poppy/poppy-humanoid · spec sheet
Poppy Humanoid specs
Open-source 3D-printed 25-DOF humanoid (~83-85 cm, 3.5 kg) from Inria Bordeaux's Flowers lab for research, education and art.
Media
5 items · credited and licensed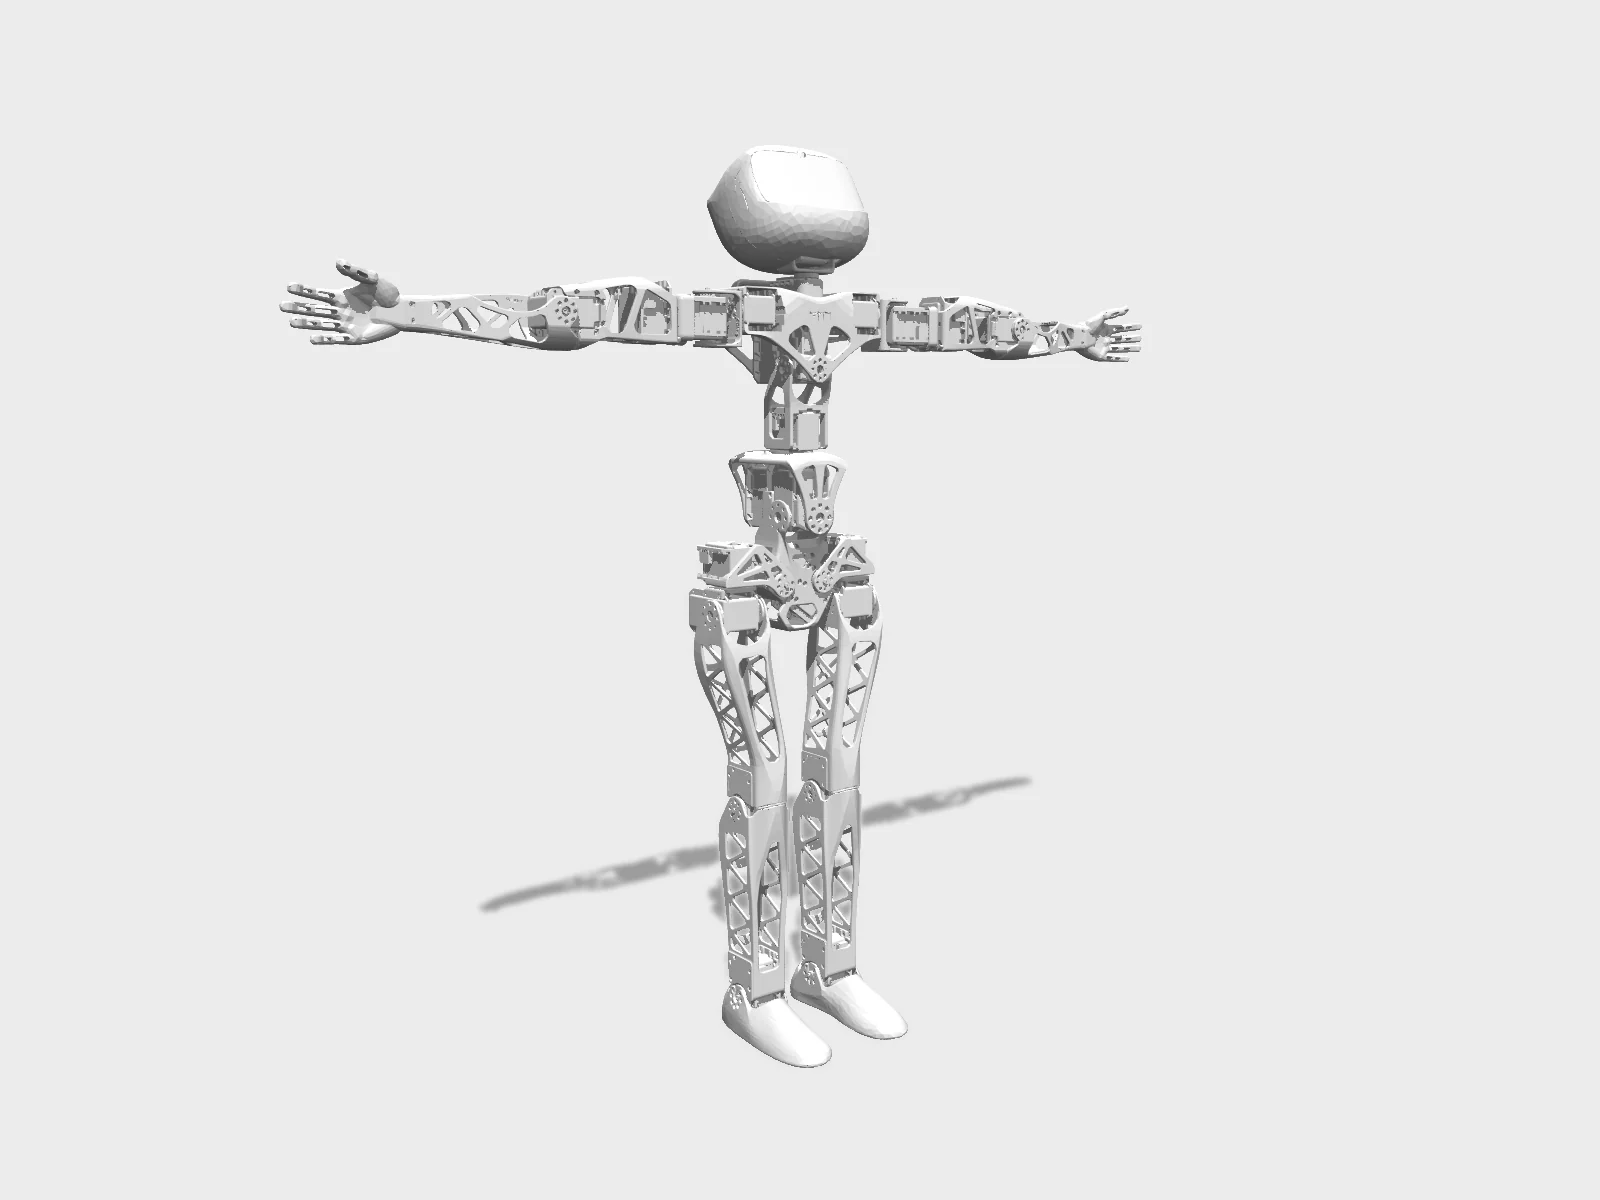 render
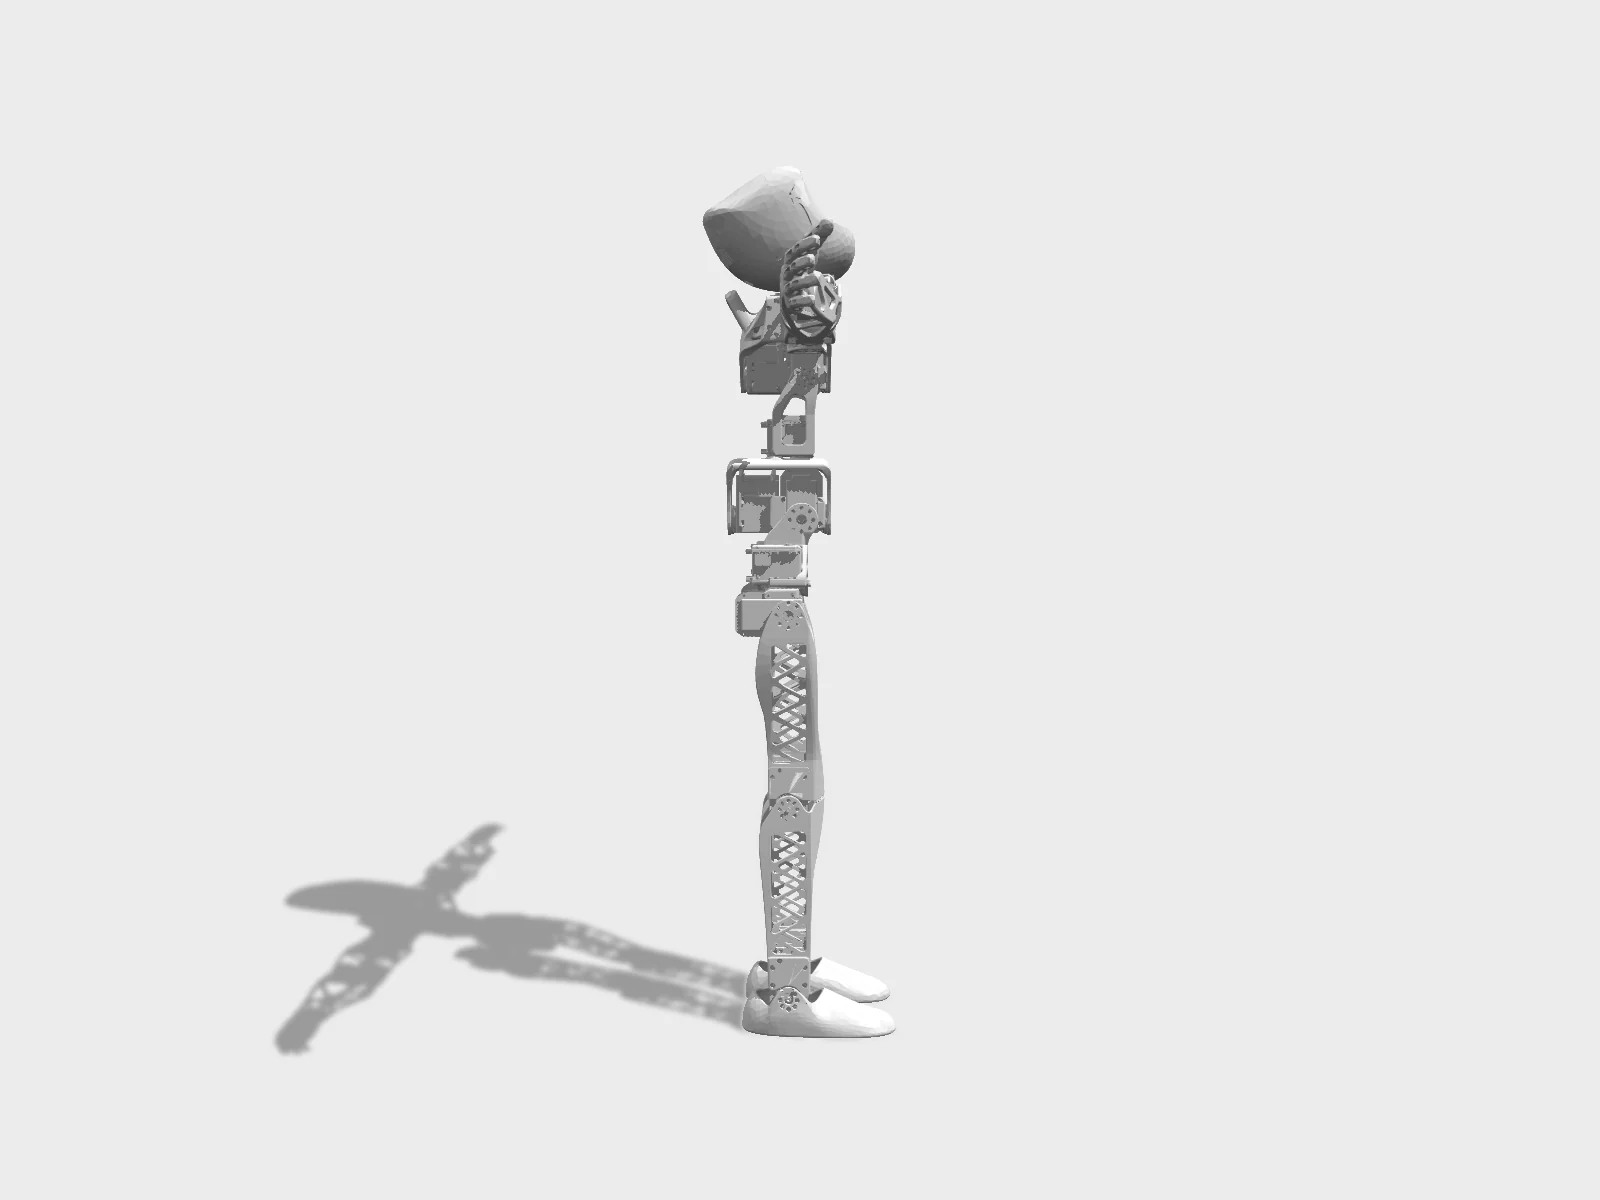 render
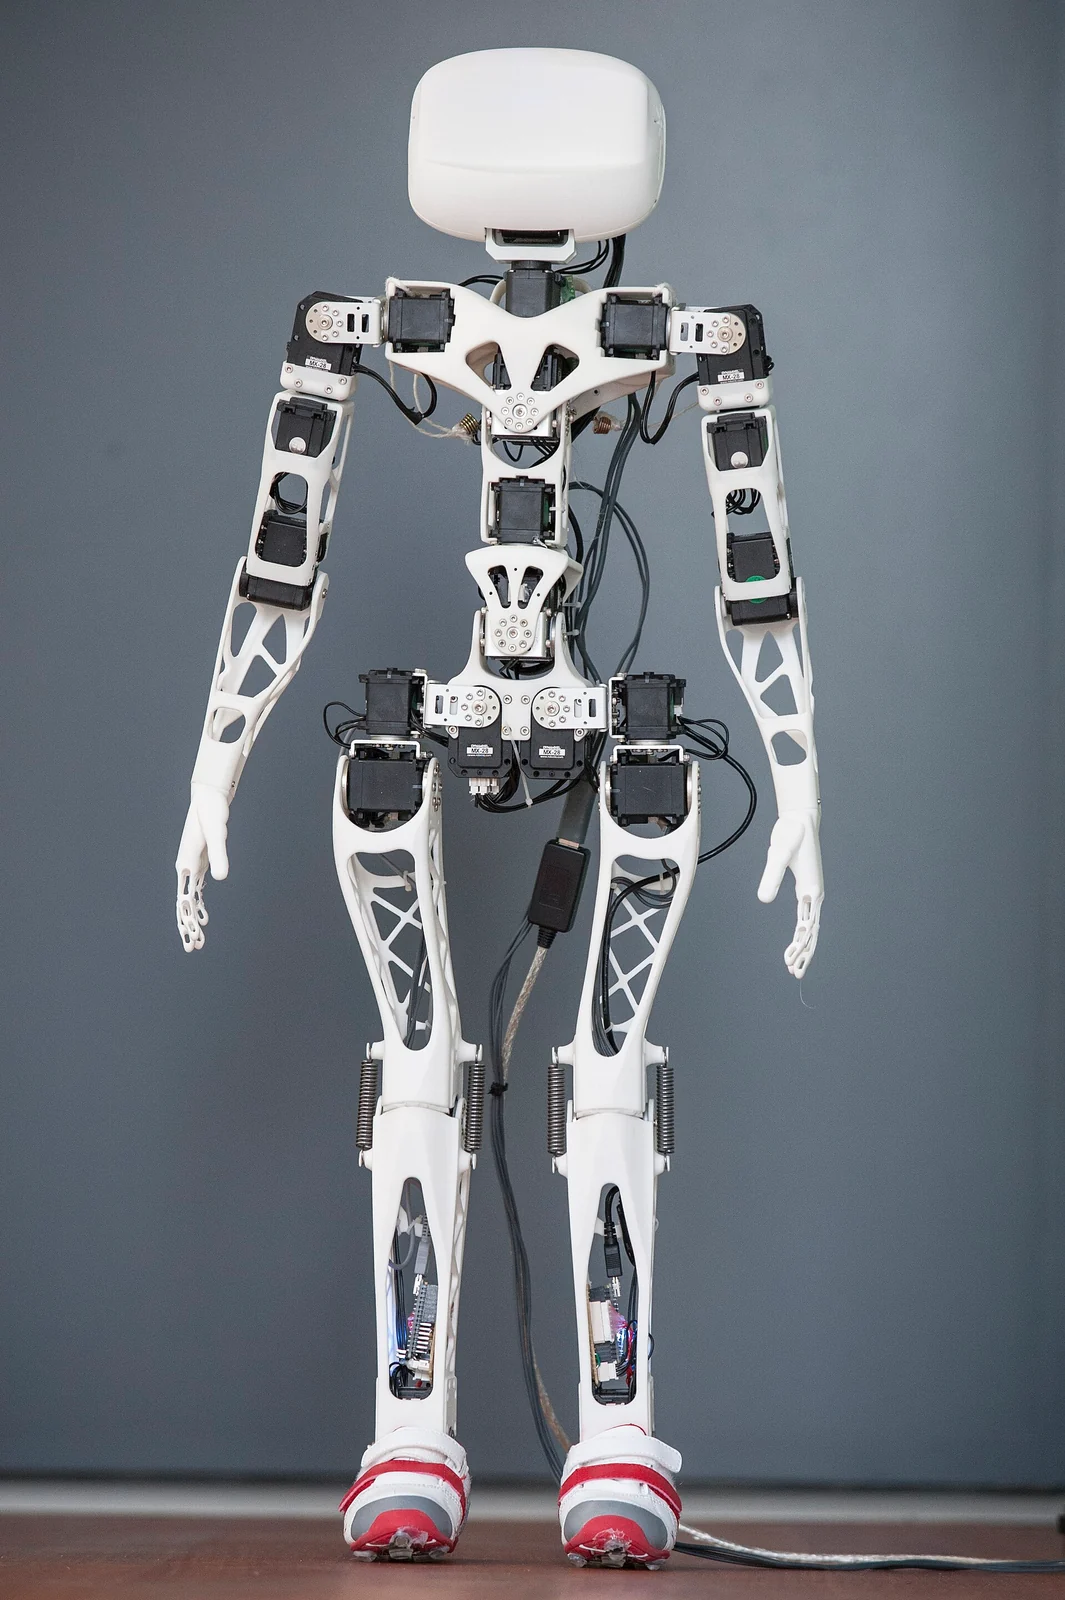

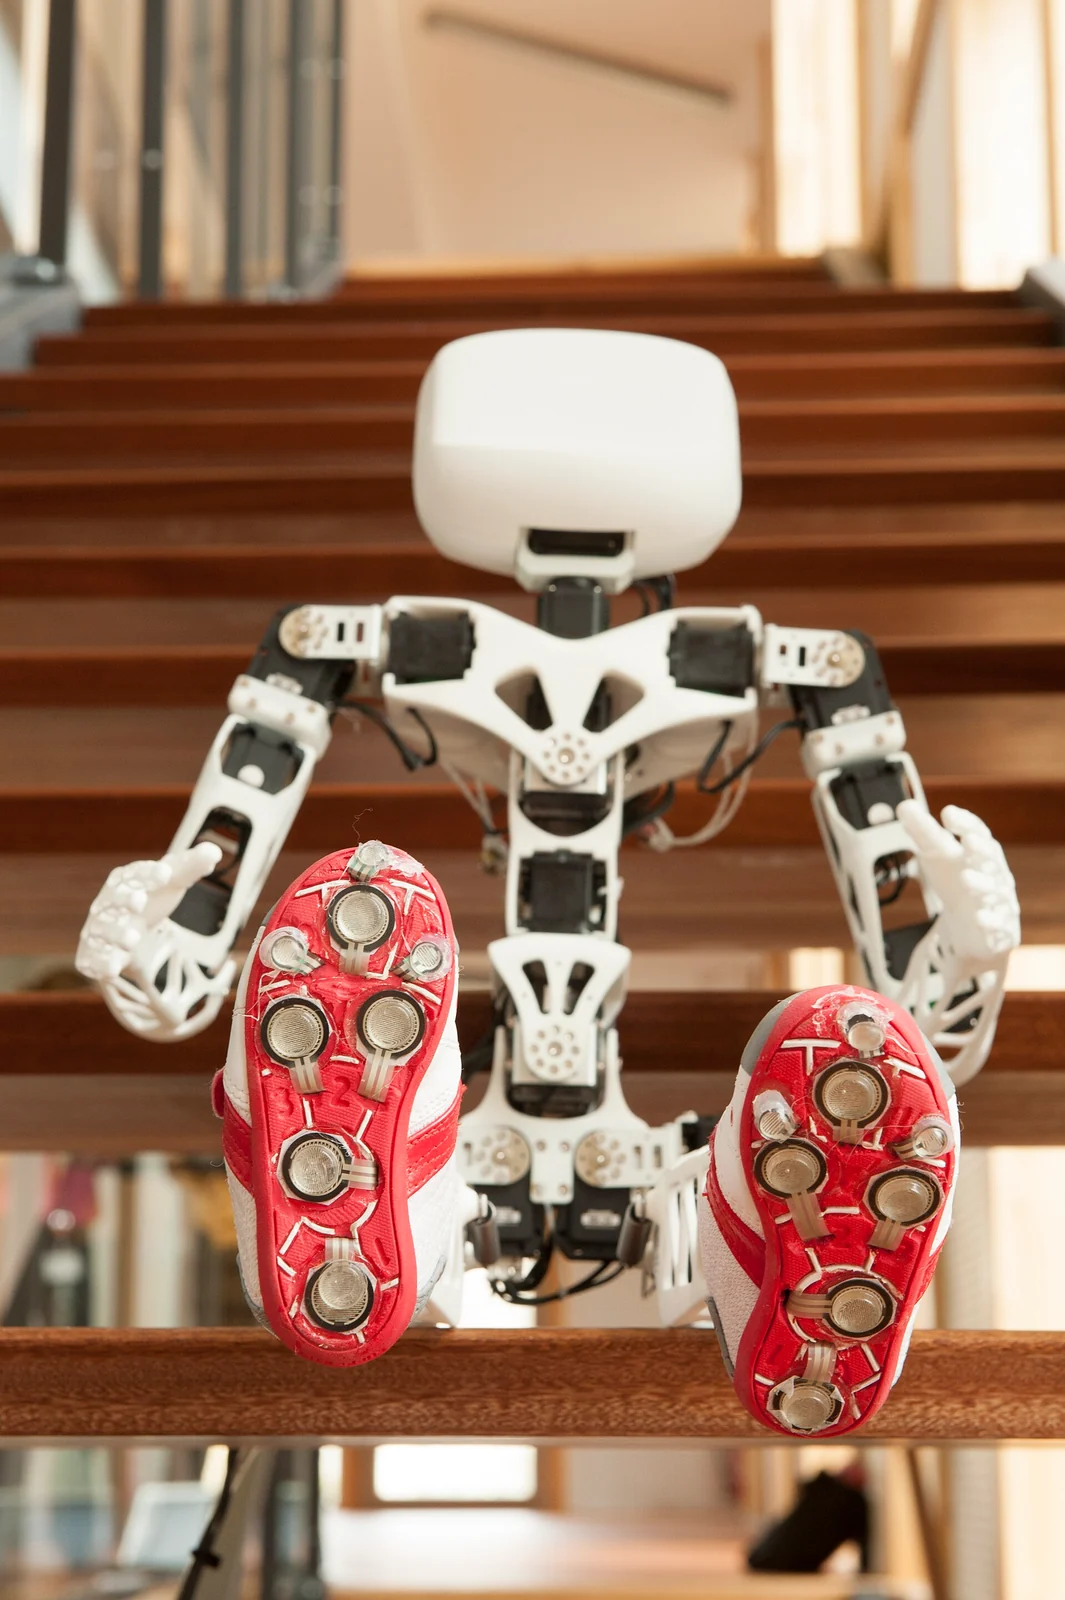

Specifications
5/12 fields sourced| Heightspecs.heightCm | 84cm |
|---|---|
| Massspecs.massKg | 3.5kg |
| Degrees of freedomspecs.dof | 25 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourcedREADME: a full build costs $8,000-9,000, ~60% of it Dynamixels. Generation Robots kit €7,862.40 incl. VAT without 3D parts, €9,971.52 with them (checked 2026-09-25) |
| Actuatorsspecs.actuators | Dynamixel: 19 MX-28AT, 4 MX-64AT, 2 AX-12A |
| Computespecs.compute | Raspberry Pi (current kit version) |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | unsourced |
| Licenselicense.hw / .sw / .docs | Hardware: CC-BY-SA-4.0Software: GPL-3.0 |
Note · Project born 2012 in Inria Flowers lab (Lapeyre PhD); exact public-unveil year not pinned (paper 2014). Main repo last pushed Dec 2021; poppy-project.org failed DNS on fetch (Sep 2026). Lapeyre later co-founded Pollen Robotics. Height quoted as 83 or 85 cm. Actuator mix (19 MX-28AT, 4 MX-64AT, 2 AX-12A) is from the motor configuration file and the archived 1.0 BOM, which agree; the current guide's per-section counts omit the arms. README puts a full build at $8,000-9,000, about 60% of it for the Dynamixels. URDF is in hardware/URDF.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | no | 10 | 0 |
| score = Σ weight × public | 90 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Electronics | 7 | 13 | 9 |
| Fasteners | 7 | 7 | — |
| Cabling | 6 | 14 | — |
| Structure | 4 | 39 | — |
| Actuators | 3 | 25 | — |
| Power | 2 | 3 | — |
| Compute | 1 | 1 | — |
| Sensors | 1 | 1 | — |
| Other | 1 | 1 | — |
Offers in EU · US from 4 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 1 | — | — |
| Preparation | 2 | — | 1 |
| Arms | 2 | — | — |
| Torso | 6 | — | — |
| Legs | 5 | — | — |
| Head | 1 | — | — |
| Electrical | 1 | — | 1 |
| Bring-up | 4 | — | 2 |
Fabrication: SLS print ×32 · SLA print ×1
Firmware
- Targets
- Raspberry Pi 3/4 (Poppy Humanoid SD image, pypot + poppy-humanoid), Dynamixel MX-28AT / MX-64AT / AX-12A (stock Robotis firmware, configured at 1 Mbps)
- Repo
- github.com/poppy-project/pypot
- Calibrate
- `poppy-configure humanoid <motor-name>` sets each motor's ID, 1,000,000 bps baud and 0 return delay, then sends it to 0° to check horn alignment. Per-motor offsets and angle limits are in software/poppy_humanoid/configuration/poppy_humanoid.json.
- Notes
- There is no custom motor firmware: stock Robotis Dynamixel firmware runs on Protocol 1.0 buses, one per body half (upper_body_controller and lower_body_controller). The controller is pypot 5.0.2 (PyPI, 2022-03-10) with the poppy-humanoid 3.0.0 package (PyPI). SD images: releases 3.0.0 (2020-11-03, Raspberry Pi 3/4, Python 3) and 4.0.0-beta (2021-07-29). The web UI (poppy.local) offers Snap!, Scratch, Jupyter/Python and Monitor and Control.
Policies
- Stand / sit posture (scripted primitives) · pypot primitives (Python) · github.comHand-written keyframe/goto behaviours, not learned policies. No walking controller or trained checkpoint is published.
- Dance beat, upper-body and head idle motion (scripted) · pypot LoopPrimitive · github.comidle.py holds UpperBodyIdleMotion and HeadIdleMotion; interaction.py holds ArmsTurnCompliant and PuppetMaster (arm copy).
- Safety: torque limiting and temperature monitoring · pypot LoopPrimitive · github.com
Caveats · stated by the package
- Project is dormant. The main repo was last pushed 2021-12-06 and poppy-docs 2022-12. poppy-project.org, docs.poppy-project.org and the forum failed DNS on 2026-09-25, so every docs link here points at the poppy-docs GitHub source.
- No per-line prices anywhere upstream. The README only says a full build costs $8,000-9,000, about 60% of it for the 25 Dynamixels. The only priced lines are the Generation Robots kit (€7,862.40 incl. VAT without 3D parts, €9,971.52 with them; both 4-6 week lead time) and single MX-28AT (€329.40 incl. VAT).
- BOM sources conflict. The per-section counts in the current guide (bom.md) add up to 13 MX-28 + 5 MX-64 + 2 AX-12 and leave out the arms. The motor config and the archived 1.0 BOM agree on 19 MX-28AT + 4 MX-64AT + 2 AX-12A, which is what this package uses.
- Fastener, horn and cable quantities come from the archived 2015 '1.0 pre-release' BOM (bulk packs). The current guide only gives per-sub-assembly counts and never totals them.
- 12 V supply count conflicts: the archived BOM lists one Robotis PS-10 12 V 5 A, while the current wiring guide and the kit list two. Two are used here.
- Head electronics drifted. The archived BOM describes an Odroid U3 head with a USB OV2643 camera, a 5 V UBEC and an optional Manga Screen. The current guide describes a Raspberry Pi 3 with a fake screen. Generation Robots lists a Pi 3 B+ plus a 3.4-inch DSI display and RPi camera on one kit page and a Pi 4 on the other. The Pi 4 'Poppy Eve' head is documented in a separate repo and not packaged here.
- Speaker and threadlocker vendor links are 2015 Farnell URLs copied from the archived BOM and were not verified. No part number is given for the speakers, the camera or the 5 V Pi supply.
- No grams, print hours or print settings are published. The reference parts are SLS polyamide (the 2015 BOM says 'white polished polyamid'), and FDM suitability isn't documented. The newest STL set is release 1.0.2 (2016). The repo's hardware/ folder only holds SolidWorks files via git-lfs and URDF meshes.
- The archived BOM lists a black 'hide-screen' head part, but the STL zip and current guide use 'screen_support'. The screen_support colour is not stated.
- Written instructions are missing for the double MX-64 sub-assembly and all leg sub-assemblies, which point to YouTube videos. No torque values are given anywhere.
- Licences: hardware CC-BY-SA-4.0 (hardware/LICENSE.md), software GPL-3.0 (software/LICENSE). The name 'Poppy' is a registered trademark, and the README asks forks to keep attribution to the Poppy project and its authors.
- The Dynamixel MX series is Robotis's older Protocol 1.0 line (the X series has largely replaced it). Check that MX-28AT/MX-64AT are still available before planning a build.
Package poppy/poppy-humanoid@0.1.0 · upstream poppy-project/poppy-humanoid@d66c8fbd6aa3ebbf9e38399cc56aae3c155ee991 (2021-12-06, master; software 4.0.0-beta image 2021-07-29); STL/STEP from release 1.0.2 (2016-05-23); itemised BOM @2b6cd60 (archived 1.0 pre-release); assembly guide poppy-project/poppy-docs@1ab374fcf6bd239e0ca6dfcaaa5d84b3c5ac2f2b (2022-12-20); leg sub-guides Poppy-lightweight-biped-legs@9be4263 (2016-05-02) · 26 package sources
Models, repositories, links
5 links- URDFgithub.com/poppy-project/poppy-humanoid/tree/master/hardware/URDFmodel
- Repogithub.com/poppy-project/poppy-humanoidgithub.com
- Repogithub.com/poppy-project/poppy-docsgithub.com
- Repogithub.com/poppy-project/pypotgithub.com
- Buygenerationrobots.com/en/312-poppy-humanoid-robotgenerationrobots.com
Videos
2 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning Poppy Humanoid
Papers using Poppy Humanoid
Sources
last checked 2026-09-25- [1]Poppy Humanoid motor configuration (motor models)github.com/poppy-project/poppy-humanoid/blob/master/software/poppy_humanoid/configuration/poppy_humanoid.jsonchecked 2026-09-25
- [2]Poppy Humanoid URDFgithub.com/poppy-project/poppy-humanoid/tree/master/hardware/URDFchecked 2026-09-25
- [3]Generation Robots: Poppy Humanoid kits (EUR prices)generationrobots.com/en/312-poppy-humanoid-robotchecked 2026-09-25
- [4]Official repogithub.com/poppy-project/poppy-humanoidchecked 2026-09-24
- [5]Lapeyre et al. 2014 paperflowers.inria.fr/LapeyreetalDI2014.pdfchecked 2026-09-24
- [6]New Atlasnewatlas.com/poppy-3d-printed-humanoid-robot-kit/29497/checked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
Cite this page
humanoidrobots.systems. “Poppy Humanoid specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/poppy/poppy-humanoid
Machine-readable: /data.json (record poppy/poppy-humanoid).