stanford/toddlerbot · spec sheet
Stanford ToddlerBot specs
Low-cost, fully 3D-printed open-source small humanoid (0.56 m, 3.4 kg, 30 DOF) for scalable policy learning research.
Media
4 items · credited and licensed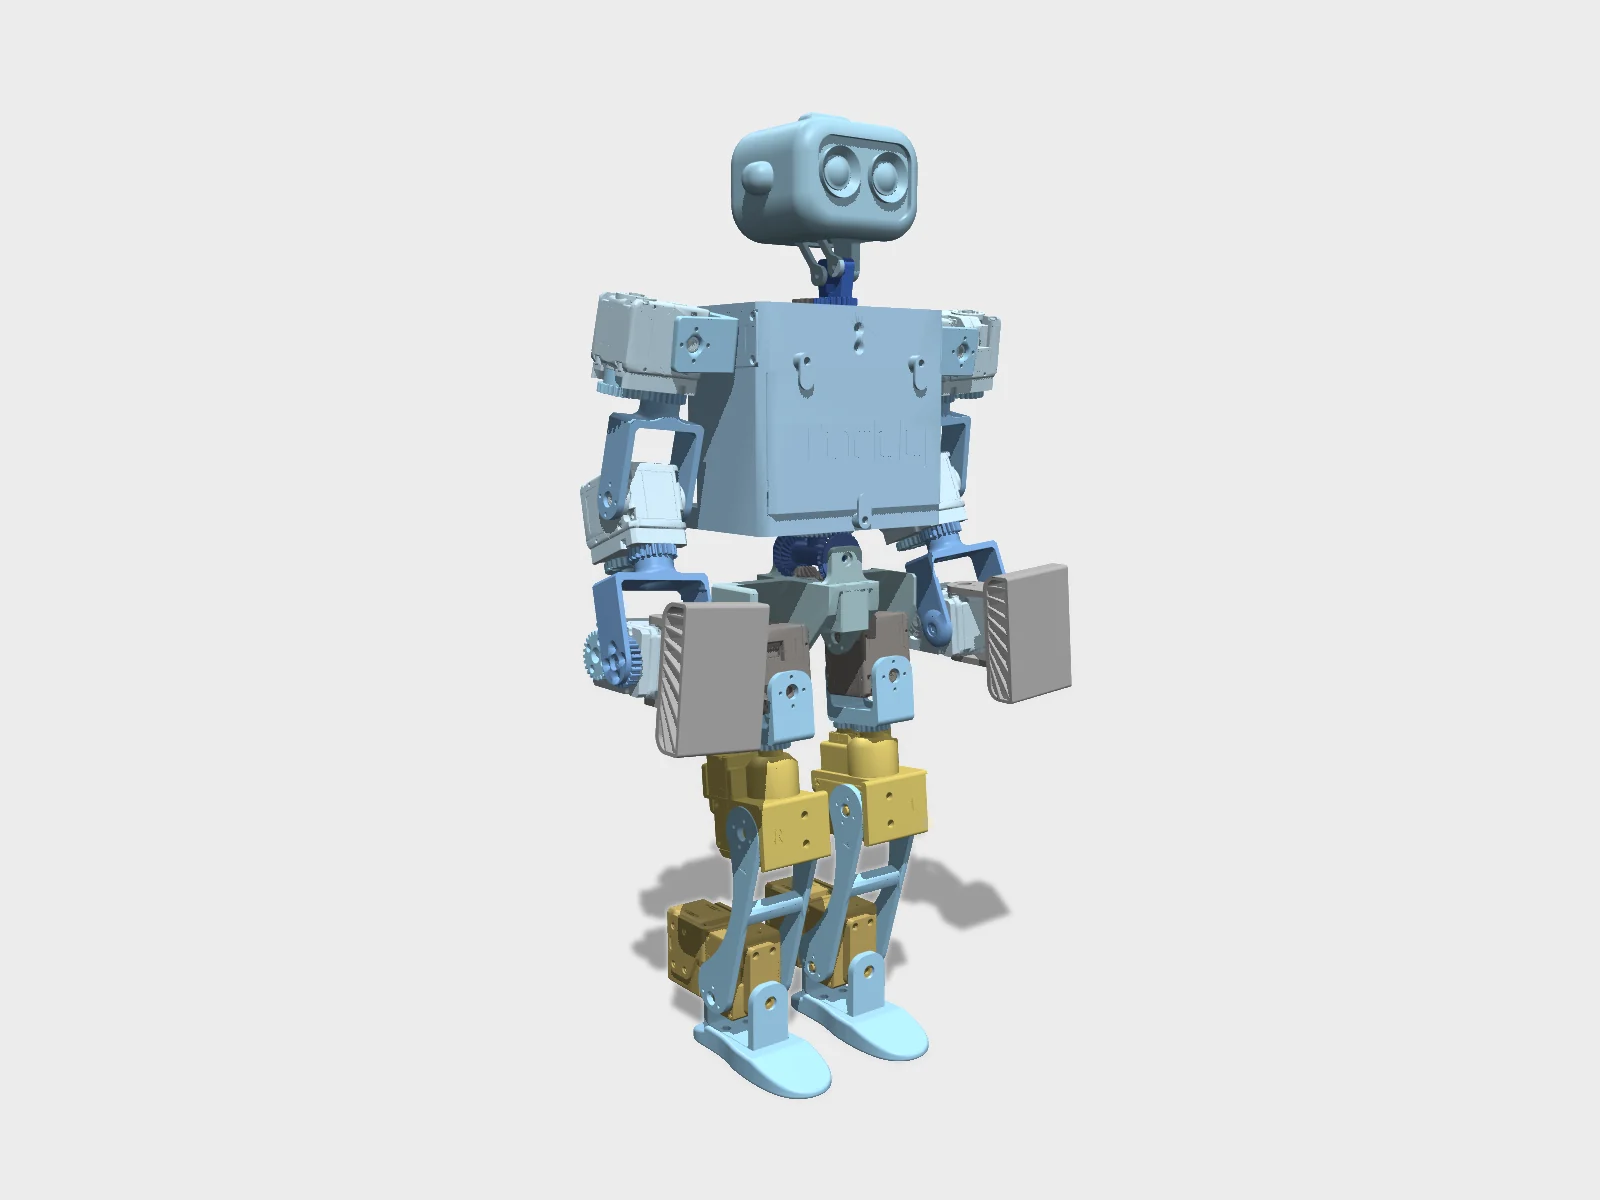 render
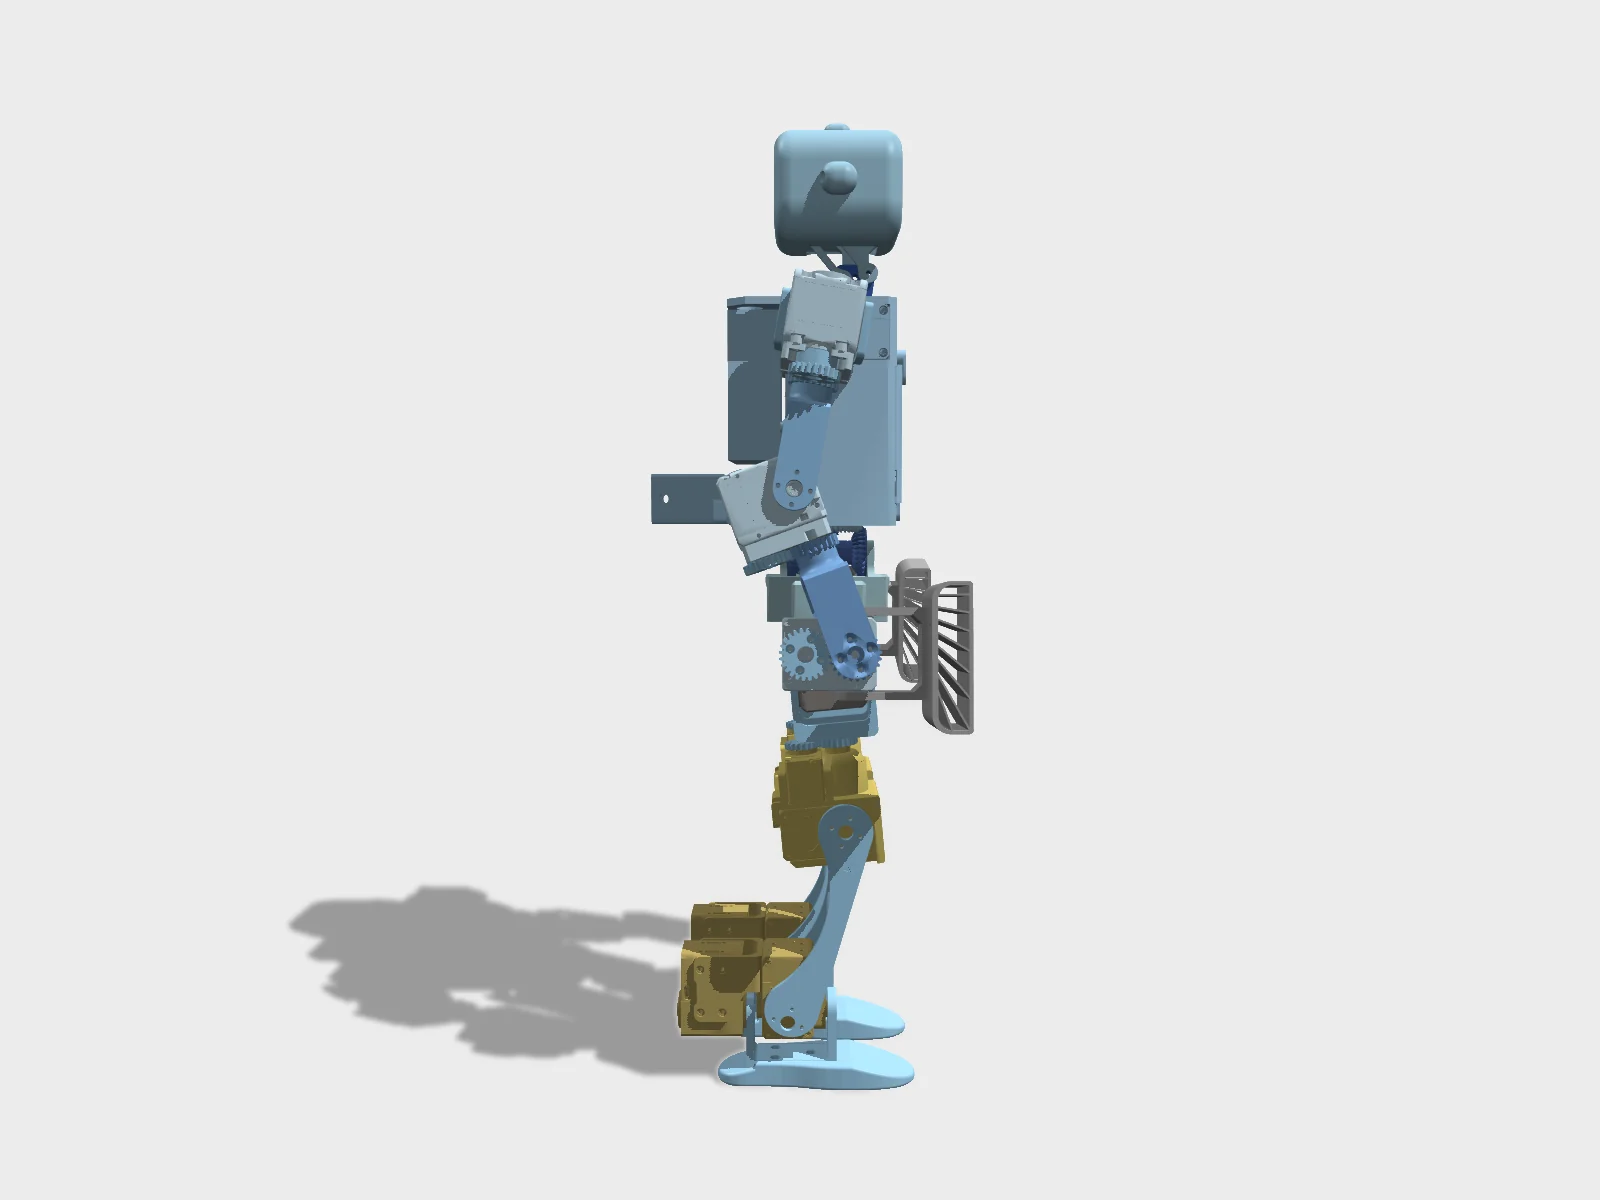 render
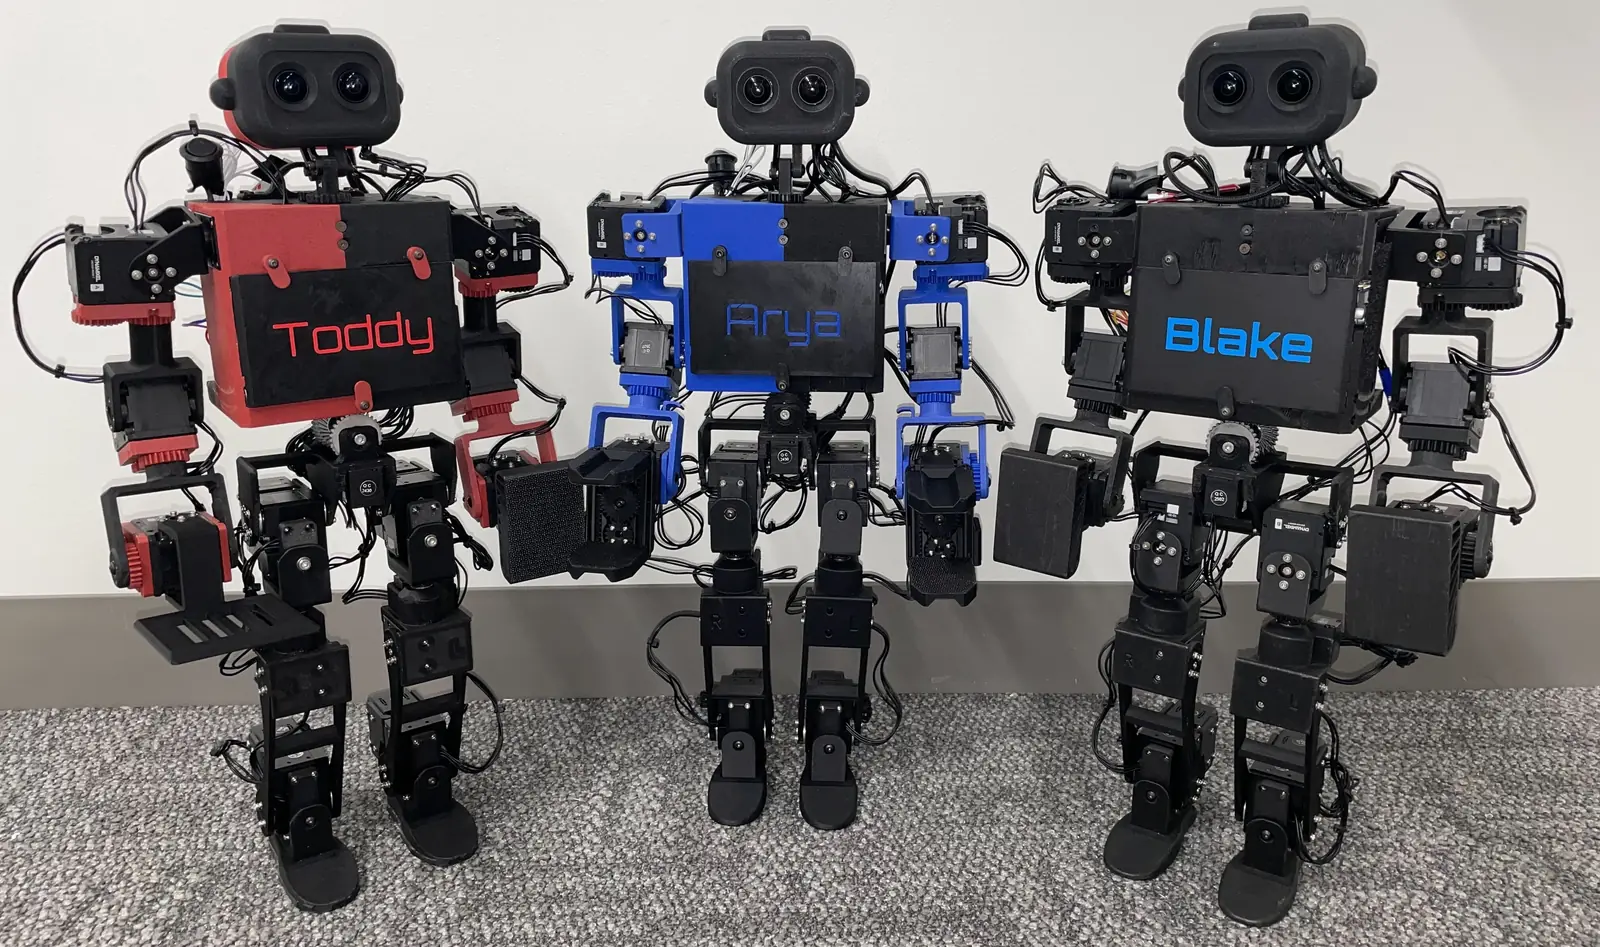

Specifications
7/12 fields sourced| Heightspecs.heightCm | 56cm |
|---|---|
| Massspecs.massKg | 3.4kg |
| Degrees of freedomspecs.dof | 30 |
| Payloadspecs.payloadKg | 1.48kg |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourcedBuild cost under $6,000 (paper); not sold |
| Actuatorsspecs.actuators | servo actuators; 7 DOF/arm, 6 DOF/leg, 2 neck, 2 waist |
| Computespecs.compute | NVIDIA Jetson Orin NX 16GB |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | 2025 |
| Licenselicense.hw / .sw / .docs | Hardware: CC-BY-NC-SA-4.0Software: MIT |
Note · ToddlerBot 2.0 released Aug 2025; variants 2XC and 2XM both in Menagerie (toddlerbot_2xm). Onshape CAD + MakerWorld print files + BOM sheet public. Locomotion Beyond Feet follow-up Jan 2026. Mirror fork exists at kscalelabs/toddlerbot. Licenses per README: code and docs MIT; hardware design (Onshape, STL/3MF) CC BY-NC-SA 4.0, non-commercial.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | yes | 10 | 10 |
| score = Σ weight × public | 100 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Actuators | 5 | 22 | 3,908 |
| Compute | 1 | 1 | 955 |
| Structure | 6 | 48 | 241 |
| Power | 5 | 6 | 171 |
| Sensors | 2 | 3 | 125 |
| Fasteners | 9 | 209 | 94 |
| Printed | 2 | 3 | 90 |
| Cabling | 9 | 42 | 73 |
| Electronics | 6 | 6 | 49 |
| Other | 2 | 2 | 24 |
Offers in CN · GLOBAL · US from 11 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 3 | — | — |
| Arms | 1 | — | — |
| Legs | 1 | — | — |
| Head | 1 | — | — |
| Waist | 1 | — | — |
| Torso | 1 | — | — |
| Bring-up | 4 | — | 3 |
| Compute | 1 | — | — |
| Electrical | 2 | — | 2 |
| Software | 1 | — | 1 |
Fabrication: FDM print ×13
Firmware
- Targets
- Dynamixel X-series servos (Protocol 2.0, TTL, 2 Mbps), TTL power board V8 (CH348L 8-port USB-to-TTL, no MCU firmware), Jetson Orin NX host (JetPack 6.1+, RT kernel)
- Repo
- github.com/hshi74/toddlerbot
- Calibrate
- python toddlerbot/tools/calibrate_zero.py --robot toddlerbot_2xc [--parts ...]; python toddlerbot/descriptions/add_configs.py --robot toddlerbot_2xc; fine-tune: python toddlerbot/policies/run_policy.py --policy calibrate --robot toddlerbot_2xc --sim real
- Notes
- No custom motor firmware. Motor IDs and baud rate are set by hand in ROBOTIS Dynamixel Wizard 2.0 (manual + 'ID the Motors' video); the repo has no ID script. Host control is a C++ pybind11 extension (toddlerbot/actuation/src/dynamixel_mch.cpp + vendored dynamixel_sdk) that scans the serial ports for motor IDs; toddlerbot/sim/real_world.py opens them at 2,000,000 baud. examples/test_dynamixel.py tests the bus. Per-motor system ID: toddlerbot/tools/run_sysID.py with the SysID jig (MakerWorld plate 7); cached fits are in toddlerbot/descriptions/sysID_*/. Per-robot configs: toddlerbot/descriptions/toddlerbot_2xc/ (MJCF, URDF, robot.yml).
Policies
- walk (omnidirectional, 2XC) · MuJoCo MJX + RSL-RL PPO, ONNX Runtime on Jetson · drive.google.comCheckpoint toddlerbot_2xc_walk_rsl_20251226_114612.zip in the Google Drive folder linked from the README. It is also the WALK_POLICY used by run_multiple_policy.py.
- get up from the ground · MuJoCo MJX + RSL-RL PPO · drive.google.comCheckpoint toddlerbot_2xc_get_up_rsl_20260214_145222.zip (Google Drive).
- crawl (full / only / rotate) · MuJoCo MJX + RSL-RL PPO · drive.google.comCheckpoints toddlerbot_2xc_crawl_full_rsl_20260214_145000.zip, crawl_only_rsl_20260214_145735.zip, crawl_rotate_rsl_20251109_195839.zip (Google Drive). Entry scripts crawl_full.py, crawl_only.py, crawl_rotate.py.
- crawl up / down stairs · MuJoCo MJX + RSL-RL PPO · drive.google.comCheckpoints toddlerbot_2xc_crawl_up_stairs_rsl_20260217_211836.zip and crawl_down_stairs_rsl_20260215_094639.zip (Google Drive). Down-stairs entry: crawl_down_stairs.py.
- climb up / down box, climb wall · MuJoCo MJX + RSL-RL PPO · drive.google.comCheckpoints toddlerbot_2xc_climb_up_box_rsl_20250907_201202.zip, climb_down_box_rsl_20250914_014343.zip, climb_wall_rsl_20250913_174540.zip (Google Drive). Entry scripts climb_down_box.py, climb_wall.py.
- multi-skill whole-body locomotion (Locomotion Beyond Feet) · RL skill policies + depth skill classifier (FoundationStereo) · github.comChains the Drive checkpoints through a depth-image skill classifier. No classifier checkpoint is published; train it with toddlerbot/skill_classifier/training/train.py on your own collected data.
- push-up (keyframe replay) · open-loop keyframe replay (run_policy.py --policy replay) · github.commotion/ holds 2XC and 2XM keyframe/reference motions (cartwheel, crawl, get-up, pull-up, kneel, walk_zmp, ...). These are reference motions, not trained networks.
- cartwheel (DeepMimic-style) · MuJoCo MJX + RSL-RL PPO · github.comNo cartwheel checkpoint in the Drive folder. Train with train_mjx.py --gin-file cartwheel --env cartwheel against motion/cartwheel_2xc.lz4. The changelog says the success rate is still low.
- bimanual manipulation (diffusion policy) · Diffusion Policy (PyTorch) · github.comExpects results/<robot>_<task>_dp_<ckpt>/best_ckpt.pth from your own teleop data; no DP weights are published.
Caveats · stated by the package
- Variant: this package is toddlerbot_2xc, the docs' 'recommended default' and the only variant with published RL checkpoints. toddlerbot_2xm (stronger hips: 6x 2XC430, 0x 2XL430, +4x XM430-W350; separate MakerWorld release) is noted in the alts; the sheet's 2XM essentials total is $7,293.56. Sources disagree on which to build: MakerWorld's 2XC page calls 2XM 'recommended for all new builds too'.
- Licensing: code and docs are MIT, but the hardware design (Onshape, STL/3MF) is CC BY-NC-SA 4.0 (non-commercial) per the README and MakerWorld.
- The assembly manual PDF in the repo is the 1.0 manual, and the docs say so: 2.0 users are sent to overview videos, Onshape and a tnkr.ai interactive manual. The tnkr.ai link (docs.tnkr.ai/Stanford University) did not respond on 2026-09-25. Steps here follow the 1.0 manual and 2.0 videos; motor counts per subassembly are from the 1.0 manual.
- The 1.0 manual assigns IDs with a U2D2 + power hub + 12 V adapter. The 2.0 essentials list neither (only under Teleoperation, $32.10 + $19.00), and no 12 V adapter is listed anywhere.
- The per-joint ID list and chain diagram exist only as a figure in the manual PDF. The repo has no ID-assignment script and no plain-text ID table.
- Bearings: the Screws tab says 683 x12 are used, but the sheet buys one 10-pack. Buy two.
- Plate 16 'Palm with TPU' uses 62 g of TPU, but the BOM lists no TPU. This package uses the rubber-tape palm (plate 18) instead.
- MakerWorld plates carry no per-part lists, so fabricated qty is per plate, not per part. Plate 19 is unlabelled. Optional plates are excluded: Safety Stand, SysID, Teleop, Gripper.
- Printed parts do not appear in the repo, which only has visual/collision meshes under descriptions/. Printable files live on MakerWorld (Bambu 3MF) and Onshape.
- Prices are the undated USD figures in the published sheet. ROBOTIS prices disagree inside the sheet (2XL430 $149.39 in Essentials vs $129.90 under Teleoperation), so treat them as stale. JST EH and M2x6 unit prices are derived from the sheet's line totals ($3.82, $1.17, $1.80). The priced lines add up to the sheet's 2XC essentials total ($5,727.94), which excludes the PCB, gripper, tools and optional features.
- The 8-channel TTL power board has no upstream price. The docs say the JLCPCB cost is mostly setup fees and varies with tariffs; order 5 (2 minimum).
- Several vendor links are short or share links that could not be expanded or verified: DigiKey /short/ links returned 403, and the Taobao e.tb.cn link. The LiPo listing's cell count and voltage are not stated in the sheet.
- Tools are not in this BOM. The sheet lists about $1,976 of tools (Bambu X1C, bench supply, screwdrivers, soldering kit) and about $2,253 of optional features: safety stand, arm teleop leader, DIY 21700 battery, SysID clamp, ROG Ally X.
- An assembled 2.0 is sold by WowRobo ($4,299 at shop.wowrobo.com, pre-order, sold out on 2026-09-25; Jetson, Wi-Fi and battery not included). The sheet disclaims any affiliation with it.
- The published checkpoints are Google Drive zips from the authors (all 2XC), not versioned in the repo. Some loaders (mjx_policy.load_wandb_policy) default to a private W&B entity, 'toddlerbot'.
Package stanford/toddlerbot@0.1.0 · upstream hshi74/toddlerbot@e337f3b177b4b53abff70b31d1695a7b66cc6d2e (2026-04-19; ToddlerBot 2.0.0 released 2025-08-25). BOM Google Sheet "Release" + "Screws" tabs read 2026-09-25 (undated sheet). MakerWorld 2XC print profile last noted update 2025-11-21. Package targets toddlerbot_2xc. · 25 package sources
Models, repositories, links
6 links- MJCFgithub.com/google-deepmind/mujoco_menagerie/tree/main/toddlerbot_2xcmodel
- Menageriemujoco_menagerie/toddlerbot_2xcmodel
- Repogithub.com/hshi74/toddlerbotgithub.com
- Sitetoddlerbot.github.io/toddlerbot.github.io
- Docshshi74.github.io/toddlerbothshi74.github.io
- Videoyoutube.com/watch?v=A43QxHSgLyMyoutube.com
Videos
2 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning ToddlerBot
Papers using ToddlerBot
20251
- Open source
Stanford releases ToddlerBot
Stanford researchers described ToddlerBot, a low-cost open-source humanoid designed for machine-learning research in locomotion and manipulation.
Stanford UniversityStanford ToddlerBotarxiv.orgtoddlerbot.github.io
Sources
last checked 2026-09-25- [1]Official repo (README license section: code MIT, design CC BY-NC-SA 4.0)github.com/hshi74/toddlerbotchecked 2026-09-25
- [2]arXiv paperarxiv.org/abs/2502.00893checked 2026-09-24
- [3]Project sitetoddlerbot.github.io/checked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
Also by Stanford University
Cite this page
humanoidrobots.systems. “Stanford ToddlerBot specs.” Hyperspawn, data revision 2026-11-13. https://humanoidrobots.systems/stanford/toddlerbot
Machine-readable: /data.json (record stanford/toddlerbot).