companies/stanford · company record
Stanford University
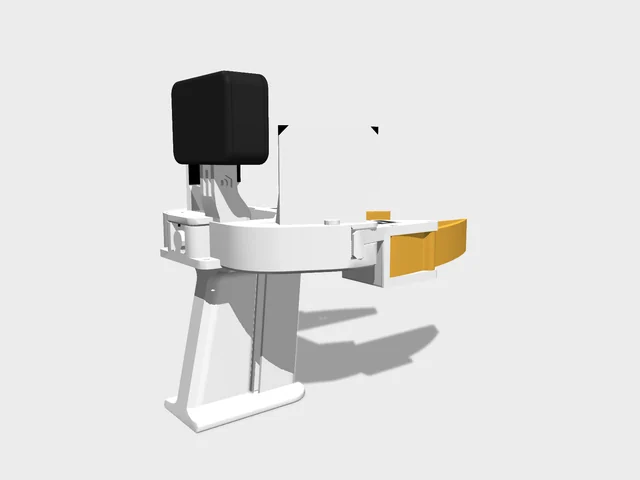
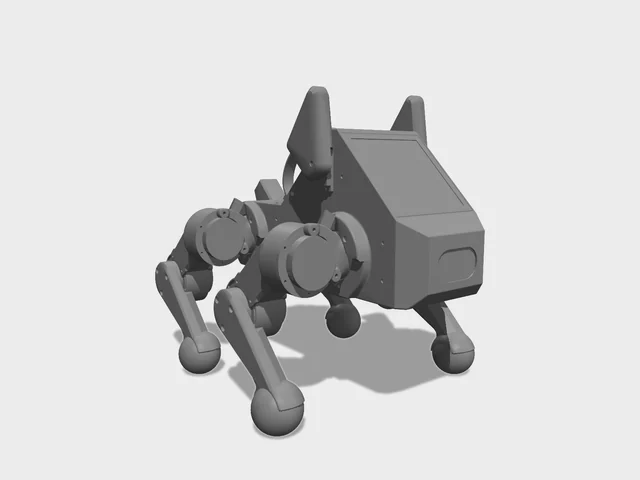
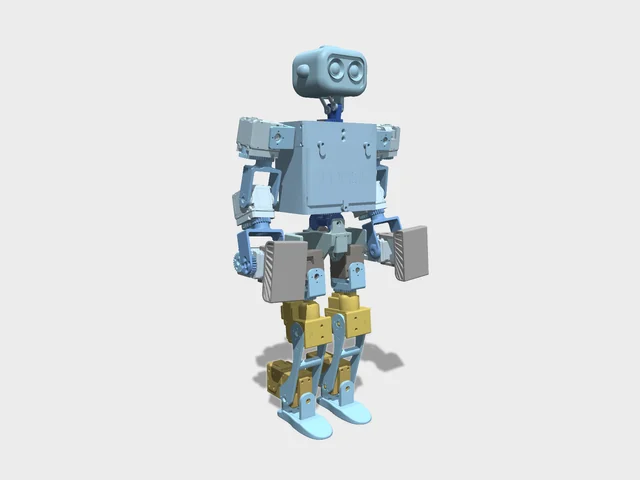
University whose labs and student groups released several open hardware projects, including ALOHA, the UMI gripper, ToddlerBot and the Pupper quadrupeds.
Robots
5 in the atlas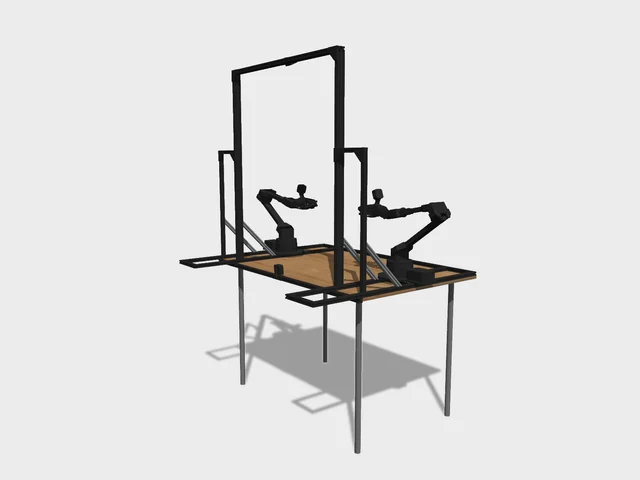
Models
2 listedNews
live feedTimeline
5 entries20251
- Open source
Stanford releases ToddlerBot
Stanford researchers described ToddlerBot, a low-cost open-source humanoid designed for machine-learning research in locomotion and manipulation.
Stanford UniversityStanford ToddlerBotarxiv.orgtoddlerbot.github.io
20242
- Research
Universal Manipulation Interface (UMI) published
Researchers presented UMI, a handheld gripper and policy-learning framework for collecting manipulation demonstrations in the wild without a robot.
Stanford UniversityStanford UMI Gripper (Universal Manipulation Interface)arxiv.org - Research
Stanford publishes Mobile ALOHA
Mobile ALOHA put the ALOHA teleoperation setup on a mobile base for low-cost, whole-body data collection and imitation learning.
Stanford UniversityStanford ALOHAarxiv.orgventurebeat.com
20231
- Research
ALOHA and ACT paper released
Stanford-led researchers introduced ALOHA, a low-cost open bimanual teleoperation system, and the Action Chunking with Transformers (ACT) imitation-learning method.
Stanford UniversityStanford ALOHAarxiv.org
20211
- Open source
Stanford Pupper paper published
Stanford researchers presented Pupper, a low-cost open-source quadruped intended as a benchmark and teaching platform for legged robotics.
Stanford UniversityStanford Pupper (v1)arxiv.orggithub.com