kscale/zbot · spec sheet
K-Scale Z-Bot (Zeroth Bot) specs
Small 3D-printed open-source humanoid (~46 cm, 18 motors) from K-Scale Labs, community-developed as Zeroth Bot; sold as Z-Bot at $999 before K-Scale shut down.
Media
4 items · credited and licensed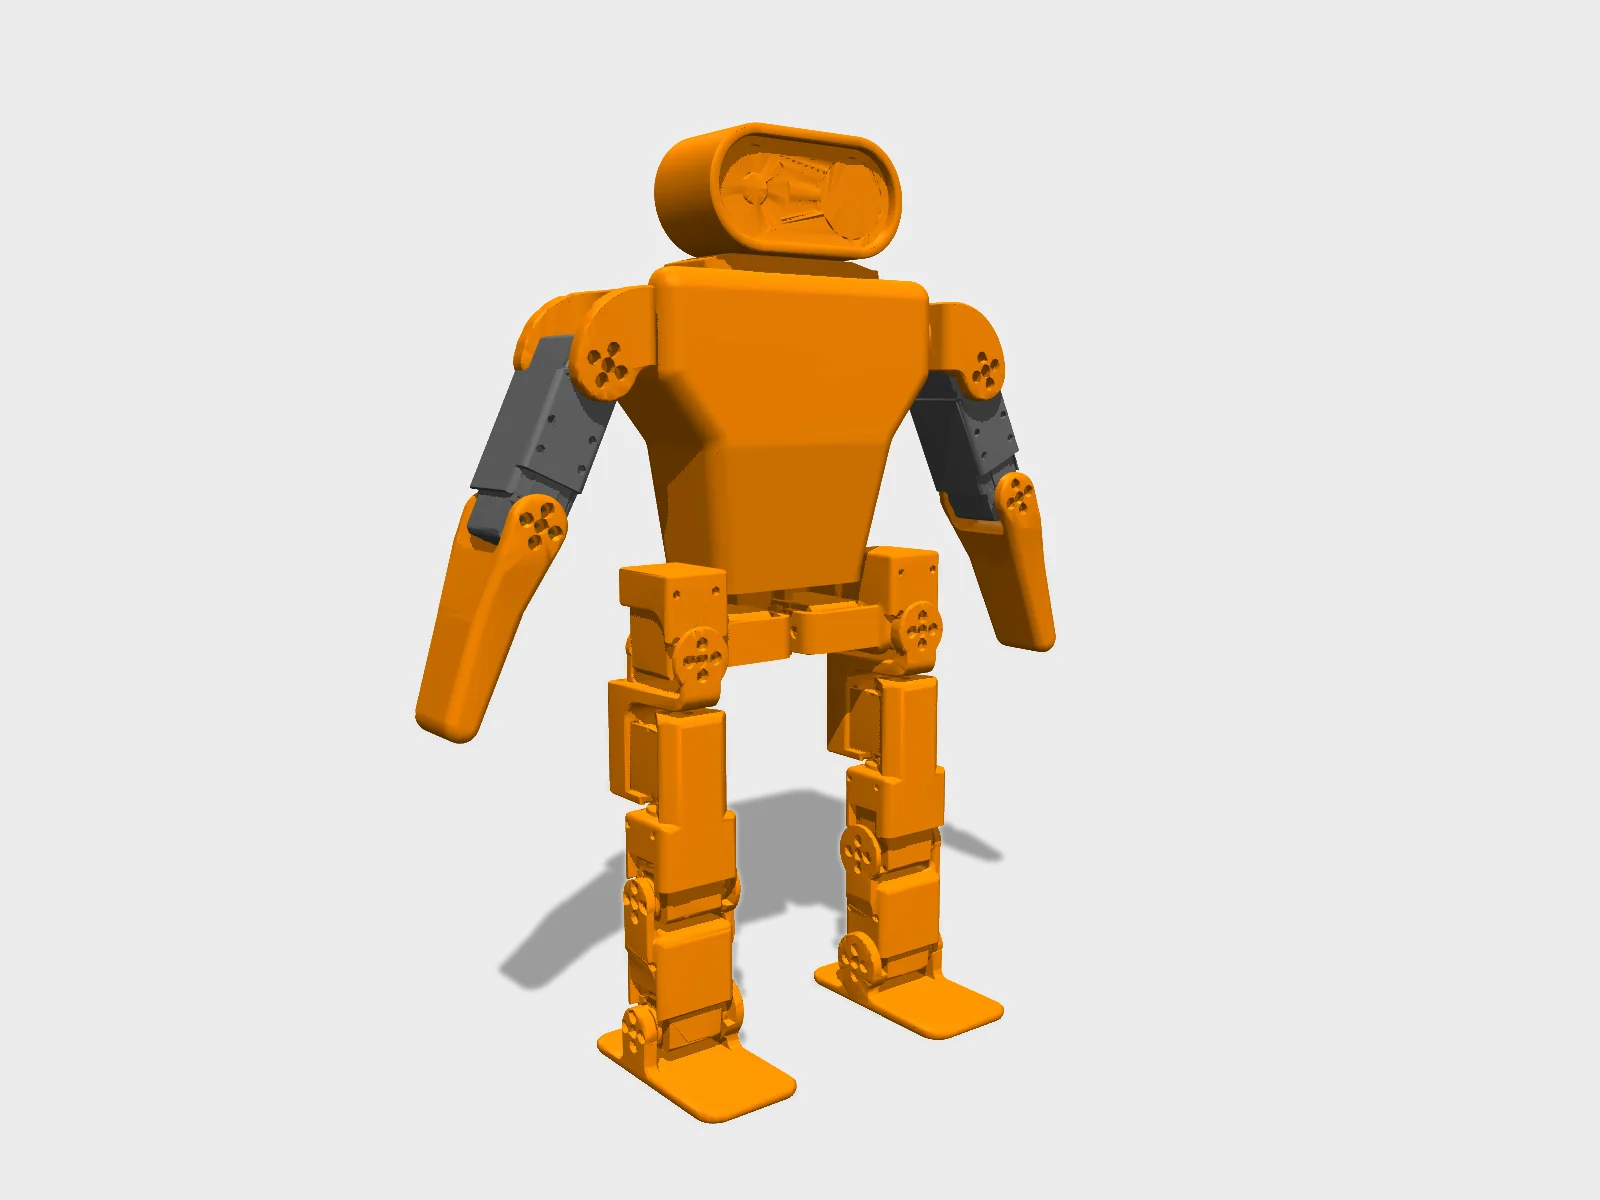 render
 render
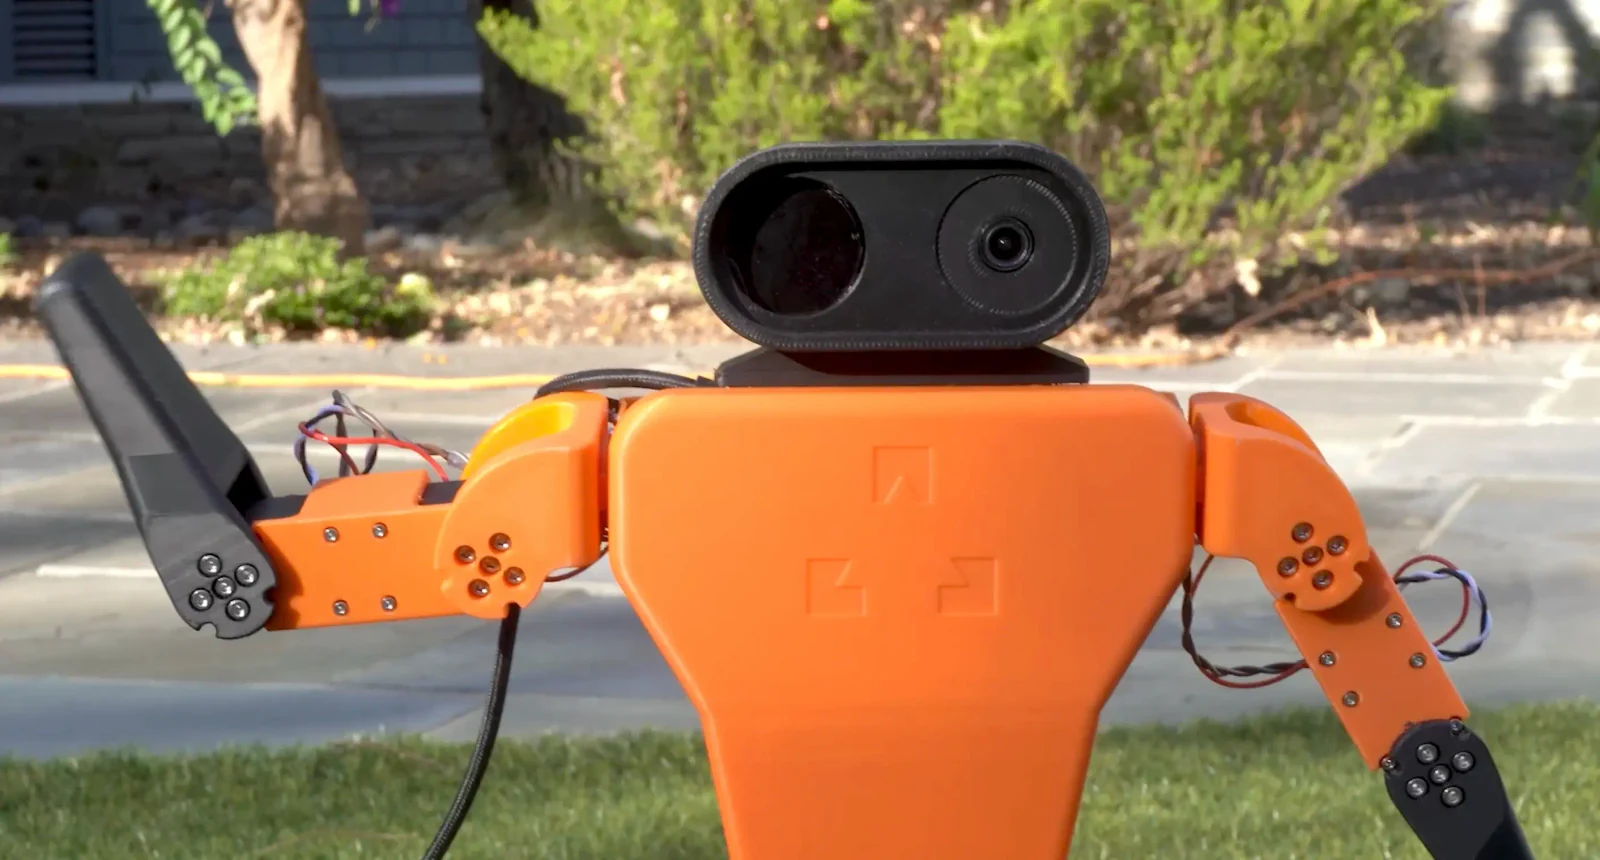

Specifications
6/12 fields sourced| Heightspecs.heightCm | 46cm |
|---|---|
| Massspecs.massKg | unsourced |
| Degrees of freedomspecs.dof | 18 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | 999USD$999 (2025); community BOM from ~$350 |
| Actuatorsspecs.actuators | 18 servo motors |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | cameras, IMU (per press) |
| Year introducedyear | 2025 |
| Licenselicense.hw / .sw / .docs | Hardware: MITSoftware: MIT |
Note · K-Scale Labs shut down in Nov 2025; the repositories (zeroth-bot, MIT) remain public and community-maintained. No maintainer can certify it until someone adopts it. github.com/kscalelabs/zbot does not exist; the project repo is zeroth-bot. ksim-gym-zbot and zbot-policy-walking contain train.py/convert.py only (no checkpoints), so policies=false.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | no | 10 | 0 |
| score = Σ weight × public | 90 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Electronics | 5 | 5 | 45 |
| Power | 2 | 2 | 36 |
| Sensors | 2 | 2 | 34 |
| Compute | 1 | 1 | 10 |
| Fasteners | 7 | 263 | — |
| Cabling | 2 | 3 | — |
| Actuators | 1 | 16 | — |
| Other | 1 | 1 | — |
Offers in CN · GLOBAL · US from 7 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| fabrication | 2 | — | — |
| legs | 3 | — | — |
| torso | 1 | — | — |
| arms | 2 | — | — |
| electrical | 3 | — | 2 |
| software | 1 | — | — |
| bring-up | 1 | — | 1 |
Fabrication: FDM print ×14
Firmware
- Targets
- Milk-V Duo S (SG2000) running OpenLCH buildroot image (Zeroth-01 BOM), Raspberry Pi 4B running zbot-os-pi4b / kos-zbot (later K-Scale Z-Bot revision), Feetech STS3250 servos (ID/zero config over serial bus, 1 Mbaud), RP2040-LCD-1.28 head display
- Repo
- github.com/kscalelabs/kos-zbot
- Calibrate
- kos-zbot CLI: `kos actuator zero all` (or comma-separated IDs) to zero servos; robot-specific service `kos zbot` loads gains and limits. Actuator IDs used in kos-zbot scripts: 11-14, 21-24 (arms), 31-36, 41-46 (legs), 20 total. Older zeroth-bot tree has Rust bins feetech_calibrate / feetech_change_id / feetech_scan.
- Notes
- Zeroth-01 path: OpenLCH image from https://github.com/Zeroth-Robotics/OpenLCH-buildroot/releases, SSH over USB gadget 192.168.42.1. K-Scale path: Raspberry Pi OS 64-bit + kos-zbot (Python 3.12), servo UART /dev/ttyAMA5 at 1,000,000 baud, 50 Hz control loop default, BNO055 IMU over I2C, policies in .kinfer format run with `kos zbot infer --model`.
Policies
- Z-Bot joystick/velocity walking (RL benchmark template) · ksim (JAX/MuJoCo) + kinfer · github.comPipeline: train.py, then convert.py exports model.kinfer. No weights file in the repo (checked 2026-09-25).
- Basic Z-Bot walking policy · ksim + kinfer · github.comconvert.py exports the trained policy to .kinfer.
- Standing policy (Zeroth-01, TPU) · PyTorch -> CVITEK TPU (Milk-V) · github.comConverted for the Milk-V TPU with tpu-mlir.
- Demo inference (Zeroth-01 first run) · Python SDK · github.comexperiments/ exists in the kscalelabs fork only; upstream zeroth-robotics/zeroth-bot does not (checked 2026-09-25).
- Scripted demos: wave, salute; voice conversation · kos-zbot · github.comAlso kos_zbot/scripts/salute.py and the voice conversation module kos_zbot/conversation.
Caveats · stated by the package
- K-Scale Labs shut down in November 2025 and refunded preorders. docs.kscale.dev and docs.zeroth.bot did not resolve (DNS failure) on 2026-09-24, so all doc content was read from the GitHub source repos (kscalelabs/docs, zeroth-robotics/docs).
- No repo named kscalelabs/zbot exists. The hardware repo is kscalelabs/zeroth-bot (a fork of zeroth-robotics/zeroth-bot, last commit 2025-03-19). The OS/software is kscalelabs/kos-zbot.
- The only public BOM is the Zeroth-01 electronics BOM (last updated 2024-11-28, 'not yet finalized') with 16x STS3250 and a Milk-V Duo S. The later K-Scale Z-Bot revision uses a Raspberry Pi 4B and 20 actuator IDs, and no BOM for that revision was found.
- The itemised BoM Google Sheet linked from the K-Scale BOM page (1CmScSyjjHeuxxL0QmV3nXdUUqKY3HEEfBCJPlzzbGro) now requires sign-in and could not be read.
- The servo price is not current. The BOM says 'Depends by Seller due to Supply Chain Issues. Previously: 222.24' for 16 units, so no unitUsd is given. Other prices are the BOM's 'Total Cost' at qty 1, from late 2024.
- The docs say STS3215 servos are too slow for the legs and STS3250 should be used. If you use plastic-housing STS3215s, the housing holes are not tapped and self-tapping screws are needed.
- Unlisted items: the 'Milk hat' and 'custom PCBs' mentioned in the assembly doc, the PH-2.0 4-pin cable, the M3x8, M3x12, M3x5, M2x4 and M2x6 screws, and the M3 nuts. These are named in the assembly steps but are not in the fastener table. The Google Doc also says '4 X M10' for the torso-to-hip joint, which looks like a typo for M3x10.
- Printing material, print hours and grams are not published.
- Step minutes are not published. The assembly doc only notes that order matters for the legs.
Package kscale/zbot@0.1.0 · upstream Zeroth-01 BOM/docs last updated 2024-11-28 (zeroth-robotics/docs@4b8db2311228a445c9d0d6264e02f3a8b102831c); STL set 20241118; K-Scale BOM page kscalelabs/docs@d4ca00ddc760197661d66495d0793b85dd31bea8; kos-zbot@fce28827aad2abfa308576e24a95621b41302a6a · 13 package sources
Models, repositories, links
5 links- URDFgithub.com/kscalelabs/zeroth-bot/blob/main/experiments/teleop/urdf/robot_fixed.urdfmodel
- Repogithub.com/kscalelabs/zeroth-botgithub.com
- Repogithub.com/kscalelabs/kos-zbotgithub.com
- Repogithub.com/kscalelabs/ksim-gym-zbotgithub.com
- Repogithub.com/kscalelabs/zbot-policy-walkinggithub.com
News and papers
0 stories · 0 papersNews mentioning Z-Bot (Zeroth Bot)
Papers using Z-Bot (Zeroth Bot)
20251
- Company
K-Scale Labs shuts down and releases its IP
K-Scale Labs canceled K-Bot orders and refunded deposits after failing to raise funding, and released its intellectual property as open source.
K-Scale LabsK-Scale K-BotK-Scale Z-Bot (Zeroth Bot)humanoidsdaily.commikekalil.com
Sources
last checked 2026-09-24- [1]Zeroth Bot repogithub.com/kscalelabs/zeroth-botchecked 2026-09-24
- [2]TechEBlog $999 Z-Bottecheblog.com/k-scale-labs-open-source-humanoid-robot/checked 2026-09-24
- [3]Humanoids Daily shutdownhumanoidsdaily.com/news/k-scale-labs-cancels-k-bot-orders-open-sources-all-ip-after-funding-failschecked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
- ROBOTIS OP3
- Stanford ToddlerBot
- UC Berkeley Humanoid Lite
- Poppy Humanoid
- UC Berkeley Humanoid
- Noetix Bumi
Also by K-Scale Labs
Compare
- Z-Bot (Zeroth Bot) vs ROBOTIS OP3
- Z-Bot (Zeroth Bot) vs Stanford ToddlerBot
- Z-Bot (Zeroth Bot) vs UC Berkeley Humanoid Lite
- Z-Bot (Zeroth Bot) vs Poppy Humanoid
- Z-Bot (Zeroth Bot) vs K-Scale K-Bot
- Z-Bot (Zeroth Bot) vs Hyperspawn Dropbear
- Z-Bot (Zeroth Bot) vs Kepler Forerunner K2 "Bumblebee"
- Z-Bot (Zeroth Bot) vs PUDU D9
Cite this page
humanoidrobots.systems. “K-Scale Z-Bot (Zeroth Bot) specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/kscale/zbot
Machine-readable: /data.json (record kscale/zbot).