kscale/kbot · spec sheet
K-Scale K-Bot specs
Open-source full-size humanoid from K-Scale Labs; Founder's Edition units shipped in 2025 before the company cancelled pre-orders and wound down in Nov 2025.
Media
3 items · credited and licensed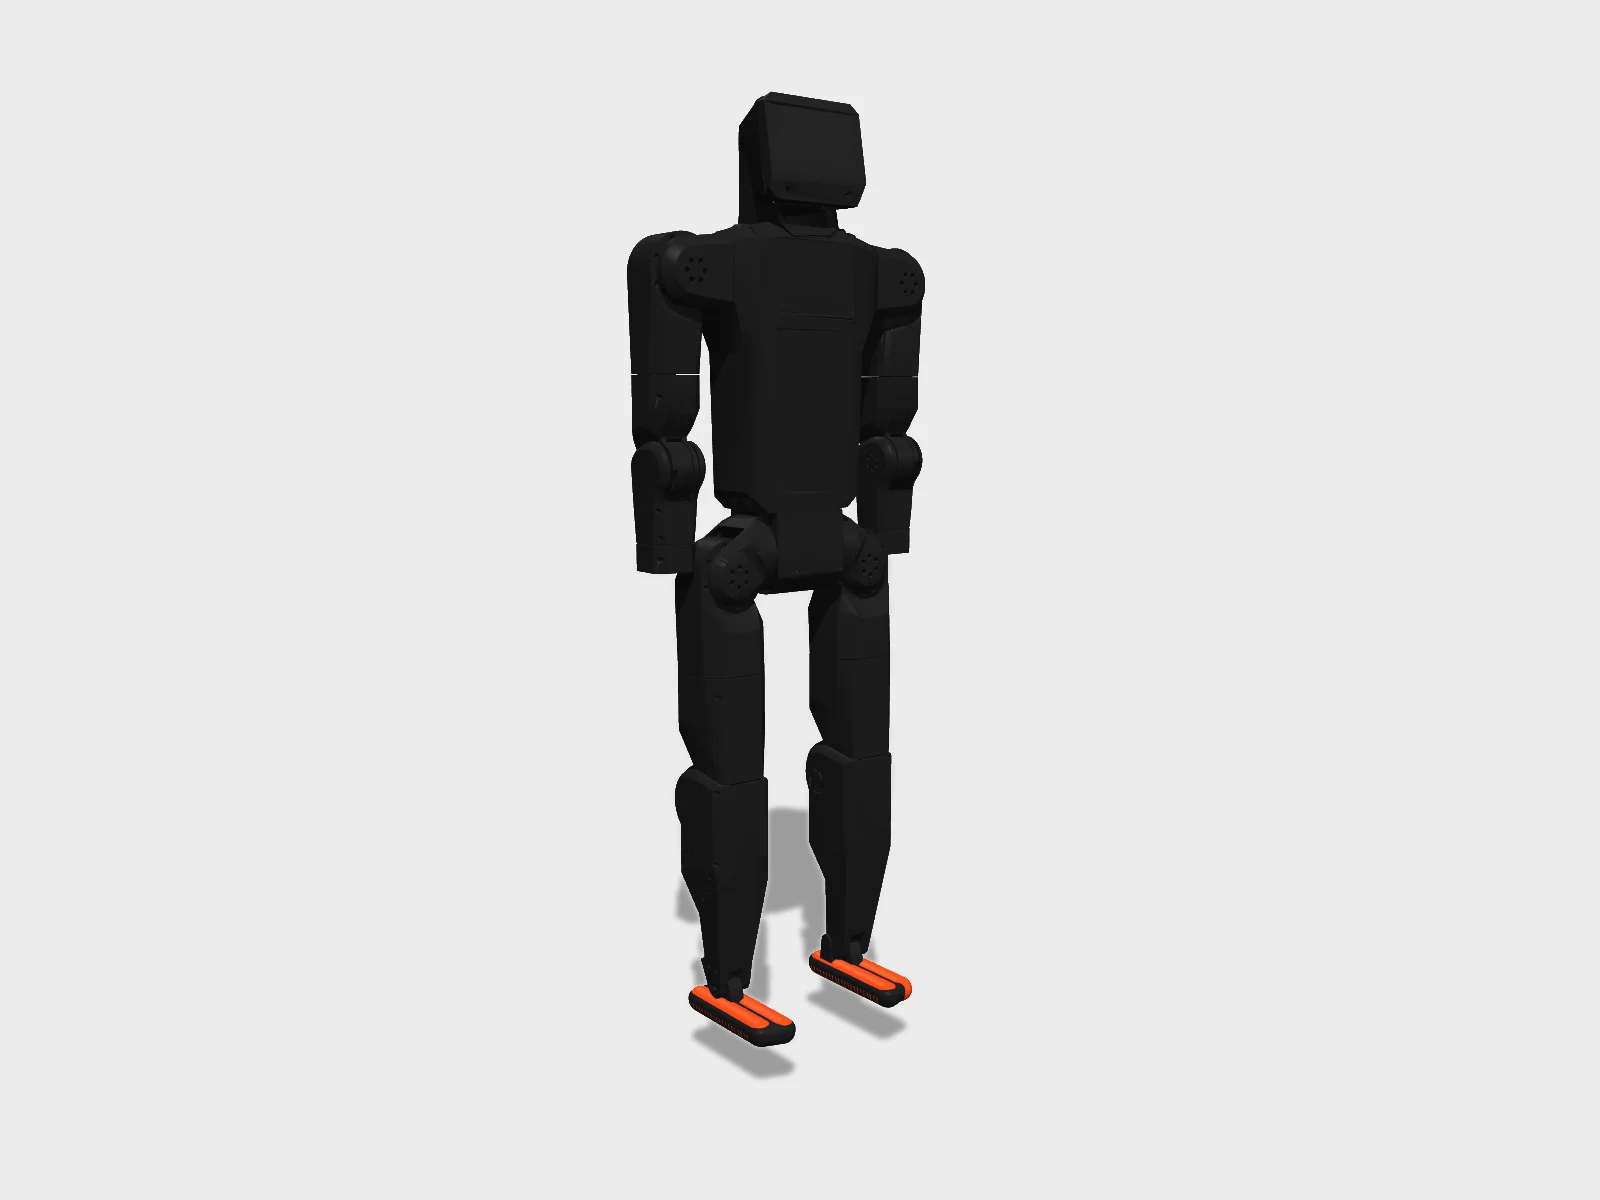 render
 render
Specifications
10/12 fields sourced| Heightspecs.heightCm | 140cm |
|---|---|
| Massspecs.massKg | 34kg |
| Degrees of freedomspecs.dof | 20 |
| Payloadspecs.payloadKg | 10kg |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | 240min |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | 8,999USD$8,999 for first 100 units (launch pricing, 2025) |
| Actuatorsspecs.actuators | RobStride RS00 x2, RS02 x6, RS03 x8, RS04 x4 |
| Computespecs.compute | Raspberry Pi 5 |
| Sensorsspecs.sensors | cameras, microphones, head sensor array |
| Year introducedyear | 2025 |
| Licenselicense.hw / .sw / .docs | Hardware: CERN-OHL-S-2.0Software: GPL-3.0 |
Note · K-Scale cancelled K-Bot pre-orders, refunded deposits and laid off most staff (Nov 4 2025), releasing IP openly. Repo LICENSE files: HW CERN-OHL-S, SW GPL-3.0 (press reported SW MIT); the runtime repos (firmware, robstride, kos-kbot, kbot-models) are MIT, while kbot_deployment and kscalelabs/docs have no license file. Arm lift ~10 kg; runtime up to 4 h (swappable battery). docs.kscale.dev did not resolve on 2026-09-24, so docs are linked at their GitHub source. The mechanical BOM (Kbot_BOM.xlsx, rev KD, 2025-11-07) and 83 STEP files are in kscalelabs/docs. 20 actuated DOF per the docs actuator table; compute is a Raspberry Pi 5 per the electrical page. URDF masses in kbot-models sum to 36.7 kg vs the 34 kg launch figure. Repos not archived but inactive since Nov 2025.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | yes | 10 | 10 |
| score = Σ weight × public | 100 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Fasteners | 20 | 610 | — |
| Electronics | 6 | 6 | — |
| Actuators | 4 | 20 | — |
| Other | 4 | 16 | — |
| Cabling | 3 | 6 | — |
| Compute | 2 | 2 | — |
| Sensors | 2 | 3 | — |
| Power | 2 | 2 | — |
| Structure | 2 | 6 | — |
Offers in CN · GLOBAL · US from 7 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 1 | — | — |
| Electrical | 4 | — | 2 |
| Arms | 3 | — | — |
| Legs | 5 | — | — |
| Torso | 2 | — | — |
| Final assembly | 2 | — | — |
| Head | 1 | — | — |
| Software | 1 | — | — |
| Bring-up | 4 | — | 4 |
| Simulation | 1 | — | — |
Fabrication: CNC ×11 · SLS print ×3 · Sheet metal ×1
Firmware
- Targets
- Raspberry Pi 5, Raspberry Pi OS 64-bit, running kscalelabs/firmware (Rust, faux_rtos / faux-rtos binary, single-threaded), RobStride RS00/RS02/RS03/RS04 actuators, flashed with RobStride's firmware releases via Motor Studio, 1 Mbit/s CAN, K-Bot power board (CAN control/query/status/power frames 0x1001-0x1004; its firmware is not published), Hiwonder IMU over USB serial (driver sets 230400 baud)
- Repo
- github.com/kscalelabs/firmware
- Calibrate
- Set CAN IDs (11-15 L arm, 21-25 R arm, 31-35 L leg, 41-45 R leg) and zero offsets per the docs zeroing table, then `robstride -i can0..can6 zero --ids ...` in the zeroing pose and verify with `robstride ... state`. Helper scripts are in kbot_deployment/scripts (set_zero_sta.sh, zero_actuator.sh, read_param.sh, set_max_torque.sh, reset_max_torques.sh, clear_faults.sh).
- Notes
- Deploy flow: kbot_deployment/scripts/run <policy.kinfer> symlinks model.kinfer and runs `sudo -E chrt 80 faux-rtos --lpf-cutoff-hz 10 --min-jerk-blend-ms 0`. The older KOS stack kscalelabs/kos-kbot (last commit 2025-05-02) and kinfer-kbot are superseded by kscalelabs/firmware. The robstride CLI/Python driver is kscalelabs/robstride. Power board Python protocol: kbot_deployment/powerboard/power_board.py; Rust: kscalelabs/kbot-pwrbrd. VR teleop: kscalelabs/kbot_vr_teleop (Meta Quest, WebRTC/GStreamer).
Policies
- Standing (stand_frozen.kinfer) · kinfer · github.comRun with kbot_deployment/scripts/run. The .kinfer file is in a Google Drive folder linked from the Raspberry Pi doc (1dsPG71_O6NO1QQJI__rrumO6KRzvx0Wz), which redirected to Google sign-in on 2026-09-25. Not in any public repo.
- Walking with keyboard velocity commands (eloquent_ride.kinfer) · kinfer · github.comSame Google Drive folder, sign-in required on 2026-09-25. Upstream: only turning in place and side-stepping work well, at command magnitude 0.2.
- Full-body joystick RL control (train + convert to .kinfer) · ksim (JAX/MuJoCo MJX) + kinfer · github.comconvert.py exports model.kinfer. No trained weights in the repo (checked 2026-09-25).
- K-Sim K-Bot walking training example · ksim (JAX/MuJoCo MJX) · github.comUses the kbot-headless model; examples/kbot/convert.py exports for deployment.
Caveats · stated by the package
- Upstream pins: K-Bot KD BoM, assembly guide, wiring and bearing-bore PDFs, STEP zip and docs pages from kscalelabs/docs@d4ca00ddc760197661d66495d0793b85dd31bea8 (2025-11-07); kscalelabs/kbot@76aba70e3372fecf3583ed6dbe5f379d44c8511c (2025-11-07); kbot-models@08defcedcdd3360f555c250a111f67eb39cbd778 (2025-10-02); firmware@d9a225a315b01a6d154a791dd535619097ebe744 (2025-09-04); robstride@eaba0e9a98bd39e7cc464bf6ca0d9f23b57e34d1 (2025-09-05); kbot_deployment@51fbee399effbf14f7eef3a5546a73d61a2ec02d (2025-08-18); kos-kbot@00fea353dd058a4d84c6897bfc27fde92c165f6e (2025-05-02); kbot-joystick@211f9a2e430d1dfbdc04e3f308614a829e14e559 (2025-10-23); ksim@52265b581b7268758a2cf77234c70e2559087365 (2025-10-29)
- K-Scale Labs shut down in November 2025 and cancelled and refunded K-Bot pre-orders. docs.kscale.dev did not resolve (DNS failure) on 2026-09-24, so all doc content was read from the GitHub source repo kscalelabs/docs (docs/robots/k-bot). The repos are not archived but have been inactive since November 2025.
- A BOM does exist: docs/robots/k-bot/assets/Kbot_BOM.xlsx (sheet 'RELEASE K-Bot KD BoM', revision KD, 2025-11-07), plus KBot_UID_to_Pic.xlsx (pictures and Chinese part names) and KBot_Parts.zip (83 STEP files). It covers mechanical parts only: machined, molded and sheet parts, fasteners, bearings and bushings. The kbot repo itself has no BOM and only points to the docs and Onshape.
- No electronics BOM exists. The actuator count and model are from the docs table, and compute, IMU, cameras, power board, battery, e-stop and cables are pieced together from docs pages and deployment code. Unknown: the IMU model, the buck converter, the power resistor value, the CAN interface hardware behind can0-can6 on the Pi 5, microphone and speaker parts, and battery cell count or voltage (the docs say 48 V bus and 4 V NCM cells).
- The power board is custom and no schematic, PCB or firmware for it is public (kbot-pwrbrd is only a Rust CAN client). This blocks an independent build unless you design a replacement.
- No prices are given anywhere upstream, so no line has unitUsd. The USD 8,999 launch price was for a finished robot, not a parts cost. RobStride actuators are the main cost and have no product URLs or prices in the docs.
- Conflicts between sources. (1) The docs joint-range table names the ankle 'dof_*_ankle_00', but the kbot-models URDF names it 'dof_*_ankle_02', and the docs actuator table (2x RS00, 6x RS02) only works if the ankle is an RS02; this package uses RS02. (2) Several parts have a different material in the BoM than in the STEP file name and UID sheet: KD-C-203X, KD-D-203X, KD-D-503X and KD-D-504X are 6061 in the BoM but SUS304 in the STEP and UID; KD-D-506L/R is 4340 steel in the BoM but 6061 in the STEP and UID; KD-D-107L/R is 5052 sheet in the BoM but 6061 in the STEP and UID. (3) Wrist rotors KD-C-501X/502X are qty 1 in the BoM but 2 in the STEP files ('TWO_') and the UID sheet; this package uses 2.
- BoM gaps: shoulder cover back KD-B-105L/R has no process or material and no STEP file. The upper and lower bicep shells (KD-C-201..302) have a blank quantity (1 per side assumed). The M8 ankle pivot washer KD-D-553F has no quantity. The BoM header says 'per Robot', but some fastener counts look per side (e.g. 9 foot-to-tread bolts). Most fasteners have no supplier; only a few McMaster, Amazon and MISUMI links are given, and one (91294A128 on an M5x12 SHCS row) looks like a countersunk PN.
- Head: the BoM includes a 'Vim4 Mount' (KD-E-107X), which suggests an earlier Khadas VIM4 computer, but the current docs use a Raspberry Pi 5. The assembly guide does not cover the head or battery enclosure.
- No torque values or step times are published. The assembly guide is titled a 'Rough Guide' and is pictures plus fastener callouts. The docs call the wiring harness 'the least reliable part of the robot' and warn that the JST CAN connectors can tear off the shoulder actuators.
- The trained policies (stand_frozen.kinfer, eloquent_ride.kinfer) are only in a Google Drive folder that needs sign-in. The public repos have training code, not weights.
- Licensing: kbot repo hardware is CERN-OHL-S (LICENSE-HW) and software GPL-3.0 (LICENSE). But the software repos the robot actually runs (kscalelabs/firmware, robstride, kos-kbot, kinfer-kbot, ksim, kbot-models, kbot-joystick) are MIT, and kbot_deployment has no LICENSE file (all rights reserved by default). The kscalelabs/docs repo, which hosts the BoM, STEP zip and PDFs, has no LICENSE file. The docs pages say hardware is CERN-OHL-S.
- The URDF masses in kbot-models sum to 36.7 kg, while the registry says 34 kg.
- RobStride firmware and Motor Studio are third-party (github.com/RobStride), and supply depends on RobStride. K-Scale modified the RS03/RS04 CAN plugs, so stock actuators need re-termination per kbot_wiring.pdf.
Package kscale/kbot@0.1.0 · upstream K-Bot KD BoM, assembly guide, wiring and bearing-bore PDFs, STEP zip and docs pages from kscalelabs/docs@d4ca00ddc760197661d66495d0793b85dd31bea8 (2025-11-07); kscalelabs/kbot@76aba70e3372fecf3583ed6dbe5f379d44c8511c (2025-11-07); kbot-models@08defcedcdd3360f555c250a111f67eb39cbd778 (2025-10-02); firmware@d9a225a315b01a6d154a791dd535619097ebe744 … (full pins in caveats) · 27 package sources
Models, repositories, links
11 links- URDFgithub.com/kscalelabs/kbot-modelsmodel
- Repogithub.com/kscalelabs/kbotgithub.com
- Repogithub.com/kscalelabs/ksimgithub.com
- Repogithub.com/kscalelabs/kscalegithub.com
- Repogithub.com/kscalelabs/kos-kbotgithub.com
- Repogithub.com/kscalelabs/kbot-modelsgithub.com
- Repogithub.com/kscalelabs/docsgithub.com
- Repogithub.com/kscalelabs/firmwaregithub.com
- Repogithub.com/kscalelabs/robstridegithub.com
- Repogithub.com/kscalelabs/kbot_deploymentgithub.com
- Docsgithub.com/kscalelabs/docs/tree/master/docs/robots/k-botgithub.com
Videos
2 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning K-Bot
Papers using K-Bot
20251
- Company
K-Scale Labs shuts down and releases its IP
K-Scale Labs canceled K-Bot orders and refunded deposits after failing to raise funding, and released its intellectual property as open source.
K-Scale LabsK-Scale K-BotK-Scale Z-Bot (Zeroth Bot)humanoidsdaily.commikekalil.com
Sources
last checked 2026-09-25- [1]K-Bot repogithub.com/kscalelabs/kbotchecked 2026-09-24
- [2]K-Bot mechanical BOM (Kbot_BOM.xlsx, rev KD)github.com/kscalelabs/docs/blob/master/docs/robots/k-bot/assets/Kbot_BOM.xlsxchecked 2026-09-25
- [3]K-Bot docs: mechanical (RobStride actuator table)github.com/kscalelabs/docs/blob/master/docs/robots/k-bot/mechanical.mdchecked 2026-09-25
- [4]K-Bot docs: electrical (Raspberry Pi 5, 48 V bus)github.com/kscalelabs/docs/blob/master/docs/robots/k-bot/electrical.mdchecked 2026-09-25
- [5]DesignSpark launch specsrs-online.com/designspark/k-scale-labs-launches-k-bot-americas-first-open-source-humanoid-robotchecked 2026-09-24
- [6]Humanoids Daily shutdownhumanoidsdaily.com/news/k-scale-labs-cancels-k-bot-orders-open-sources-all-ip-after-funding-failschecked 2026-09-24
- [7]Mike Kalil: K-Scale shuts downmikekalil.com/blog/k-scale-labs-shuts-down/checked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
Also by K-Scale Labs
Cite this page
humanoidrobots.systems. “K-Scale K-Bot specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/kscale/kbot
Machine-readable: /data.json (record kscale/kbot).