roboparty/roboto-origin · spec sheet
RoboParty ROBOTO_ORIGIN specs
Fully open-source DIY running/jumping humanoid prototype whose structure, electronics, training and deployment code are all published; buildable from Taobao parts and JLC prototyping.
Media
4 items · credited and licensed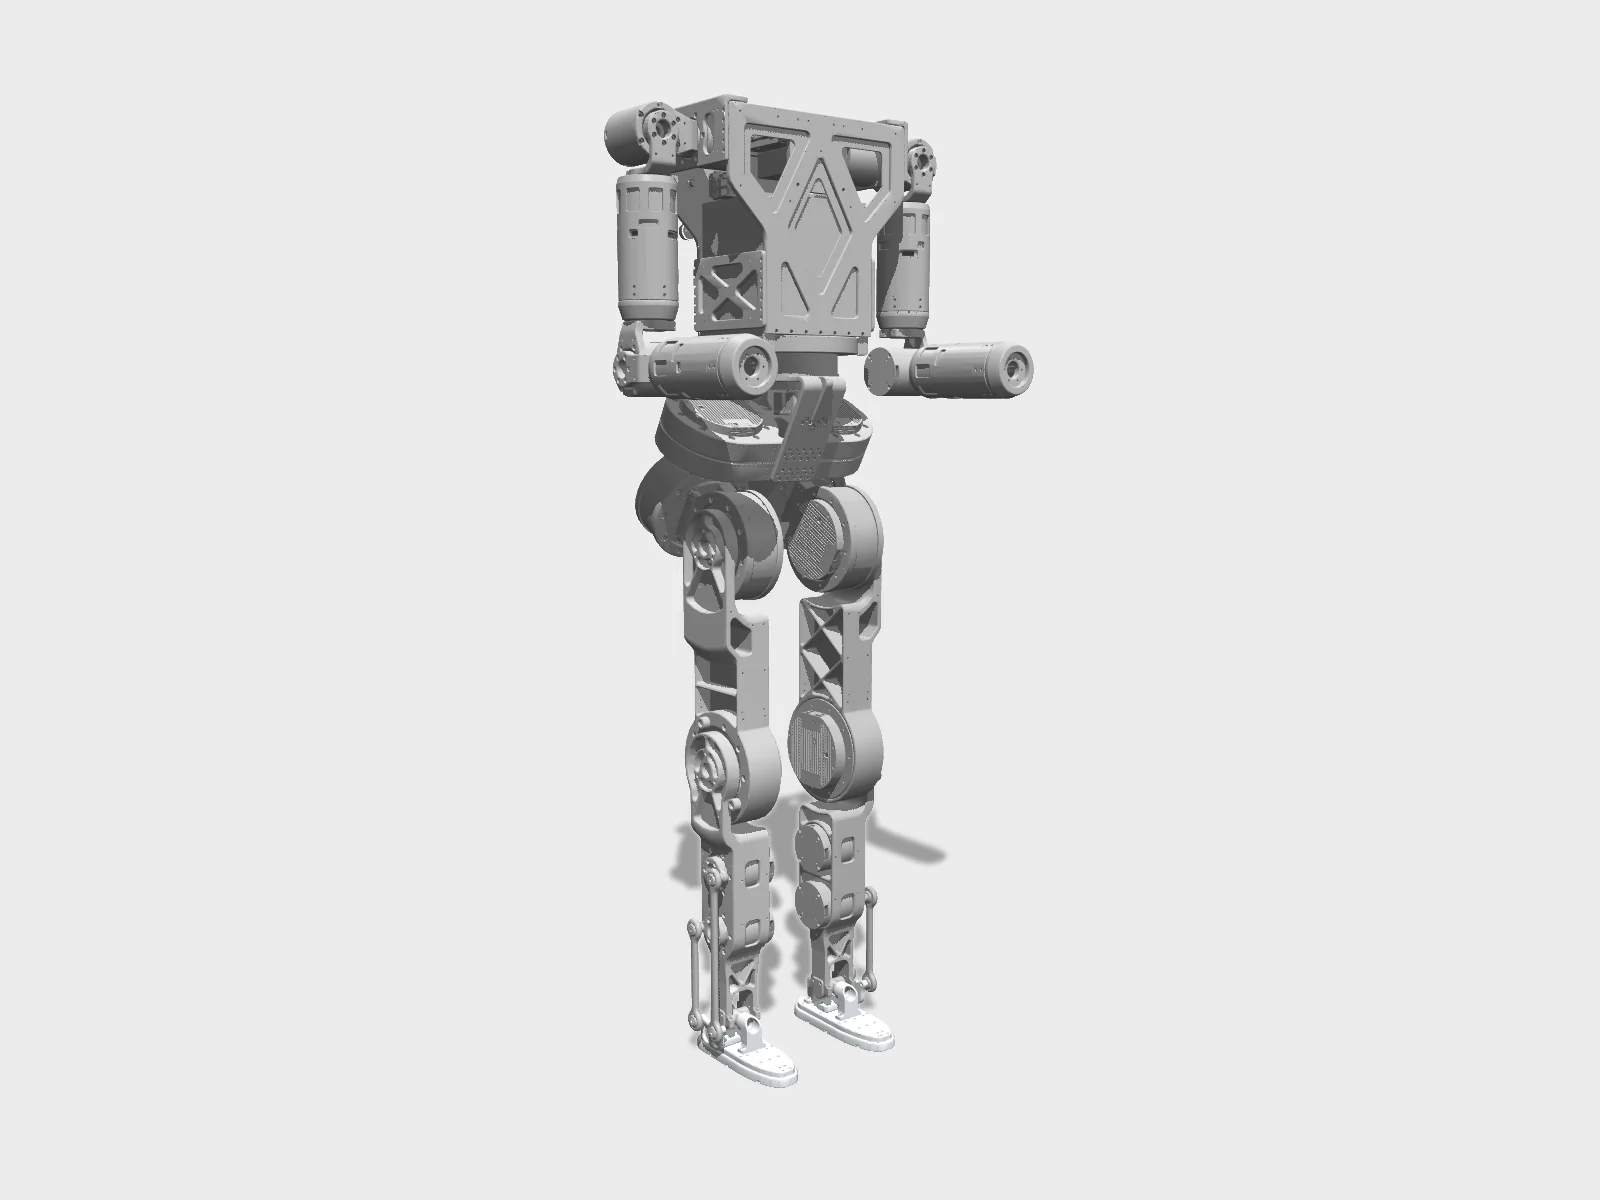 render
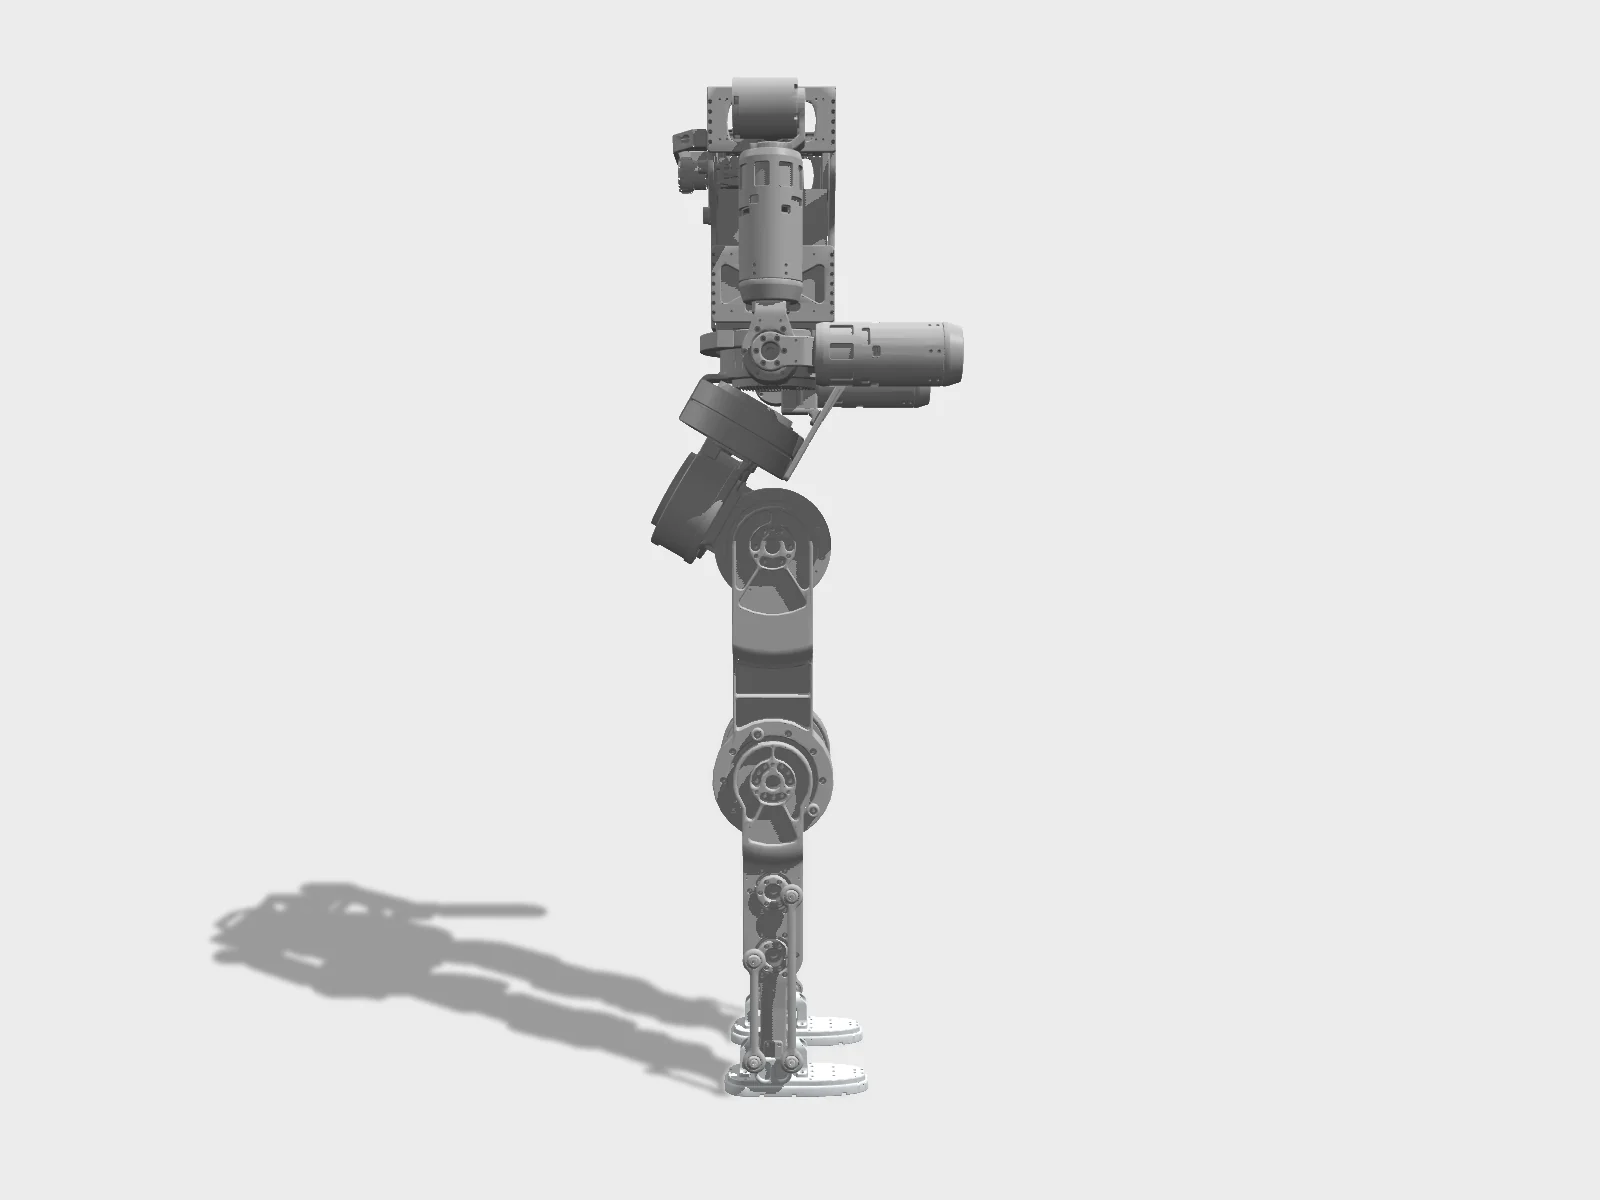 render
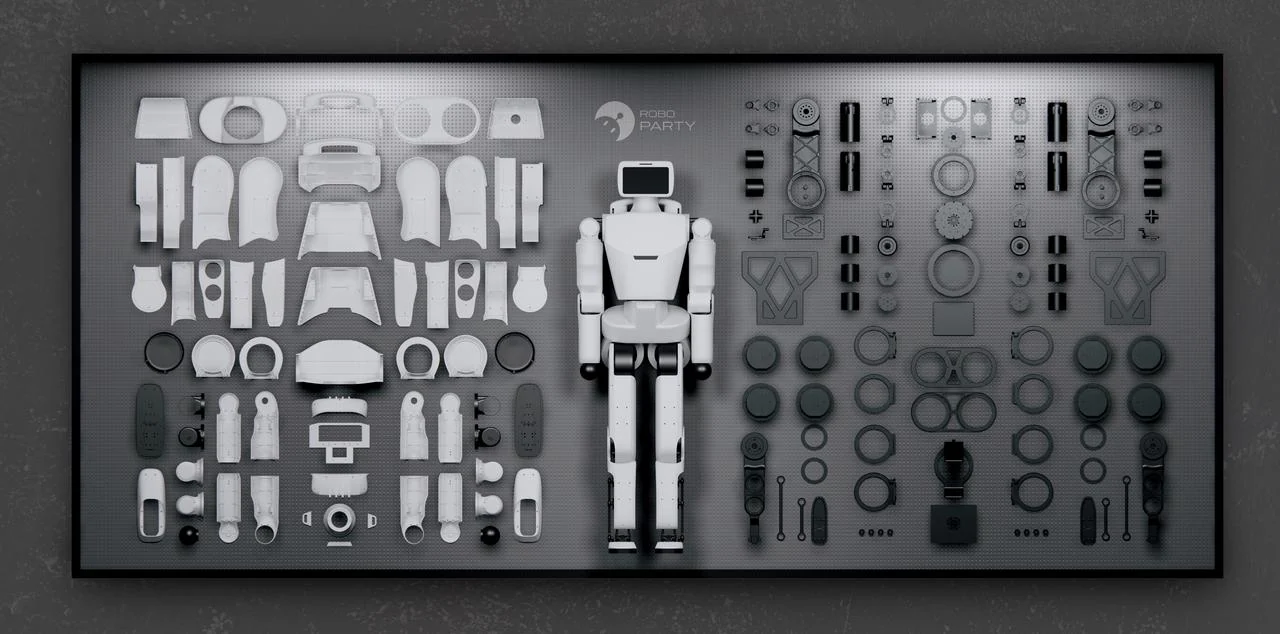

Specifications
8/12 fields sourced| Heightspecs.heightCm | 125cm |
|---|---|
| Massspecs.massKg | 34kg |
| Degrees of freedomspecs.dof | 23 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | 3m/s |
| Runtimespecs.runtimeMin | 120min |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourced |
| Actuatorsspecs.actuators | 120 N·m peak joint torque (maker claim) |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | Intel D435i depth camera and 3D LiDAR (both optional) |
| Year introducedyear | 2025 |
| Licenselicense.hw / .sw / .docs | Hardware: CERN-OHL-W-2.0Software: GPL-3.0-onlyDocs: CC-BY-SA-4.0 |
Note · Company founded Feb 2025; prototype built in ~4 months. Repo created Dec 2025, actively updated. Uses Isaac Lab / ROS 2. roboto_origin is a snapshot aggregation of the module repos. Specs are maker claims from the Original-0310 brochure in rpo_hardware (not in the README): 1.25 m, 34 kg, 23 DOF, 3 m/s, 120 N·m peak joint torque, 48 V 15 Ah battery, >2 h runtime. URDF and MJCF in modules/rpo_description. Licensing is per module (LICENSES.md): hardware (rpo_hardware, rpo_description, rpo_appearance) CERN-OHL-W-2.0; RoboParty software and firmware GPL-3.0-only; rpo_hardware docs CC-BY-SA-4.0; roboparty_train BSD-3-Clause; orangepi-build GPL-2.0. RoboParty names and logos are not licensed. Walking, motion-tracking, get-up and parkour policies ship as ONNX in roboparty_inference / roboparty_deploy.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | yes | 10 | 10 |
| score = Σ weight × public | 100 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Fasteners | 9 | 1,168 | — |
| Cabling | 8 | 25 | — |
| Electronics | 6 | 6 | — |
| Power | 6 | 6 | — |
| Structure | 6 | 23 | — |
| Actuators | 2 | 23 | — |
| Sensors | 2 | 2 | — |
| Other | 2 | 2 | — |
| Compute | 1 | 1 | — |
Offers in CN from 4 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 3 | — | — |
| Preparation | 1 | — | 1 |
| Legs | 1 | — | — |
| Hip | 2 | — | — |
| Torso | 2 | — | — |
| Arms | 1 | — | — |
| Electrical | 3 | — | 3 |
| Bring-up | 5 | — | 2 |
| Calibration | 1 | — | 1 |
| Simulation | 1 | — | — |
Fabrication: CNC ×26 · FDM print ×6
Firmware
- Targets
- RBE board USB-to-CAN (4x STM32G431), RDK X5 image (x5-rdk-gen), Orange Pi 5 Plus image / RT kernel (orangepi-build), Damiao DM-J4340P / DM-J10010L motor IDs (vendor tool)
- Repo
- github.com/Roboparty/roboparty_deploy
- Calibrate
- Pin calibration (4x18 arm pins, 4x22 leg pins, waist limit block or printed waist jig), then scripts/set_zero.py or the /set_zeros ROS 2 service. motor_zero_offset for waist yaw is 2.093 rad (limit block) or 0.0 (printed jig) in robots/rpo/robot.yaml.
- Notes
- ROS 2 Humble deployment (roboparty_deploy, GPL-3.0-only; submodules roboparty_inference, roboparty_motors, roboparty_imu, roboparty_camera). The motors are Damiao DM over SocketCAN at 1 Mbit/s: can0 left leg (6), can1 right leg + waist (7), can2 left arm (5), can3 right arm (5), master_id_offset 16. The HiPNUC IMU runs on serial at 921600 baud. USB-to-CAN firmware is roboparty_firmware/roboto_usb2can (Zephyr, gs_usb). Board images are built with roboparty_firmware/x5-rdk-gen and orangepi-build (GPL-2.0).
Policies
- walk (default velocity-tracking policy) · Isaac Lab + RSL-RL (roboparty_train), ONNX via roboparty_inference · github.comStarted with `./tools/start_robot.sh --robot rpo --policy default`
- walk, AMP style · Isaac Lab + RSL-RL AMP · github.com
- walk, attention encoder · Isaac Lab + RSL-RL · github.com
- motion tracking: wave / dance (BeyondMimic) · Isaac Lab BeyondMimic · github.comThe beyondmimic config also loads policy_dance0.onnx and policy_dance1.onnx with motions/wave.npz, dance0.npz and dance1.npz; LB/RB switch mode and sequence
- get up from the ground · Isaac Lab BeyondMimic-style motion tracking · github.comPaired with motions/getup.npz and the default walking policy
- interruptible walking · Isaac Lab + RSL-RL · github.com
- parkour with depth · Isaac Lab + RSL-RL · github.comNeeds a RealSense D435i and `./tools/start_camera.sh --policy parkour` publishing /depth_obs
Caveats · stated by the package
- Upstream pins: roboto_origin@c71fd9287d28104dca111d7c25b908fa3f45f8e4 (2026-08-18, snapshot aggregation of rpo_hardware, roboparty_deploy, roboparty_train, roboparty_firmware, rpo_description); roboparty_deploy@a8a0f1557cc5d085234b8bac248a8f543342f531 (2026-08-19); roboparty_inference@c4238d1560bc795e61226074f4ee4b0a256a8901 (2026-09-10). Hardware V2.0: parts list v1.1.3, CNC BOM v1.0.2 (2026-03-04), 3D BOM v2.0.0 (2026-02-24), RBE_PWR_HUB V2.1 (2026-04-09), installation manual 0428; priced D-BOM ATOM 01 v1.0.1 (2026-01-05).
- Licensing is split by module. Hardware (rpo_hardware, rpo_description, rpo_appearance) is CERN-OHL-W-2.0; software and firmware are GPL-3.0-only; rpo_hardware docs are CC-BY-SA-4.0; roboparty_train is BSD-3-Clause; orangepi-build is GPL-2.0. The root GPL-3.0 LICENSE covers only the aggregation layer. RoboParty/RPO/Roboto Origin names and logos are trademarks and are not licensed.
- Third-party and vendor files in rpo_hardware (for example motor STEP models) are not relicensed. Upstream says to treat any file with no identifiable license as reference-only.
- Two BOM generations exist. The V2.0 parts list v1.1.3 has quantities but no prices. The only priced BOM (assets/BOM_EN.md, ATOM 01 v1.0.1, 2026-01-05, total ¥49,713) is V1-era: HI13 IMU, discrete USB-to-CAN/hub/DC-DC boards, 4x of each arm part. Its CNY prices are only indicative for V2.
- No USD prices are published. The CNY figures are in offer notes; the V1 D-BOM's CNC subtotal was ¥15,670. CNC prices depend on the shop and batch.
- Taobao/Tmall links come from the V1 D-BOM (tracking parameters removed) and may be stale or region-locked. Many V2 lines (RTC, cooling kit, antenna, switch, voltmeter, charger, gamepad, bearings, fasteners, harnesses) have no vendor link or spec beyond the name.
- The V2.0 mechanical README links 安装手册-0317.pdf and 插销标定说明.pdf, which are not in the repo. The manual in the repo is 安装手册_0428.pdf and pin calibration is its section 2.3. The deploy README points to Feishu wiki pages (motor IDs, wiring, safety guide) that were not checked here.
- Harness lengths conflict. The parts list gives Leg01/Leg02 as 25 cm, but the wiring guide gives 20 cm. The GH1.25 lead lengths also differ between the two documents. No harness drawings or connector pinouts are published for self-crimping.
- Fastener quantities in the parts list are kit quantities (spares included), not counted per step. The manual's handle step uses M6x10, but the BOM lists only M6x12 and M6x16. No torque values are published except 'tighten diagonally, re-tighten twice' for the hip plates.
- The CNC folder includes RB000165 脚底板 (sole plate) drawings that are not in the CNC BOM or parts list. The 3D-print folder has head top/bottom, chest bracket 3.0 and a camera-mount zip with no BOM quantity, so they are not listed here.
- The parts list gives 8 calibration pieces, but the calibration folder's file names add up to 13 (plus a smaller rear-thigh variant). File-name quantities are used here.
- rpo_appearance shells (53 STL files) are marked 'static display only, printing not recommended' because of routing and seam issues, so they are not included.
- The RBE board BOM specifies STM32G431C8T6, but the roboto_usb2can README specifies STM32G431CBT6. Upstream does not say outright which firmware the 4-channel RBE board ships with or how to flash it.
- Specs come from the Original-0310 brochure: 1.25 m, 34 kg, 23 DOF, 48 V 15 Ah, 3 m/s, 120 N·m peak joint torque, >2 h runtime. They are maker claims and have not been verified.
- The docs site roboparty.com/roboto_origin/doc is a JavaScript app and could not be mined here, so it may hold steps not captured.
- The published policies are ONNX files with no separate real-robot validation report. Upstream disclaims all liability and requires simulation validation and a safety gantry before deploying modified code.
Package roboparty/roboto-origin@0.1.0 · upstream roboto_origin@c71fd9287d28104dca111d7c25b908fa3f45f8e4 (2026-08-18, snapshot aggregation of rpo_hardware, roboparty_deploy, roboparty_train, roboparty_firmware, rpo_description); roboparty_deploy@a8a0f1557cc5d085234b8bac248a8f543342f531 (2026-08-19); roboparty_inference@c4238d1560bc795e61226074f4ee4b0a256a8901 (2026-09-10). Hardware V2.0: parts list v1.1.3 … (full pins in caveats) · 22 package sources
Models, repositories, links
11 links- URDFgithub.com/Roboparty/roboto_origin/blob/main/modules/rpo_description/urdf/rpo.urdfmodel
- MJCFgithub.com/Roboparty/roboto_origin/blob/main/modules/rpo_description/mjcf/rpo.xmlmodel
- Repogithub.com/Roboparty/roboto_origingithub.com
- Repogithub.com/Roboparty/rpo_hardwaregithub.com
- Repogithub.com/Roboparty/rpo_descriptiongithub.com
- Repogithub.com/Roboparty/roboparty_traingithub.com
- Repogithub.com/Roboparty/roboparty_deploygithub.com
- Repogithub.com/Roboparty/roboparty_inferencegithub.com
- Repogithub.com/Roboparty/roboparty_firmwaregithub.com
- Siteroboparty.com/roboto_origin/docroboparty.com
- Docsroboparty.com/roboto_origin/docroboparty.com
News and papers
0 stories · 0 papersNews mentioning ROBOTO_ORIGIN
Papers using ROBOTO_ORIGIN
Sources
last checked 2026-09-25- [1]Official repo READMEgithub.com/Roboparty/roboto_originchecked 2026-09-24
- [2]roboto_origin LICENSES.md (per-module license scope)github.com/Roboparty/roboto_origin/blob/main/LICENSES.mdchecked 2026-09-25
- [3]rpo_hardware LICENSES.md (CERN-OHL-W-2.0 / GPL-3.0-only / CC-BY-SA-4.0)github.com/Roboparty/roboto_origin/blob/main/modules/rpo_hardware/LICENSES.mdchecked 2026-09-25
- [4]ROBOTO Origin brochure (1.25 m, 34 kg, 23 DOF)github.com/Roboparty/roboto_origin/blob/main/modules/rpo_hardware/V2.0/roboto_origin_mechanic/00_Docs/Original-0310.pdfchecked 2026-09-25
- [5]roboparty_inference: ONNX policiesgithub.com/Roboparty/roboparty_inference/tree/main/robots/rpo/modelschecked 2026-09-25
Suggest a correction
Related
Cite this page
humanoidrobots.systems. “RoboParty ROBOTO_ORIGIN specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/roboparty/roboto-origin
Machine-readable: /data.json (record roboparty/roboto-origin).