fourier/n1 · spec sheet
Fourier N1 specs
1.3 m, 38 kg humanoid launched April 2025 with open-released BOM, design drawings, assembly guides and base software.
Media
3 items · credited and licensed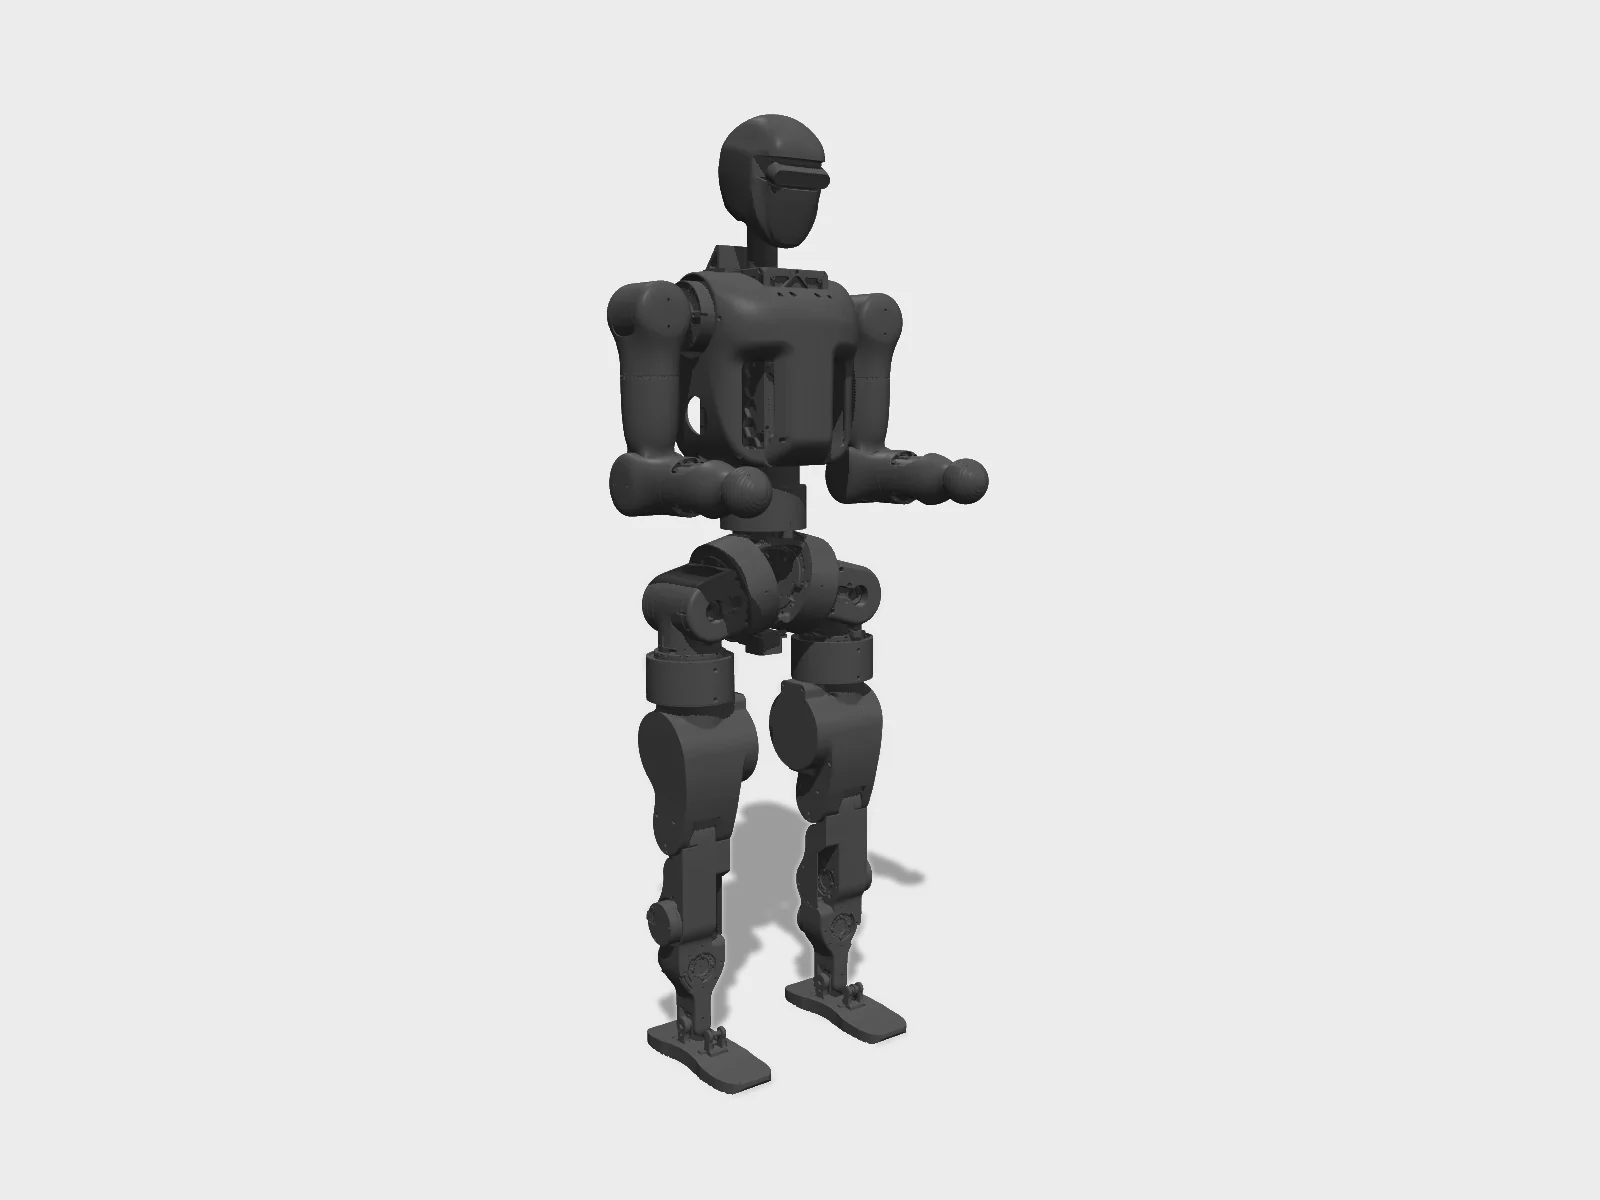 render
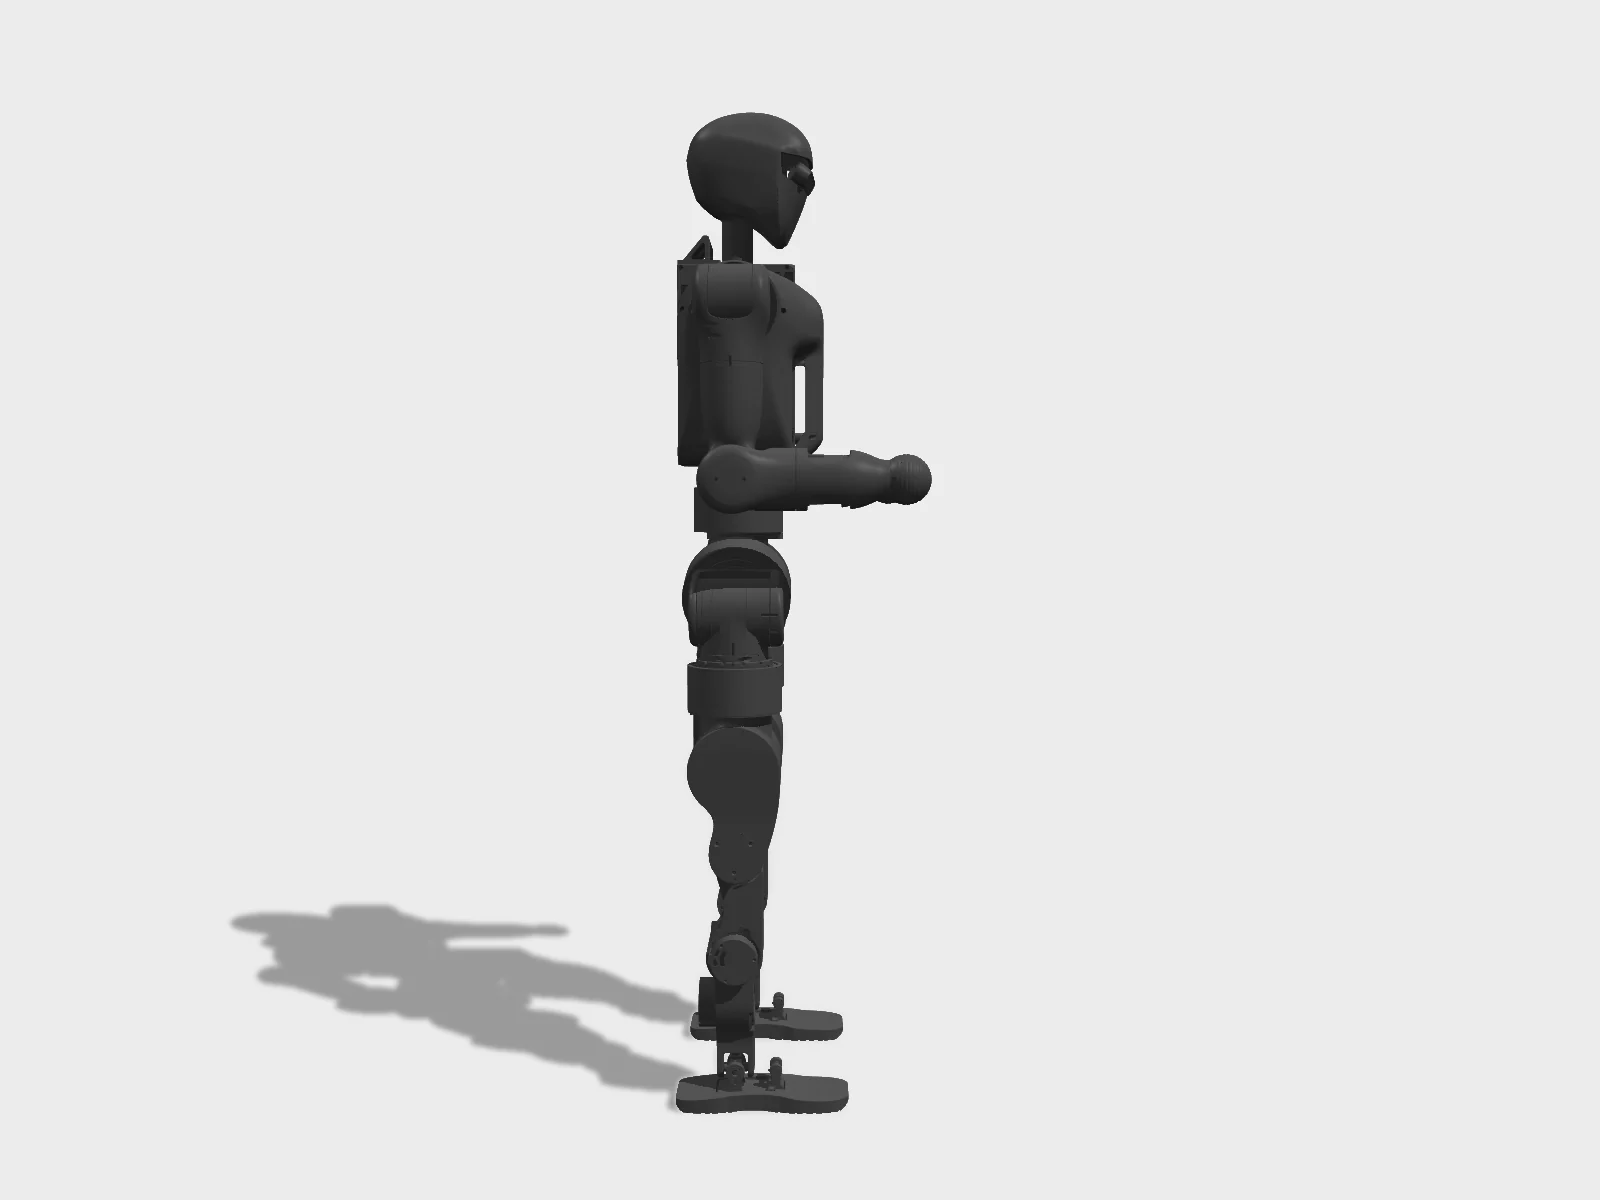 render
Specifications
7/12 fields sourced| Heightspecs.heightCm | 130cm |
|---|---|
| Massspecs.massKg | 38kg |
| Degrees of freedomspecs.dof | 23 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | 3.5m/s |
| Runtimespecs.runtimeMin | 120min |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourcedNo price announced at launch; press reported pricing as undetermined. |
| Actuatorsspecs.actuators | Fourier FSA actuators; URDF effort limits 95 N·m x4, 54 N·m x7, 30 N·m x12 |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | 2025 |
| Licenselicense.hw / .sw / .docs | Software: MIT |
Note · The 23 DOF count excludes hands. The open-source package is published as the docs repo FFTAI/fourier-grx-N1 (MIT); there is no FFTAI/N1 repo. Press (Yicai, TMTPost) called it the first open-source humanoid; that claim is disputed. The MIT license covers the docs repo; no license for the hardware files was found, so hw is left undeclared. The N1 URDF (Wiki-GRx-Models, FourierN1 branch) sets a 95 N·m max effort on the four strongest joints; launch press said 96 N·m peak. Walking policies (TorchScript policy_jit_walk.pt) ship in Wiki-GRx-Deploy (FourierN1 branch) with Isaac Gym training (Wiki-GRx-Gym) and MuJoCo sim2sim (Wiki-GRx-Mujoco). fourier-grx itself is a closed binary.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | no | 15 | 0 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | yes | 10 | 10 |
| score = Σ weight × public | 85 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Actuators | 3 | 23 | — |
| Electronics | 3 | 3 | — |
| Sensors | 2 | 2 | — |
| Power | 2 | 2 | — |
| Other | 2 | 2 | — |
| Compute | 1 | 1 | — |
Offers in CN from 1 vendor
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 1 | — | — |
| Legs | 1 | — | — |
| Arms | 1 | — | — |
| Torso and head | 1 | — | — |
| Waist and hip | 1 | — | — |
| Final assembly | 1 | — | 1 |
| Electrical bring-up | 1 | — | 1 |
| Firmware | 1 | — | — |
| Calibration | 1 | — | 1 |
| First motion | 2 | — | 2 |
| Sim and policy | 1 | — | 1 |
Fabrication: CNC ×9
Firmware
- Targets
- Main computer: fourier-grx (.deb, Ubuntu 22.04 x86-64, Python 3.11; closed binary run.bin, no license), Fourier FSA actuators x23 (FSA v2 protocol over Ethernet, 48 V; actuator firmware not published), USB IMU (serial, 500 Hz)
- Repo
- fftai.github.io/fourier-grx-N1
- Calibrate
- TASK_SET_HOME (TID 999): locating pins in every joint hole, run from the gamepad (L1 select, L2 confirm) or the developer API; pass = all-zero array (any value >1 means >1° offset). Remove all pins afterwards.
- Notes
- fourier-grx releases are downloaded from Fourier's Tencent COS bucket (links in docs/update.md): 4.1.21 stable (2025-10-30, the only stable build still supported) and 4.2.2 preview (2025-12-16). From 4.0.0 the developer API uses radians: use developer_radian/ in Wiki-GRx-Deploy, not developer/. The FSA SDK (FFTAI/fourier_actuator_sdk) ships only prebuilt libfsav2 binaries plus Python (fi_fsa) examples and has no LICENSE. Default actuator IP is 192.168.137.101 out of the box; N1 joint IPs are listed in docs/reference/joint_sequence.md. On some ARM hosts zenoh stalls, so x86 is recommended.
Policies
- Walk (TorchScript, developer API, radians) · PyTorch JIT (Isaac Gym / legged_gym) · github.comRun by developer_radian/demo_walk.py; also copied at robots/N1/policy/ in Wiki-GRx-Mujoco for sim2sim.
- Walk, refined (TorchScript) · PyTorch JIT (Isaac Gym / legged_gym, FourierN1_refine branch of Wiki-GRx-Gym) · github.comAdded with fourier-grx 4.2.2 (demo_walk_refined.py).
- Built-in tasks: stand/walk/run (up to 3.5 m/s), get-up front/back, squat, single-leg stand, lie down, box-carry arm pose · fourier-grx (closed binary) · github.comBundled in the fourier-grx .deb and triggered by task ID (e.g. 3551 get-up); weights and code are not published.
Caveats · stated by the package
- Upstream pins: Hardware: Fourier official Baidu Netdisk share 'Fourier-N1开源资料' (share created 2025-04-10; EBOM Ebom-Fourier N1-V1.3.1.xlsx dated 2025-04-11; CAD, drawings, assembly guide FourierN1装配工艺指导书_A01.pdf and six videos dated 2025-04-10; listing read 2026-09-25, contents not downloaded). Docs: FFTAI/fourier-grx-N1@c8dca3ded1b6f2c505cbc3ec6b55a34325e32ece (2026-03-17, docs v1.0.1; latest fourier-grx 4.1.21 stable 2025-10-30, 4.2.2 preview 2025-12-16). Model: FFTAI/Wiki-GRx-Models@f8e683f00d1d99deb882deb9dfce6030095b466a (FourierN1, 2025-05-10). Deploy: FFTAI/Wiki-GRx-Deploy@950f3d86fd6afd1c86ea94802bf3754b6163199d (FourierN1, 2025-12-16). Train: FFTAI/Wiki-GRx-Gym@25693a5eb8bcc4a4896b9f44778230a28c49d0b3 (FourierN1, 2025-08-01). Sim2sim: FFTAI/Wiki-GRx-Mujoco@5c30ece8683a3fe48f903adfa5bb355f6bfb2c9c (FourierN1, 2025-12-05). MJCF: google-deepmind/mujoco_menagerie fourier_n1 @71f066ad0be9cd271f7ed58c030243ef157af9f4 (2026-07-04). Actuator SDK: FFTAI/fourier_actuator_sdk@8e7c3b0e5aec6d3a6176d85bb8ea6beb44763f6c (2026-01-30).
- HARDWARE LICENSE: none found. The only LICENSE files are MIT on the docs repos (FFTAI/fourier-grx-N1 and the redirect stub fourier-grx-N1/fourier-grx-N1.github.io); the docs repo was GPL-3.0 until 2025-05-18. The Baidu hardware pack (EBOM, SolidWorks CAD, drawings, assembly guide, videos) carries no license in its listing, so treat it as all rights reserved: fine to study, not licensed to manufacture, modify or redistribute. Ask Fourier (gr_opensource@fftai.com, per launch press) before selling kits or rehosting CAD. The URDF repo is GPL-3.0, the Deploy/Gym/Mujoco repos are LGPL-3.0, the menagerie MJCF is Apache-2.0, and fourier_actuator_sdk has no license.
- The hardware pack is not on GitHub. It is only on Baidu Netdisk (5.6 GB: 355 CAD/drawing files, 6 assembly videos totalling about 4.2 GB, 1 EBOM xlsx, 1 PDF assembly guide), which needs a Baidu account to download and is hard to reach outside China. The site the launch press points to (fourier-grx-n1.github.io) was re-created on 2025-06-23 as a redirect stub and archived snapshots show it only ever held SDK docs. A GitHub 'mirror' (TheWisp/Fourier-N1) is an empty repo.
- The EBOM (Ebom-Fourier N1-V1.3.1.xlsx) and the assembly process guide (FourierN1装配工艺指导书_A01.pdf) were NOT read, because the download needs a login. So this package has no per-robot quantities for fabricated parts (fabricate qty = number of distinct drawings per part-number group), no materials or finishes, no fasteners, bearings, pins, harness or connectors, no part numbers, no torques and no prices. Bounty: transcribe the EBOM and the PDF guide.
- Actuator model per joint is unknown. The URDF gives three effort classes (95 N·m x4, 54 N·m x7, 30 N·m x12 = 23), and the CAD folder contains FSA80-29E, FSA60-43E, FSA36B-14-80Z-A00, a '45-30E' model and a customised hip-yaw actuator, but no readable source maps them to joints. Launch press says 'FSA 2.0'. The registry's '96 N·m peak' does not match the URDF's 95 N·m effort limit.
- Many CAD parts are 'replacement models' (数据替代模型), i.e. simplified stand-ins for the actuators, so the CAD is not a full actuator design. FSA internals, PCBs (GR1-02-PCB_*, GR2-BAT-*) and battery electronics are Fourier parts with no schematics, gerbers or firmware.
- Almost everything is SolidWorks native (199 SLDPRT, 21 SLDASM, 100 SLDDRW). Only 5 STEP/STP files, 2 PDFs and 1 STL (the head) are neutral formats, so you need SolidWorks to read most drawings.
- Unknown specs: battery voltage and capacity, main computer model, IMU model, camera model, and charger rating are not in any readable source. The actuator SDK README says 48 V DC per FSA. Runtime (>2 h), speeds (0.5 m/s walk, 3.5 m/s max run) and the aluminium + engineering plastic structure come from launch press, not from engineering documents.
- No price or purchase channel for N1 parts or FSA actuators was verified. Every actuator/electronics offer is 'contact Fourier', with no store page. The registry lists availability 'buy', but no buy link or price was found.
- The robot docs, SDK and tasks are Chinese-only. Parts of the docs are copied from GR2 (the default login and hotspot name pattern is gr2m25{month}{serial}). fourier-grx itself is a closed binary: calibration, the built-in gaits and the get-up routines cannot be inspected or rebuilt.
- Version drift: the CAD and videos are dated 2025-04-10 and the EBOM is V1.3.1 (2025-04-11). The URDF is from 2025-05-10, and the software is at 4.1.21/4.2.2 (late 2025). The docs mention several IMU models and hardware changes after launch, and there is no hardware changelog.
- Minimal assembly steps: step bodies follow the six video titles and the docs. Detailed sub-steps, left/right specifics, fastener torques and harness routing live only in the unread PDF guide and videos.
Package fourier/n1@0.1.0 · upstream Hardware: Fourier official Baidu Netdisk share 'Fourier-N1开源资料' (share created 2025-04-10; EBOM Ebom-Fourier N1-V1.3.1.xlsx dated 2025-04-11; CAD, drawings, assembly guide FourierN1装配工艺指导书_A01.pdf and six videos dated 2025-04-10; listing read 2026-09-25, contents not downloaded). Docs: FFTAI/fourier-grx-N1@c8dca3ded1b6f2c505cbc3ec6b55a34325e32ece … (full pins in caveats) · 23 package sources
Models, repositories, links
11 links- URDFgithub.com/FFTAI/Wiki-GRx-Models/blob/FourierN1/N1/urdf/N1_raw.urdfmodel
- MJCFgithub.com/google-deepmind/mujoco_menagerie/tree/main/fourier_n1model
- Menageriemujoco_menagerie/fourier_n1model
- Repogithub.com/FFTAI/fourier-grx-N1github.com
- Repogithub.com/FFTAI/Wiki-GRx-Modelsgithub.com
- Repogithub.com/FFTAI/Wiki-GRx-Deploygithub.com
- Repogithub.com/FFTAI/Wiki-GRx-Gymgithub.com
- Repogithub.com/FFTAI/Wiki-GRx-Mujocogithub.com
- Repogithub.com/FFTAI/fourier_actuator_sdkgithub.com
- Sitefftai.comfftai.com
- Docsgithub.com/FFTAI/fourier-grx-N1github.com
Videos
1 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning Fourier N1
Papers using Fourier N1
20251
- Open source
Fourier open-sources the N1 humanoid
Fourier released hardware designs, assembly guides and base control software for its N1 humanoid.
FourierFourier N1aibase.comhumanoidsdaily.com
Sources
last checked 2026-09-25- [1]TMTPost: Fourier N1en.tmtpost.com/post/7534782checked 2026-09-24
- [2]Humanoids Daily N1humanoidsdaily.com/news/fourier-intelligence-launches-n1-humanoid-robot-with-open-source-strategychecked 2026-09-24
- [3]fourier-grx-N1 repogithub.com/FFTAI/fourier-grx-N1checked 2026-09-24
- [4]N1 URDF (effort limits 95/54/30 N·m)github.com/FFTAI/Wiki-GRx-Models/blob/FourierN1/N1/urdf/N1_raw.urdfchecked 2026-09-25
- [5]Wiki-GRx-Deploy FourierN1 branch (walking policies)github.com/FFTAI/Wiki-GRx-Deploy/tree/FourierN1checked 2026-09-25
- [6]fourier_actuator_sdkgithub.com/FFTAI/fourier_actuator_sdkchecked 2026-09-25
- [7]Fourier N1 open-source launch pagefftai.cn/open-source/18checked 2026-09-25
- [8]N1 hardware pack on Baidu Netdisk (download needs a Baidu login)pan.baidu.com/s/1tMbhTLfY-tFFIe2poseqLA?pwd=cedkchecked 2026-09-25
Suggest a correction
Related
Nearest by size (height, mass)
Also by Fourier (Fourier Intelligence)
Cite this page
humanoidrobots.systems. “Fourier N1 specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/fourier/n1
Machine-readable: /data.json (record fourier/n1).