sourcerobotics/parol6 · spec sheet
Source PAROL6 specs
3D-printed 6-axis desktop robot arm with industrial-style mechanics, with open-source STL files, BOM, control software and GUI.
Media
4 items · credited and licensed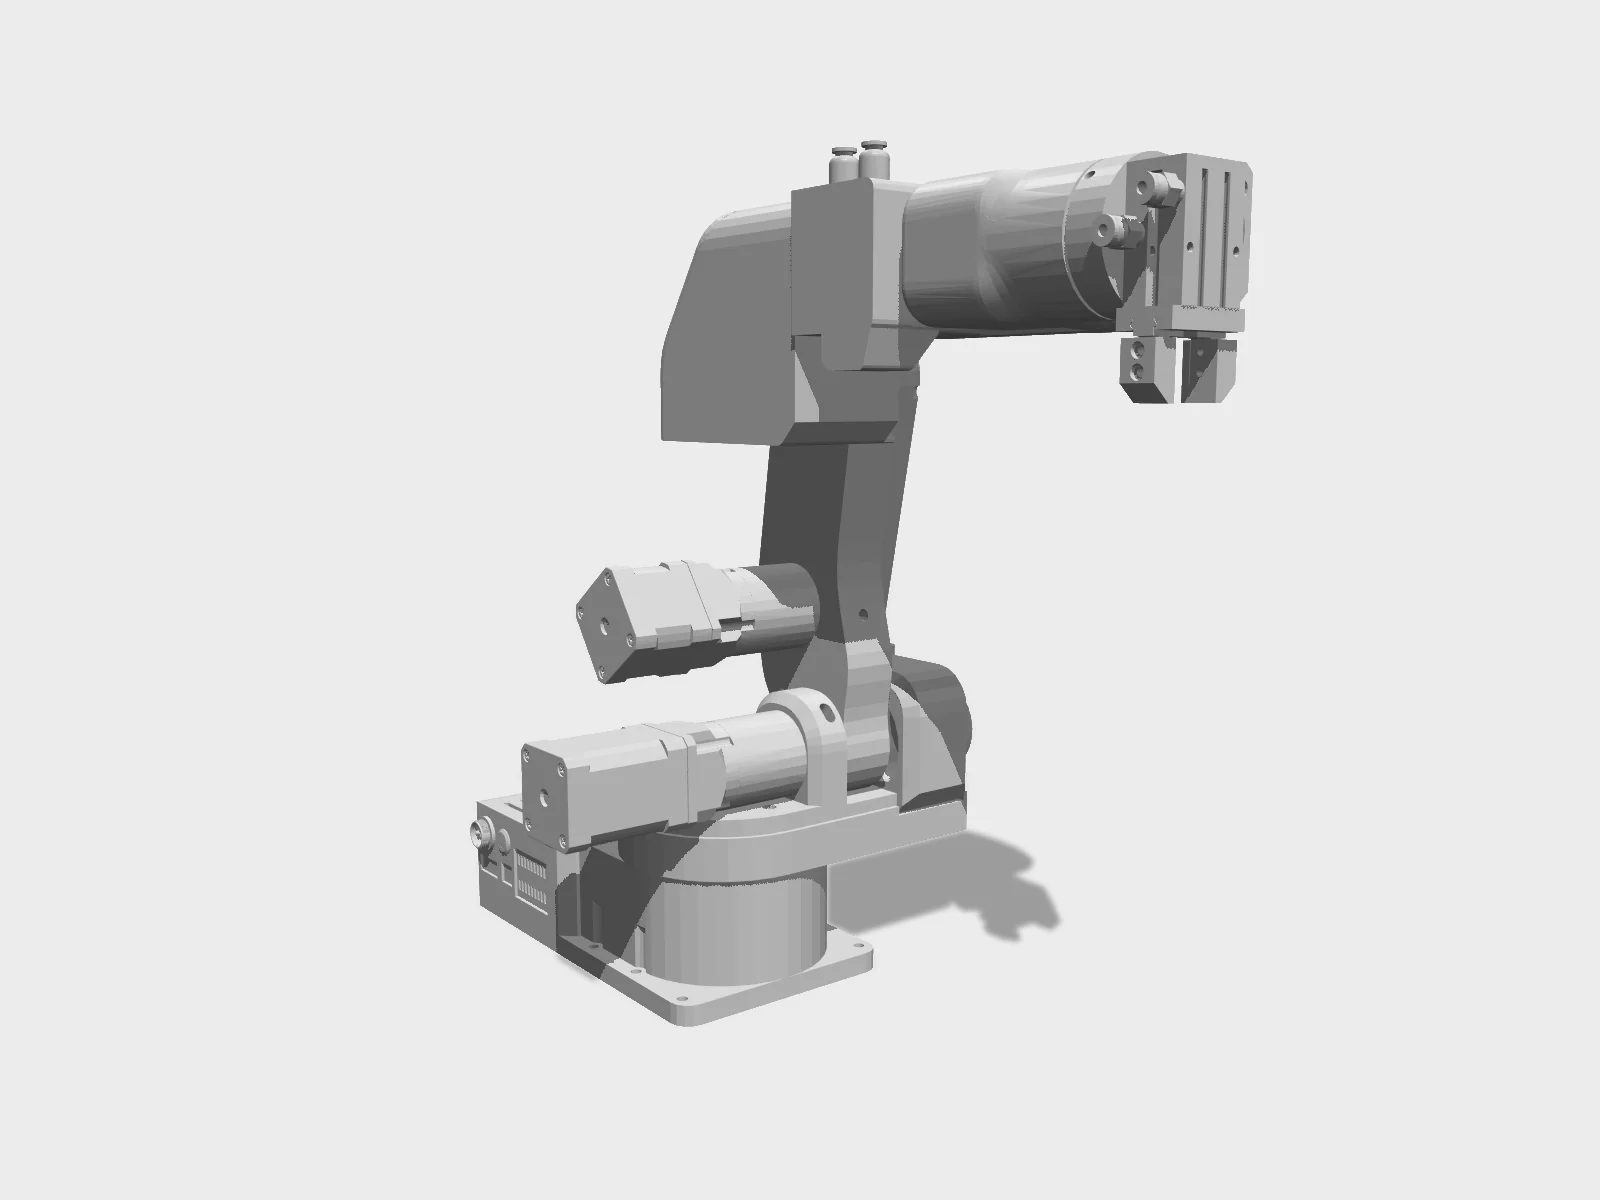 render
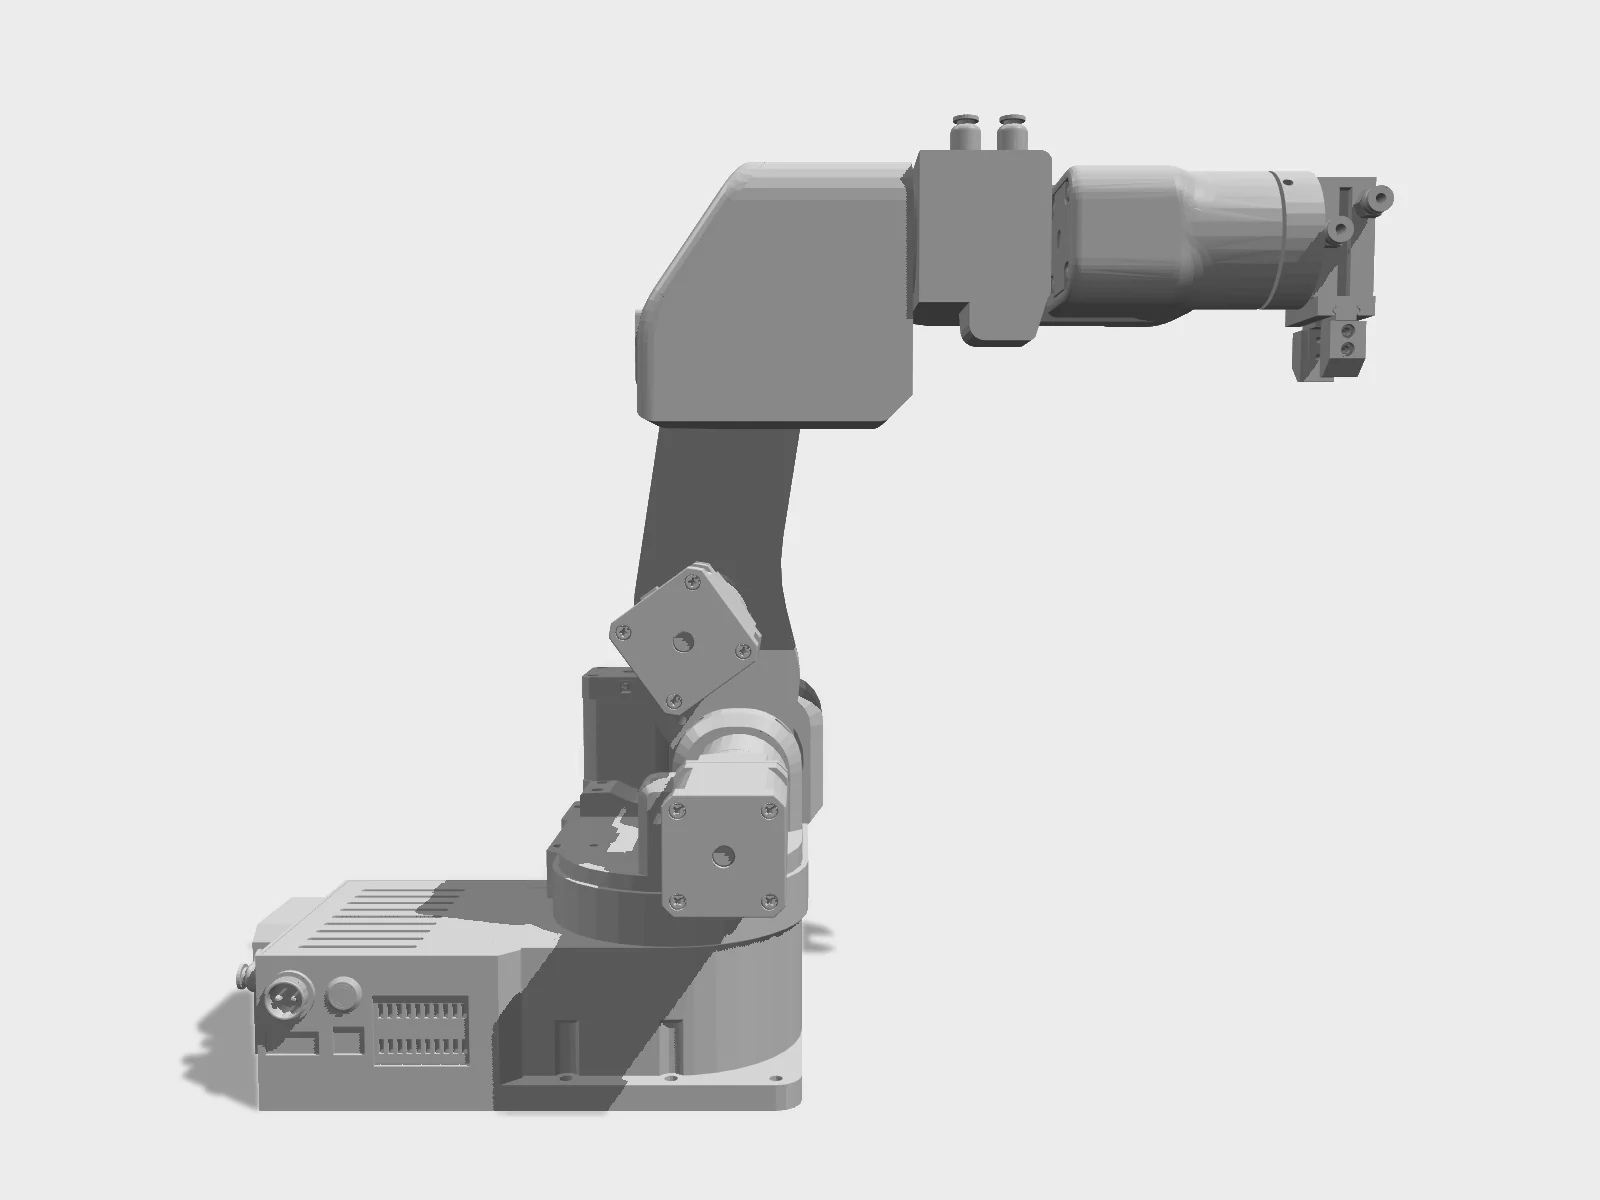 render
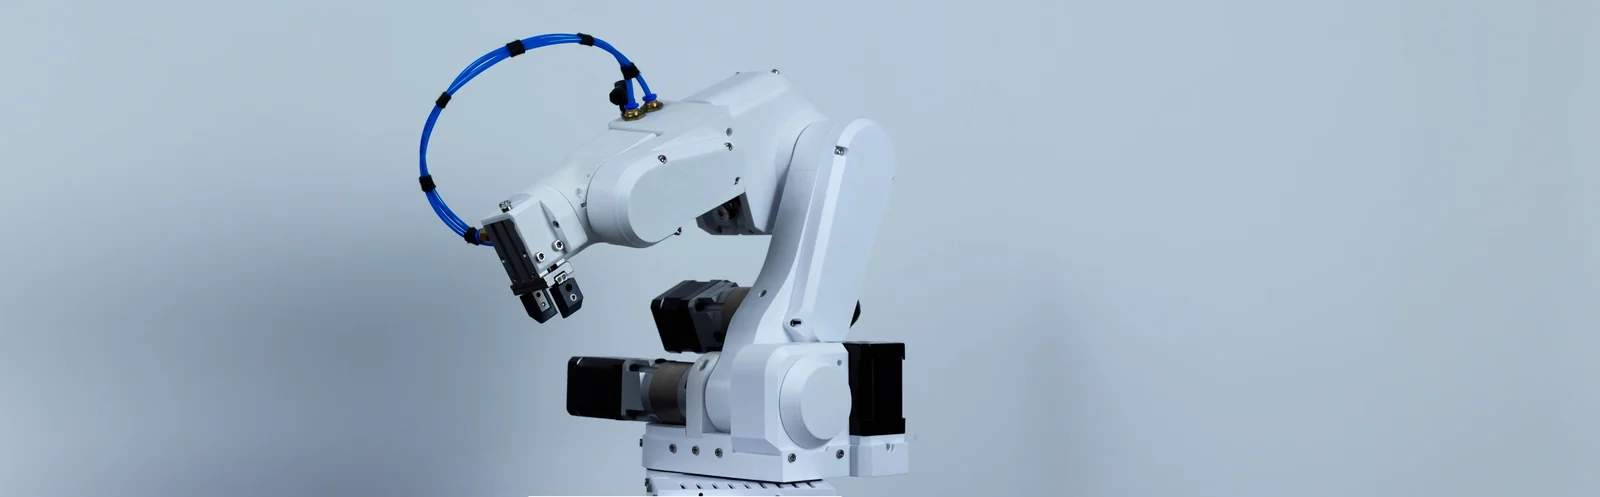

Specifications
2/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | 5.5kg |
| Degrees of freedomspecs.dof | 6 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourcedSold as full kit (no printed parts/PSU), partial kit, or assembled; reach 400 mm |
| Actuatorsspecs.actuators | unsourced |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | unsourced |
| Licenselicense.hw / .sw / .docs | Hardware: GPL-3.0Software: GPL-3.0 |
Note · Repo moved from PCrnjak (Petar Crnjak) to the Source-Robotics org. Maker reports >250 units in use worldwide. URDF (ROS package with Gazebo launch) is in PAROL6_URDF/. STL files, BOM, firmware and PAROL Commander are GPL-3.0; per the assembly manual the STEP files and the PAROL6 control board are not open source, and the board is only sold by Source Robotics. No trained policies or datasets found on Hugging Face (2026-09-25).
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | no | 10 | 0 |
| score = Σ weight × public | 90 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Fasteners | 18 | 263 | — |
| Structure | 12 | 60 | — |
| Other | 11 | 20 | — |
| Electronics | 6 | 11 | — |
| Cabling | 6 | 6 | — |
| Actuators | 5 | 9 | — |
| Sensors | 4 | 6 | — |
| Power | 1 | 1 | — |
Offers in CN · EU · GLOBAL from 4 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 3 | — | — |
| Arm assembly | 9 | — | — |
| Electronics | 5 | — | 4 |
| Firmware | 2 | — | — |
| First motion | 3 | — | 3 |
| Calibration | 1 | — | — |
| Gripper | 2 | — | — |
Fabrication: FDM print ×41
Firmware
- Targets
- STM32F446RE (PAROL6 control board, PlatformIO env genericSTM32F446RE, ST-Link upload), 6x TMC5160 over SPI (configured by the main firmware)
- Repo
- github.com/Source-Robotics/PAROL6-Desktop-robot-arm/tree/main/PAROL6%20control%20board%20main%20software
- Calibrate
- Homing on every power-up: Commander Home button (J1-J3 to limit switches/sensor, then J4, J6, J5). Mastering: align the witness marks and edit `homed_position` per joint in motor_init.cpp, then re-upload. Direction: `Joint__->direction_reversed` in motor_init.cpp. Currents: `MOTORx_MAX_CURRENT` in constants.h (defaults 2000/2000/1900/1700/1700/965 mA for J1-J6) and `hold_multiplier`.
- Notes
- Two PlatformIO projects in the robot repo: 'PAROL6 control board test code' (component tests, serial commands `# LIMIT` and `# IO`; spins all motors, not for an assembled arm) and 'PAROL6 control board main software' (talks to Commander over USB CDC). Boards ship with the test code. 32x microstepping on all joints; reductions J1 6.4:1 belt, J2 20:1 planetary, J3 20:1 x 38:42 belt (18.095:1), J4 4:1 belt, J5 4:1 belt, J6 10:1 planetary. Host software: PAROL-commander-software (GPL-3.0), plus the community PAROL-Web-Commander and the PAROL6 Python API.
Caveats · stated by the package
- Upstream pins: Source-Robotics/PAROL6-Desktop-robot-arm@3892e9c85c1f6d8041cda01c47c9db9d18b30ad8 (2026-09-07; BOM/BOM.md, STL/, Print table/PR_EXCEL.xlsx, assembly manual v1.2 rev1 dated 27.10.2023, control board main + test firmware); Source-Robotics/PAROL-docs@6a30a7fadc73e6e270e8e86f3afb96d55346af69 (2026-03-13, published at source-robotics.github.io/PAROL-docs as of 2026-09-25); PAROL-commander-software@65c844fd5e0e5ec20c30352092ac4fb29b997bd5 (2025-09-23)
- No USD prices anywhere upstream. BOM.md gives links only (many are AliExpress affiliate short links), and the control board and programming adapter are priced in EUR on source-robotics.com.
- The PAROL6 control board is only sold by Source Robotics. The manual states the STEP files and the control board are not open source; STL files, BOM, firmware and Commander are GPL-3.0.
- The BOM supply (Mean Well EDR-120-24) is an open-terminal mains DIN-rail unit. It needs an enclosure, earth and qualified wiring. The kit is sold without printed parts or a PSU.
- The print table (PR_EXCEL.xlsx) predates some STL renames: several files (J1_turret_rework_blocker, J1_belt_cover_rework, main_base_blocker, lid_electronics) are matched to older row names, some parts have two conflicting rows, and E-stop, gripper jaws and J1_wires_cover have no row at all.
- The assembly manual is v1.2 rev1 (27.10.2023) and some images are outdated (the J5 stepper orientation is shown 180° wrong; J1 turret stopper rails were added later).
- TMC5160 modules from other sellers must match the docs pinout and have the DIAG pins removed. A reversed or wrong driver, or an ST-Link connected without the adapter, destroys the board.
- No brakes: the arm falls when power is cut. For long runs the docs require lowering motor currents in constants.h to keep PETG parts cool (J4-J6 reach 72-73 °C when moving).
- The manual calls for an M3x20 screw as the J1 rotation limiter and 'M3 ?' in one optional shoulder step, but BOM.md has no M3x20 line. Buy a few extra M3 lengths.
- Open-loop steppers with homing switches. Position is lost on a stall until the next homing.
- No trained policies or datasets were found on Hugging Face for PAROL6 (search 2026-09-25).
Package sourcerobotics/parol6@0.1.0 · upstream Source-Robotics/PAROL6-Desktop-robot-arm@3892e9c85c1f6d8041cda01c47c9db9d18b30ad8 (2026-09-07; BOM/BOM.md, STL/, Print table/PR_EXCEL.xlsx, assembly manual v1.2 rev1 dated 27.10.2023, control board main + test firmware); Source-Robotics/PAROL-docs@6a30a7fadc73e6e270e8e86f3afb96d55346af69 (2026-03-13, published at source-robotics.github.io/PAROL-docs as of … (full pins in caveats) · 18 package sources
Models, repositories, links
6 links- URDFgithub.com/Source-Robotics/PAROL6-Desktop-robot-arm/blob/main/PAROL6_URDF/PAROL6/urdf/PAROL6.urdfmodel
- Repogithub.com/Source-Robotics/PAROL6-Desktop-robot-armgithub.com
- Repogithub.com/Source-Robotics/PAROL-commander-softwaregithub.com
- Sitesource-robotics.com/source-robotics.com
- Docssource-robotics.github.io/PAROL-docs/source-robotics.github.io
- Buysource-robotics.com/products/parol6-robotic-arm-kitsource-robotics.com
Videos
2 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning PAROL6
Papers using PAROL6
Sources
last checked 2026-09-25- [1]PAROL docssource-robotics.github.io/PAROL-docs/checked 2026-09-25
- [2]PAROL6 assembly manual v1.2 (STEP files and control board not open source)github.com/Source-Robotics/PAROL6-Desktop-robot-arm/blob/main/Building%20instructions/Parol%20building%20instructions.pdfchecked 2026-09-25
- [3]PAROL Commander software (GPL-3.0)github.com/Source-Robotics/PAROL-commander-softwarechecked 2026-09-25
- [4]Source Robotics contact info (Zagreb address)source-robotics.com/policies/contact-informationchecked 2026-09-24
- [5]GitHub repo (GPL-3.0)github.com/Source-Robotics/PAROL6-Desktop-robot-armchecked 2026-09-24
- [6]Source Robotics sitesource-robotics.com/checked 2026-09-24
- [7]Hackaday.io projecthackaday.io/project/191860-parol6-desktop-robotic-armchecked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
Cite this page
humanoidrobots.systems. “Source PAROL6 specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/sourcerobotics/parol6
Machine-readable: /data.json (record sourcerobotics/parol6).