pollen/amazing-hand · spec sheet
Pollen AmazingHand specs
Fully 3D-printable 8-DOF four-finger humanoid hand with all actuators inside the hand, designed for Pollen's Reachy2 wrist but adaptable.
Media
5 items · credited and licensed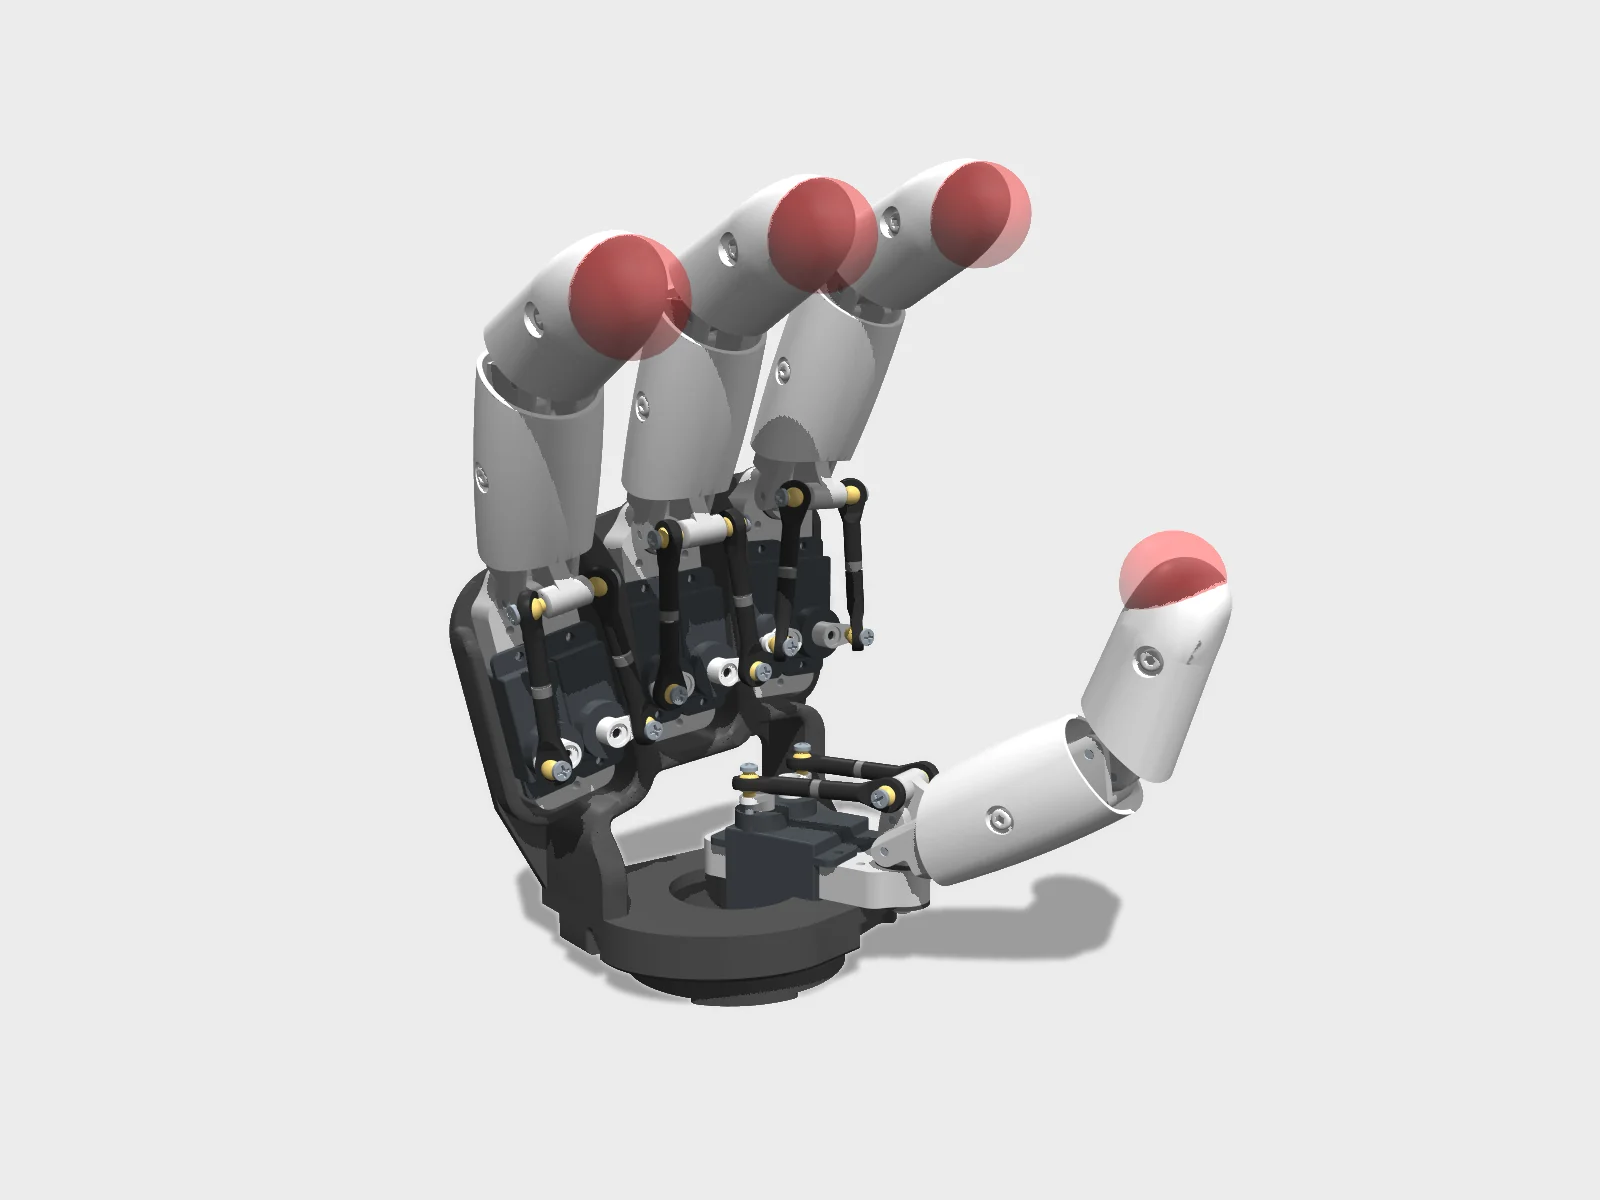 render
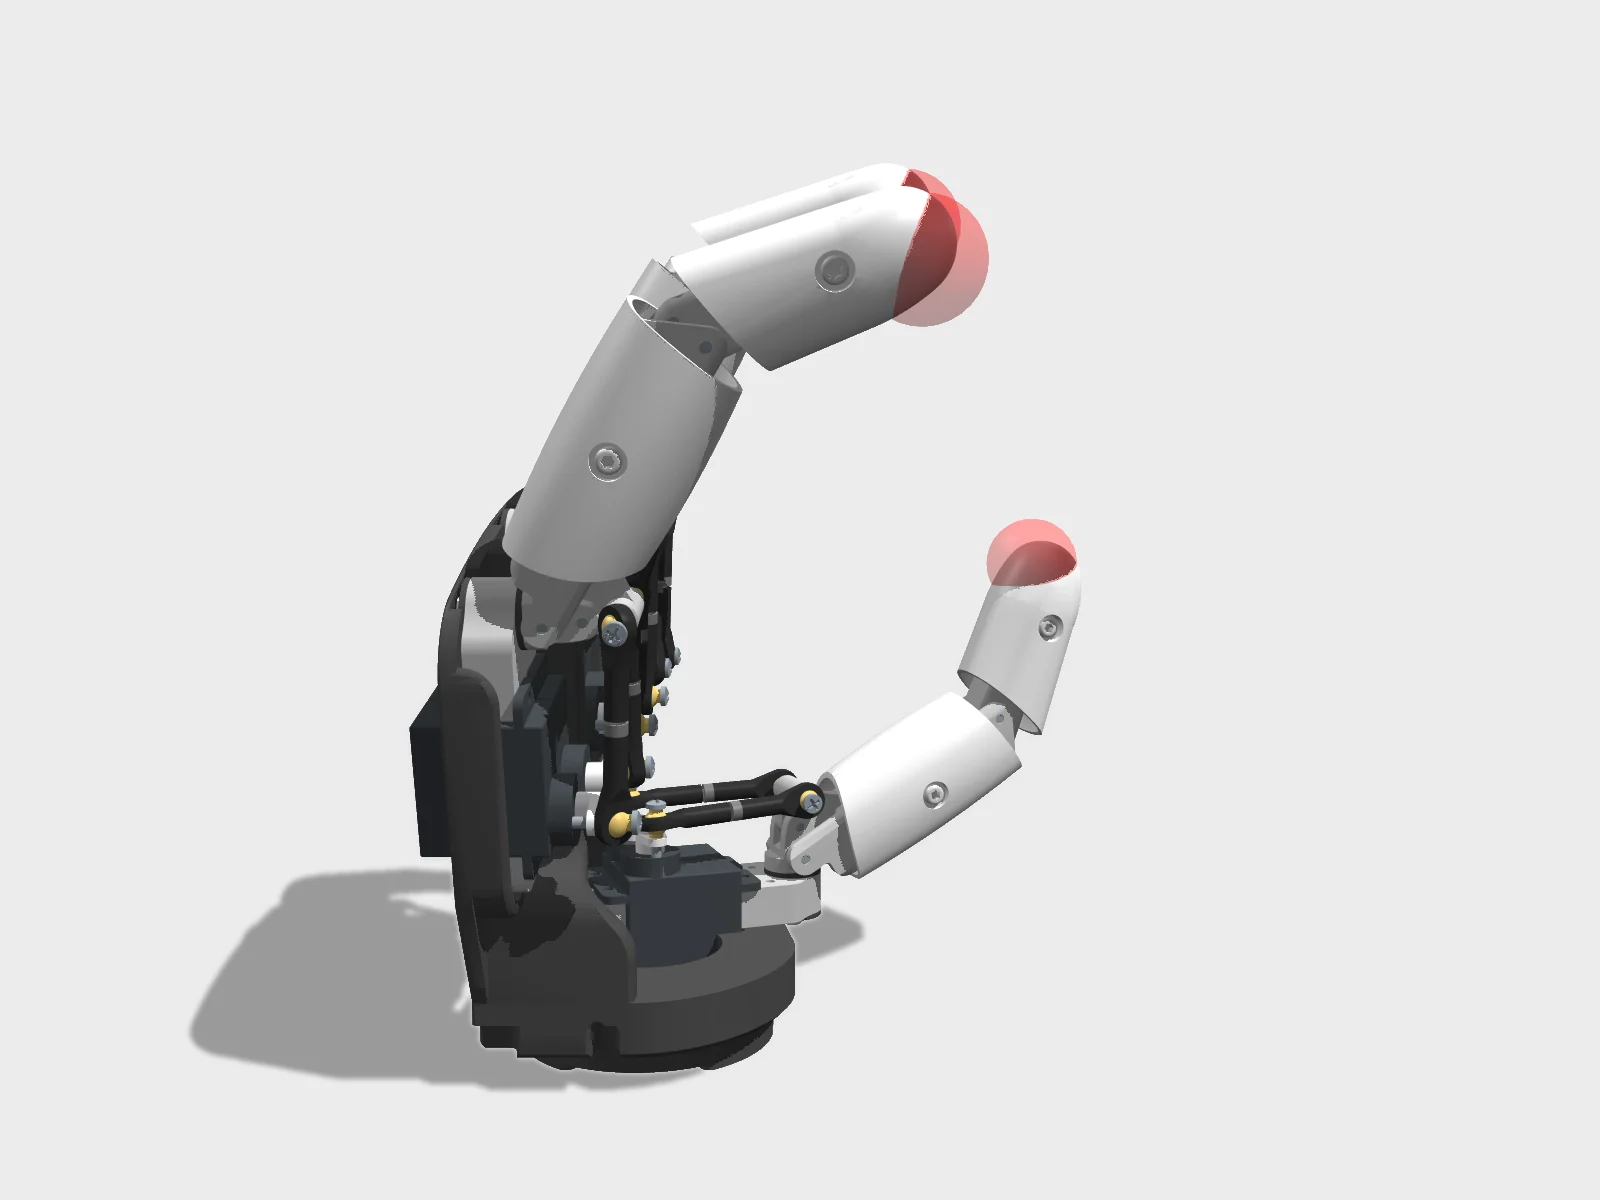 render
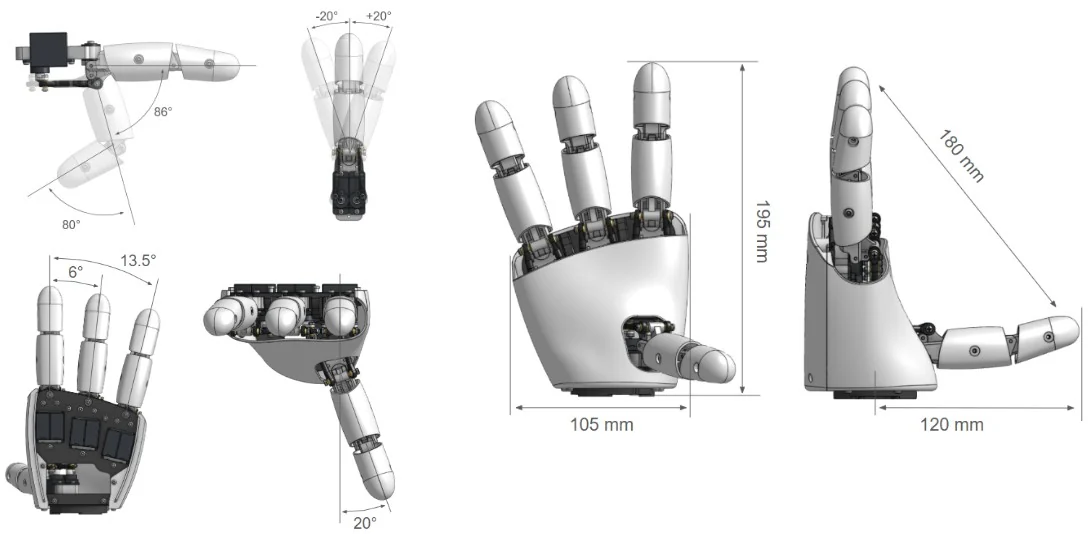

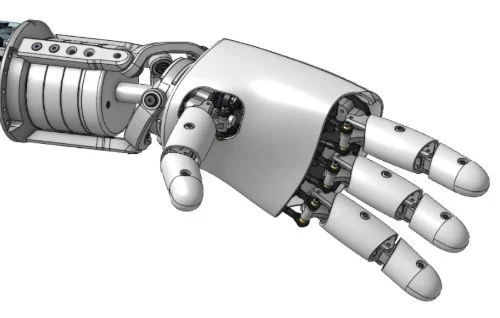

Specifications
4/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | 0.4kg |
| Degrees of freedomspecs.dof | 8 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourcedUpstream BOM: €116.89 per hand, €128.28 with the Waveshare board (EUR only; printing extra) |
| Actuatorsspecs.actuators | 8x Feetech SCS0009 servos (2 per finger) |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | 2025 |
| Licenselicense.hw / .sw / .docs | Hardware: CC-BY-4.0Software: Apache-2.0 |
Note · An 'Amazing Hand Enhanced' branch exists. Third-party kits from WowRobo/Seeed. Onshape CAD public. Left and right MJCF models ship in Demo/AHSimulation.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | no | 10 | 0 |
| score = Σ weight × public | 90 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Structure | 5 | 41 | — |
| Fasteners | 3 | 50 | — |
| Electronics | 3 | 3 | — |
| Actuators | 1 | 8 | — |
| Printed | 1 | 1 | — |
| Power | 1 | 1 | — |
| Other | 1 | 1 | — |
Offers in CN · EU from 5 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 2 | — | — |
| Preparation | 2 | — | — |
| Finger (x4) | 8 | — | — |
| Electronics | 1 | — | 1 |
| Calibration | 2 | — | 2 |
| Hand | 4 | — | — |
| First motion | 1 | — | 1 |
| Software | 1 | — | — |
Fabrication: FDM print ×16
Firmware
- Targets
- Feetech SCS0009 bus (IDs 1-8, 1 Mbaud), Waveshare serial bus servo driver + host Python (rustypot), Arduino Mega 2560 + Feetech TTLinker (SCServo library)
- Repo
- github.com/pollen-robotics/AmazingHand
- Calibrate
- Set IDs in Feetech FD (1000000 baud): index 1/2, middle 3/4, ring 5/6, thumb 7/8. Run PythonExample/AmazingHand_Hand_FingerMiddlePos.py, fit horns, then AmazingHand_FingerTest.py and adjust MiddlePos per servo until the horns align with the servo mid-plane in the closed pose (Arduino: raw values around 511, 0.293° per step). Rust tools in Demo/AHControl: `cargo run --bin=get_zeros`, `set_zeros`, `change_id`, `goto`.
- Notes
- No firmware to flash on the servos; the host drives them over the half-duplex TTL bus. Python uses rustypot's Scs0009PyController; Arduino needs the SCServo library (Serial1 on a Mega, pins 19/18). For left and right hands on one bus, use the alternate IDs in assets/Both_Hands-IDs.jpg and PythonExample/AmazingHand_Demo_Both.py.
Caveats · stated by the package
- All upstream prices are in EUR (BOM total €116.89 per hand, €128.28 with the Waveshare board, €142.29 with Arduino + TTLinker; the sheet's own USD conversion uses 1.16). They are kept as notes; no USD prices are set.
- Most vendor links are French Amazon/AliExpress listings (tracking parameters stripped). Alibaba links are the Feetech supplier pages. A Chinese-market BOM is maintained separately by Jianliang Shen (linked in the README).
- Rod lengths are inconsistent inside the assembly guide: page 6 says cut 4 rods at 26-28 mm and 8 rods at 14-16 mm, page 9 lists 2x 18 mm and 1x 25 mm per finger. Cut long, then trim against the length tooling.
- The length tooling needs 2 extra D2x16 axes that stay pressed in; the BOM lists 8 D2x16, exactly the 4 fingers' need. Order 10.
- The BOM sheet's screw rows carry swapped link annotations ('M2.5 x 8' on the 2.5x6 row and vice versa); both point to the same listing.
- Material for the top shell differs: the parts sheet says flexible filament, the printing guide also shows a rigid PLA hand shell (20-40% infill).
- The wrist interface is designed for Pollen's Reachy2 (Orbita 3D wrist). An SO-ARM interface and a desk base are community additions in cad/.
- Upstream disclaimer: real finger angles vary from the CAD, and the hand is not yet validated for long grasping tasks; stalled SCS0009 servos can overheat.
- An 'Amazing Hand Enhanced' revision lives on a separate branch (Amazing-Hand-Enhanced); this package follows main.
- Print hours and filament grams are not published. Assembly time per the Overview is 5-6 hours.
- Ready-made kits exist: Seeed Studio (https://www.seeedstudio.com/Amazing-Hand-Right-Hand-The-Open-Source-Robotic-Hand-Developer-Kit.html) and WowRobo (https://shop.wowrobo.com/products/amazing-hand-the-open-source-robotic-hand-kit).
Package pollen/amazing-hand@0.1.0 · upstream pollen-robotics/AmazingHand@3e8241074df3436a3044ced4881e3bb2133aa725 (main, 2026-04-03); BOM Google Sheet (tabs 'BOM' gid 1269903342 and '3D printed parts' gid 2050623549) as exported 2026-09-25; docs/AmazingHand_Assembly.pdf, AmazingHand_3DprintingTips.pdf, AmazingHand_Overview.pdf at that commit · 12 package sources
Models, repositories, links
5 links- MJCFgithub.com/pollen-robotics/AmazingHand/blob/main/Demo/AHSimulation/AHSimulation/AH_Right/mjcf/robot.xmlmodel
- Repogithub.com/pollen-robotics/AmazingHandgithub.com
- Sitehuggingface.co/blog/pollen-robotics/amazing-handhuggingface.co
- Docsgithub.com/pollen-robotics/AmazingHandgithub.com
- Buyshop.wowrobo.com/products/amazing-hand-the-open-source-robotic-hand-kitshop.wowrobo.com
Videos
2 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning AmazingHand
Papers using AmazingHand
Sources
last checked 2026-09-25- [1]AmazingHand repo (licenses, specs)github.com/pollen-robotics/AmazingHandchecked 2026-09-24
- [2]Hugging Face blog announcementhuggingface.co/blog/pollen-robotics/amazing-handchecked 2026-09-24
- [3]AmazingHand BOM sheet (EUR totals)docs.google.com/spreadsheets/d/1QH2ePseqXjAhkWdS9oBYAcHPrxaxkSRCgM_kOK0m52E/edit?gid=1269903342#gid=1269903342checked 2026-09-25
Suggest a correction
Related
Nearest by size (height, mass)
- Stanford ToddlerBot
- Poppy Humanoid
- ROBOTIS OP3
- Noetix Bumi
- UC Berkeley Humanoid
- UC Berkeley Humanoid Lite
Also by Pollen Robotics
Cite this page
humanoidrobots.systems. “Pollen AmazingHand specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/pollen/amazing-hand
Machine-readable: /data.json (record pollen/amazing-hand).