odri/solo-12 · spec sheet
Open Solo-12 specs
Lightweight, torque-controlled 12-DOF research quadruped built from open-source brushless actuator modules by the Open Dynamic Robot Initiative.
Media
3 items · credited and licensed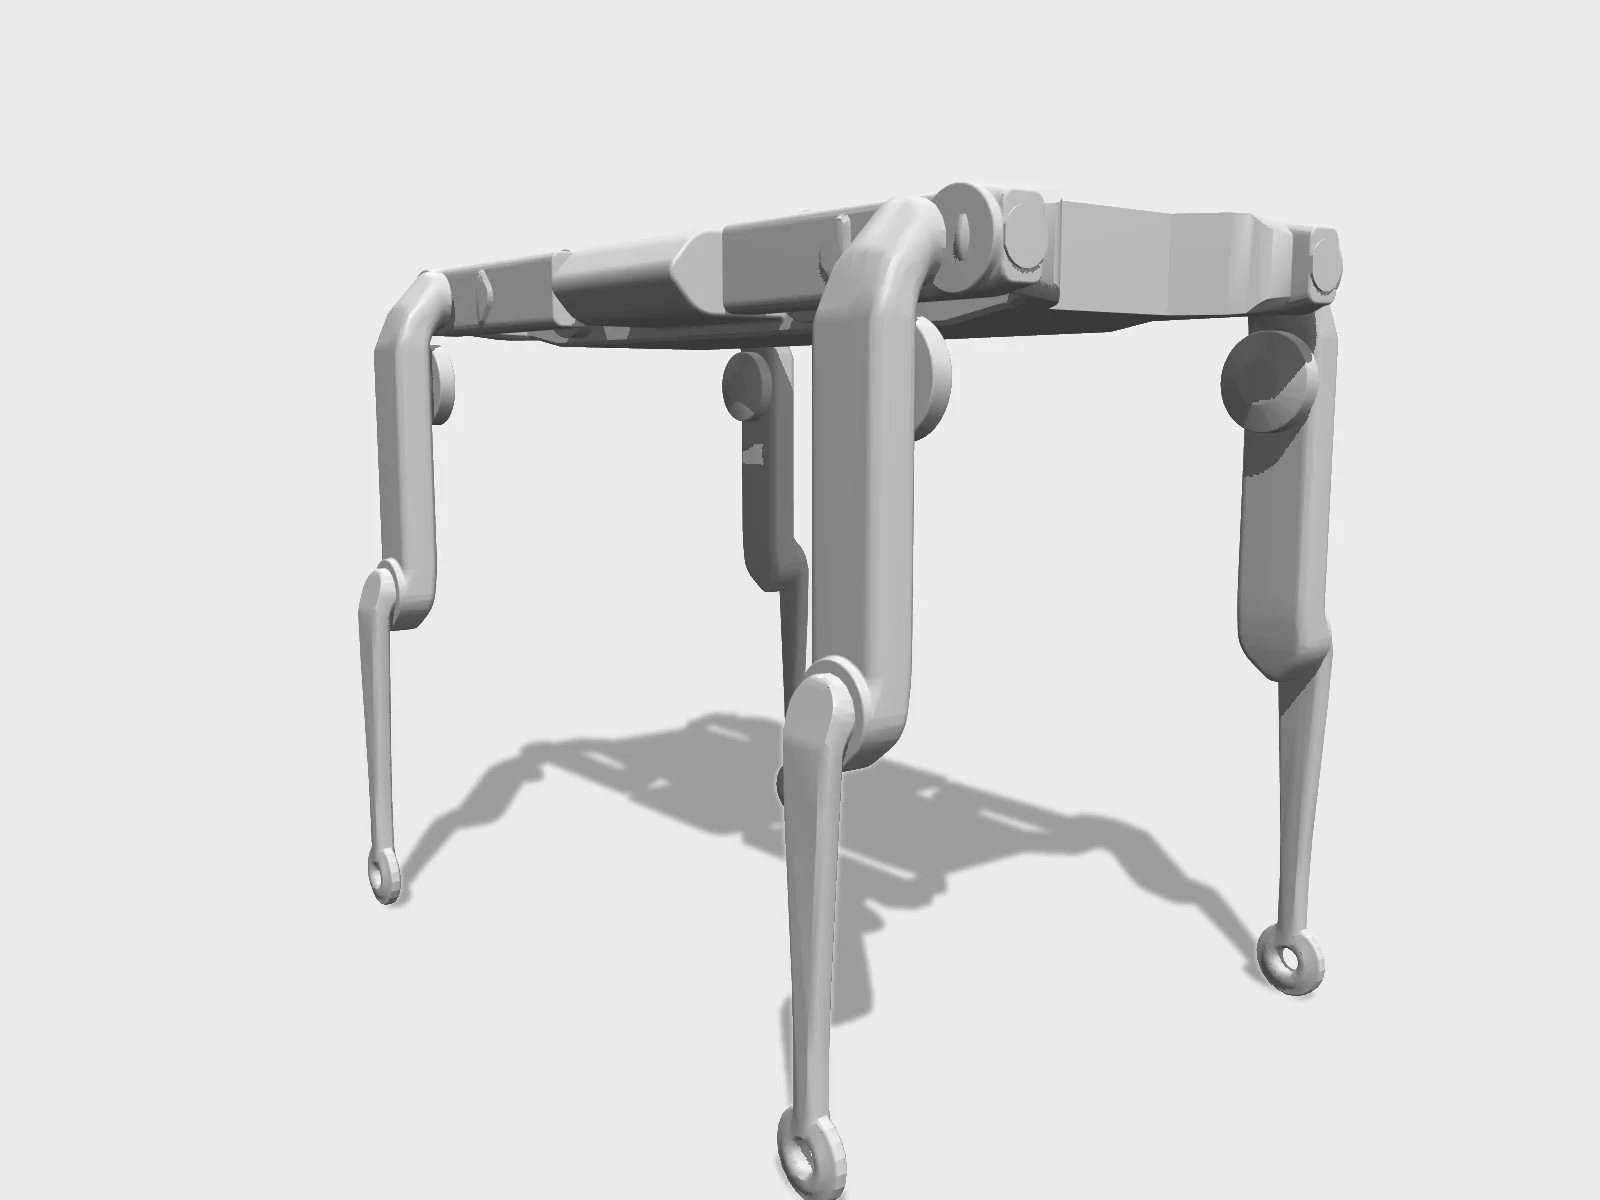 render
 render
Specifications
4/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | 2.5kg |
| Degrees of freedomspecs.dof | 12 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourced |
| Actuatorsspecs.actuators | ODRI open-source brushless torque-controlled actuator modules |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | 2021 |
| Licenselicense.hw / .sw / .docs | Hardware: BSD-3-ClauseSoftware: BSD-3-Clause |
Note · Multi-institution academic initiative, so no single HQ given. Actuator/solo repos mostly unchanged since 2022-2023; master-board updated 2026. Mass 2.5 kg per the 12-DOF quadruped hardware README (v1, tethered); the v1.1 autonomy upgrade weighs 2.8 kg; 2.2 kg, quoted by some sources, is the Solo-8 figure. License mismatch upstream: the master-board README says BSD 2-Clause while its ordering page says BSD 3-Clause; actuator hardware and software are BSD-3-Clause.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | no | 10 | 0 |
| score = Σ weight × public | 90 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Fasteners | 18 | 499 | — |
| Electronics | 9 | 72 | — |
| Cabling | 8 | 189 | — |
| Structure | 7 | 113 | — |
| Other | 3 | 30 | — |
| Sensors | 2 | 13 | — |
| Actuators | 1 | 12 | — |
| Power | 1 | 1 | — |
Offers in CN · EU · GLOBAL · US from 25 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Electronics prep | 4 | — | 2 |
| Fabrication | 2 | — | — |
| Actuators | 6 | — | 1 |
| Legs | 1 | — | — |
| Body | 3 | — | — |
| Software | 2 | — | — |
| Bring-up | 3 | — | 3 |
Fabrication: FDM print ×20 · SLS print ×6 · SLA print ×3 · CNC ×3
Firmware
- Targets
- 6 x MicroDriver v2 (TI F28069M + DRV8305): udriver_firmware SPI build via Code Composer Studio + XDS100V2 JTAG, Master Board v2 (ESP32): master-board/firmware via esp-idf (v4.0.1 install, rolled back to 8d1a9c0) and `make flash` over the PROG serial port
- Repo
- github.com/open-dynamic-robot-initiative/udriver_firmware
- Calibrate
- Joint offsets: `sudo -E python3 robot_calibrator.py -c config_solo12.yaml` (odri_control_interface/demos) with the printed calibration tools; paste the output into position_offsets. At every start the joint calibrator searches the nearest encoder index (search_methods per joint) and applies the offsets. Motor-encoder electrical alignment runs automatically in the driver firmware on first enable.
- Notes
- Host side: master_board_sdk (raw Ethernet frames or ESP-NOW Wi-Fi at 1 kHz; needs root or cap_net_admin/cap_net_raw), odri_control_interface (yaml-configured robot, joint calibrator, safety limits), solo (dynamic_graph_manager bindings, installed via treep SOLO). robot_properties_solo holds solo12_driver.yaml with motor numbers, polarities, limits and offsets.
Caveats · stated by the package
- Upstream pins: open-dynamic-robot-initiative/open_robot_actuator_hardware@66af1522b4fba0ec4a1d7790e66f5e4652208d30 (2022-09-06); master-board@574fe988270aa3da948484ad3fa1f15dbf8162bf (2026-06-30); udriver_firmware@c98d2296aaf409cd8ef2ce0df2e0a0a4a73943c0 (2022-09-30); odri_control_interface@dcc07e4efc9113622b32cbf5abb60f14b93de488 (2025-06-05); robot_properties_solo@2201f454f4caffa0cad307fa8cbd1d64dd844008 (2023-03-22); solo@e2a3b8bb749e9a41b32fa1907d46a1aa46e6cc34 (2023-08-17)
- No USD prices anywhere upstream. The only figures are EUR component estimates: about 50 EUR per micro driver and 35 EUR per master board in components. Several key parts (encoder kits, 4 mm belts, stainless bearings) are email-quote items from European suppliers.
- PAL Robotics' Solo12 page now says 'SOLO12 sales have been discontinued', so the upstream 'Commercial Option' (kit or assembled, including programmers and calibration tools) is no longer available.
- Custom PCB fab: the micro drivers are 6-layer boards built to a Beta LAYOUT order number (AU-201909/38760) or from the Gerber/assembly packs; the master board is quote AN5eea24ae72697. Shunt resistors and Hirose connectors are hand-soldered.
- Precision parts: pulleys need SLA/multijet, shells need SLS with a controlled +Z print direction (via 3D Systems engineering support), and without the ODRI Encoder Kit the pulleys need a custom form cutter (modified AT3 profile). Bearing seats and output pulley diameters are hand-fitted with end mills and a lathe.
- Robot-level quantities are computed from upstream per-module (x12) and per-leg (x4) BOMs; fastener counts for the calibration tools and body were added in. The actuator assembly page uses 5 M2.5x6 + 3 M2.5x8 for the shells while the leg BOM lists M2.5x6/M2.5x10 only. DF13 right-angle headers per micro driver are not counted upstream (18 assumes 2 encoders + 1 SPI per board).
- Dead vendor links on the upstream pages as of 2026-09-25: Globe-flight T-Motor set, EZO USA catalogue, Online Bearing Store bearing pages and Beltingonline all return 404; those offers are left out. DigiKey, Conrad and MicroStrain block automated checks (403) and were kept.
- Hoffmann part numbers for the M2.5x3.75 Helicoil conflict (leg page: 082814 M2,5; tools page: 082812 M2,5 for 3.75 mm, 082814 for 5 mm).
- Master board firmware only builds with esp-idf 3.x-era code: the docs install v4.0.1 then roll back to commit 8d1a9c0. `espefuse.py set_flash_voltage 3.3V` is irreversible and only for a fresh board.
- This package is the tethered v1 (24 V lab supply + Ethernet). The v1.1 autonomy upgrade (power board, 2 x 3S 850 mAh LiPo, e-stop, LED ring) is documented as work in progress upstream and is not included.
- Policies: the Sci. Reports Solo12 RL work (Gepetto/soloRL) points to checkpoints at gitlab.laas.fr/paleziart/quadruped-rl, which returned HTTP 500 on 2026-09-25, so no policy file could be verified and none is listed.
- Licences: hardware BSD-3-Clause (open_robot_actuator_hardware); master-board README says BSD 2-Clause while its ordering page says BSD 3-Clause; software BSD-3-Clause.
Package odri/solo-12@0.1.0 · upstream open-dynamic-robot-initiative/open_robot_actuator_hardware@66af1522b4fba0ec4a1d7790e66f5e4652208d30 (2022-09-06); master-board@574fe988270aa3da948484ad3fa1f15dbf8162bf (2026-06-30); udriver_firmware@c98d2296aaf409cd8ef2ce0df2e0a0a4a73943c0 (2022-09-30); odri_control_interface@dcc07e4efc9113622b32cbf5abb60f14b93de488 (2025-06-05) … (full pins in caveats) · 33 package sources
Models, repositories, links
9 links- URDFgithub.com/open-dynamic-robot-initiative/robot_properties_solo/blob/master/src/robot_properties_solo/resources/xacro/solo12.urdf.xacromodel
- Repogithub.com/open-dynamic-robot-initiative/open_robot_actuator_hardwaregithub.com
- Repogithub.com/open-dynamic-robot-initiative/robot_properties_sologithub.com
- Repogithub.com/open-dynamic-robot-initiative/master-boardgithub.com
- Repogithub.com/open-dynamic-robot-initiative/sologithub.com
- Repogithub.com/open-dynamic-robot-initiative/udriver_firmwaregithub.com
- Repogithub.com/open-dynamic-robot-initiative/odri_control_interfacegithub.com
- Siteopen-dynamic-robot-initiative.github.io/open-dynamic-robot-initiative.github.io
- Docsopen-dynamic-robot-initiative.github.io/open-dynamic-robot-initiative.github.io
Videos
3 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning Solo-12
Papers using Solo-12
Sources
last checked 2026-09-25- [1]ODRI hardware: 12-DOF quadruped v1 README (2.5 kg)github.com/open-dynamic-robot-initiative/open_robot_actuator_hardware/blob/master/mechanics/quadruped_robot_12dof_v1/README.mdchecked 2026-09-25
- [2]PAL Robotics Solo page (sales discontinued)solo.pal-robotics.com/solochecked 2026-09-25
- [3]master-board repo (README: BSD 2-Clause)github.com/open-dynamic-robot-initiative/master-boardchecked 2026-09-25
- [4]ODRI siteopen-dynamic-robot-initiative.github.io/checked 2026-09-24
- [5]Sci. Reports: Solo12 deep RLnature.com/articles/s41598-023-38259-7checked 2026-09-24
- [6]Tegakari: SOLO 12 (2021)tegakari.net/en/2021/08/solo12/checked 2026-09-24
- [7]arXiv: An Open Torque-Controlled Modular Robotarxiv.org/pdf/1910.00093checked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
Cite this page
humanoidrobots.systems. “Open Solo-12 specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/odri/solo-12
Machine-readable: /data.json (record odri/solo-12).