chestnut/aero-hand-open · spec sheet
Chestnut Aero Hand Open specs
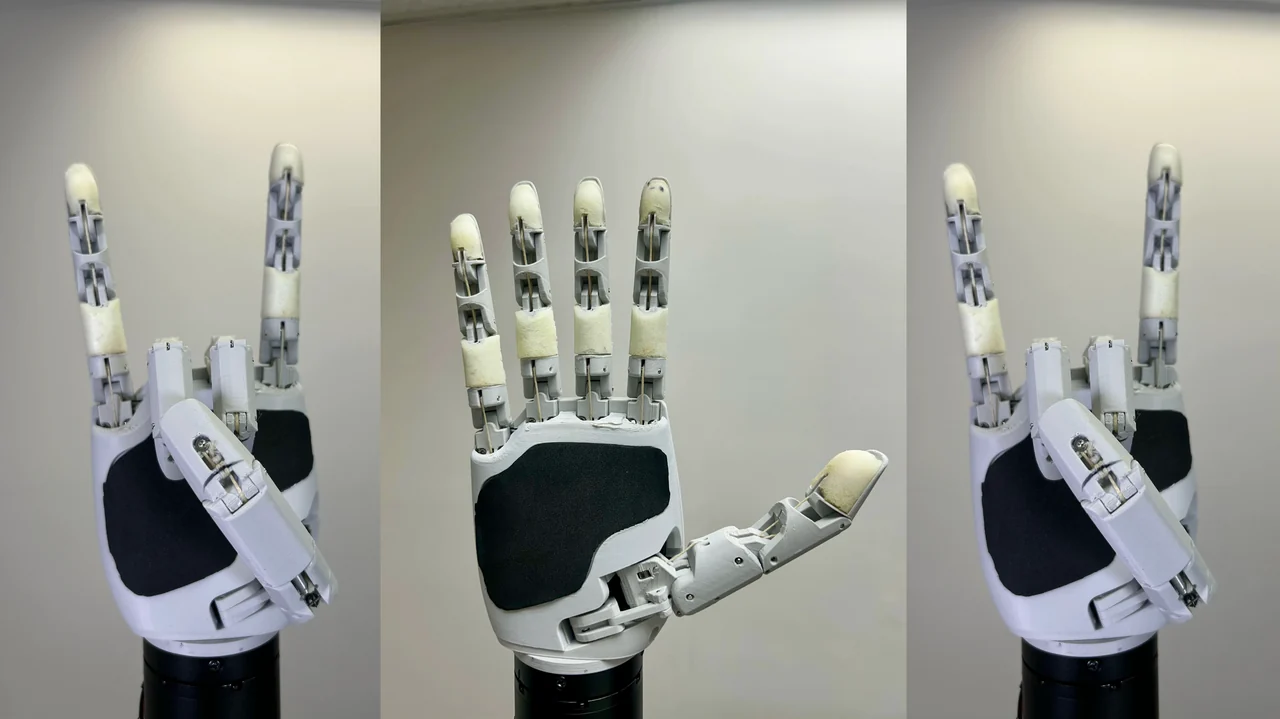
Open-source tendon-driven five-finger hand with 7 actuated DOF (16 joints), fully 3D printed, weighing 389 g, with a Python SDK and ROS2 support.
Media
4 items · credited and licensed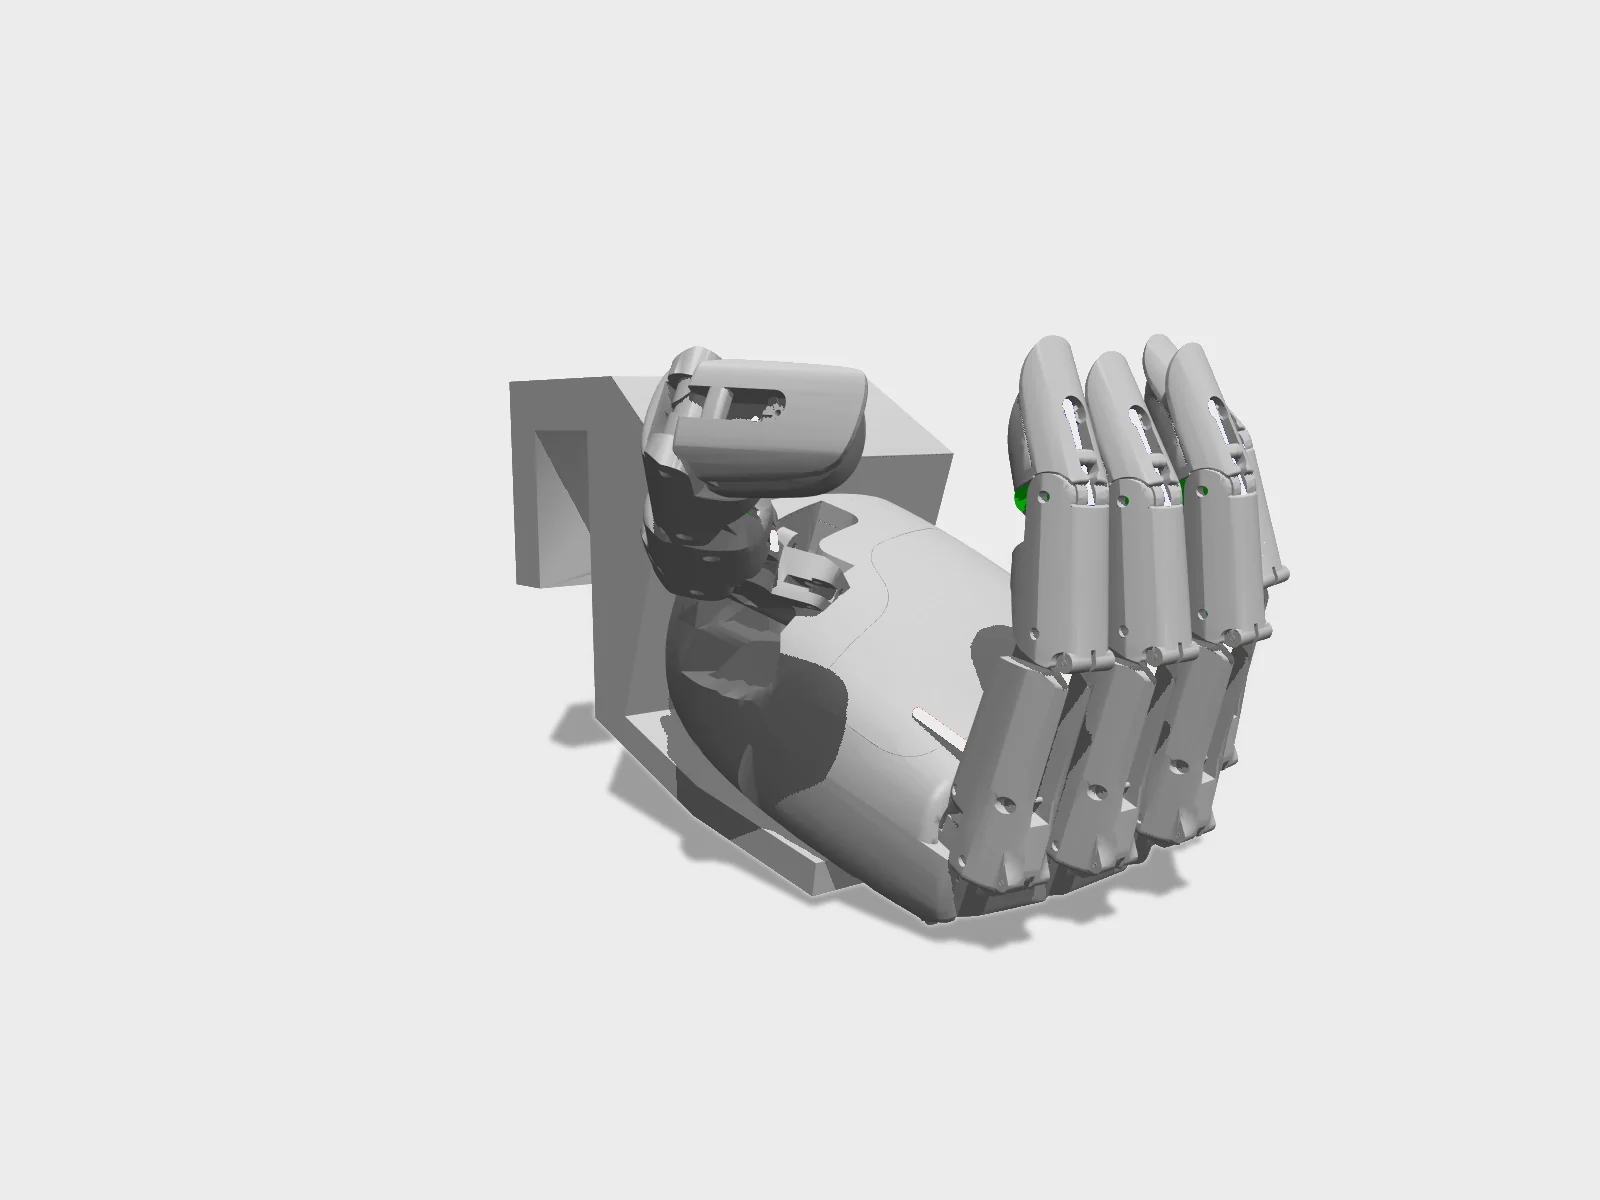 render
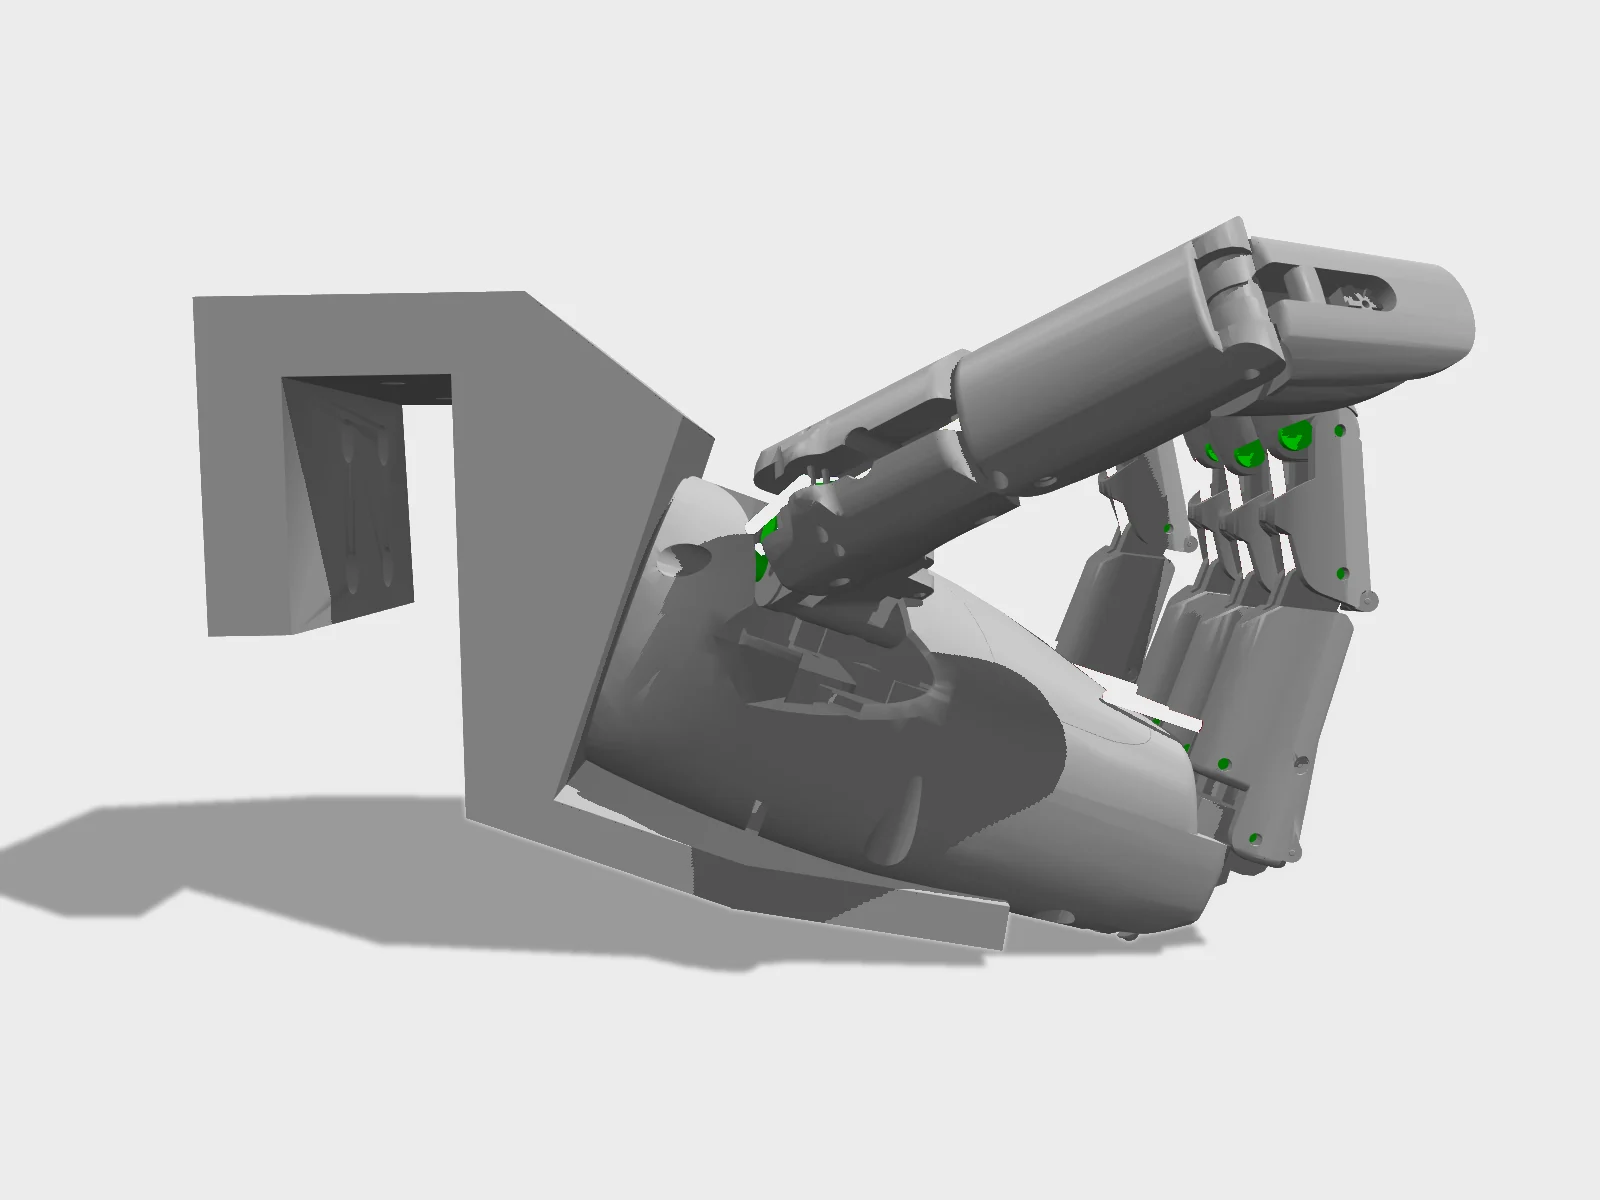 render

Specifications
4/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | 0.39kg |
| Degrees of freedomspecs.dof | 7 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | 314USDComplete kit $314 |
| Actuatorsspecs.actuators | unsourced |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | 2025 |
| Licenselicense.hw / .sw / .docs | Hardware: CC-BY-NC-SA-4.0Software: Apache-2.0 |
Note · TetherIA rebranded to Chestnut Robotics (GitHub org renamed TetherIA -> Chestnut-Robotics). Design files are non-commercial; commercial manufacturing needs a license.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | no | 10 | 0 |
| score = Σ weight × public | 90 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Actuators | 1 | 7 | 209 |
| Structure | 4 | 33 | 56 |
| Fasteners | 10 | 101 | 28 |
| Electronics | 3 | 9 | 17 |
| Compute | 1 | 1 | 8 |
| Cabling | 2 | 2 | 6 |
| Power | 1 | 1 | — |
| Other | 1 | 1 | — |
| Printed | 1 | 1 | — |
Offers in CN · GLOBAL · US from 11 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 4 | — | — |
| Fingers | 2 | — | — |
| Thumb | 2 | — | — |
| Electronics | 2 | — | 2 |
| Firmware | 2 | — | 1 |
| Actuators | 2 | — | — |
| Palm | 6 | — | 1 |
| Bring-up | 1 | — | 1 |
| Finishing | 1 | — | — |
| Policy | 1 | — | — |
Fabrication: FDM print ×17
Firmware
- Targets
- Seeed XIAO ESP32S3 (hand controller, 16-byte binary serial protocol, default 921600 baud), Feetech HLS3606M bus servos, IDs 0-6
- Repo
- github.com/Chestnut-Robotics/aero-hand-open/tree/main/firmware
- Calibrate
- Current-based homing on the ESP32 (GUI Homing button or opcode 0x01), then TRIM (0x03) per channel to set the extend endpoint, stored in NVS. CALIBRATE_MID re-centres a channel whose tendon travel falls outside the default single-turn window.
- Notes
- Prebuilt left/right binaries in firmware/main/bin (v0.1.0 to v0.2.0); flash from `aero-open-gui` or build firmware.ino with LEFT_HAND/RIGHT_HAND set in HandConfig.h. Servo rail is 6 V from its own supply (up to 10 A), separate from USB. Servos over 80 °C may ignore commands until they cool. Torque control closes only (open-to-close direction).
Policies
- in-hand cube rotation about Z (60 mm, 117 g cube) · MuJoCo Playground PPO, deployed via ROS 2 (rl_z_rotation_deploy) · github.comPretrained checkpoint shipped in the repo; validated against firmware v0.1.0 kept in firmware/main/bin/rl_z_rotation.
Caveats · stated by the package
- BOM total is $316.48 per hand in USD as stated in BOM.csv (printed parts and silicone are costed by volume, so real filament and silicone purchases cost more). The README quotes a $314 kit.
- The 6 V servo power supply and XT30 connector appear in the assembly guide but not in BOM.csv; no model or vendor is given. Size it for about 10 A peak per the firmware README.
- Design files (CAD, STL, BOM, docs) are CC BY-NC-SA 4.0, non-commercial; commercial manufacturing needs a licence from Chestnut Robotics. Firmware and SDK are Apache-2.0.
- Several BOM links were long search URLs; tracking parameters are stripped here. MISUMI undersized-pin links point at a series page where you select the size.
- Cable lengths per servo come from a table in the guide that is partly hard to read; only servo 1 (90 mm) and servos 3-5 (140 mm) are stated unambiguously. Check the guide page 10 for servos 2 and 6.
- The BOM row labels and the guide's part numbers differ (e.g. undersized 2x10 is P/N 37 in the BOM and 32 in the guide).
- The RL deployment README calls the GUI `aero-hand-gui`; the SDK installs `aero-open-gui`. The README also says `--select-packages`; colcon's flag is `--packages-select`.
- The BOM lists one undersized 2x20 pin that the guide never calls out by name; this package puts it with the thumb CMC pins. Check the Onshape model.
- The RL policy was validated only with the archived v0.1.0 firmware, not the newer binaries.
- Upstream disclaimer: research prototype, not validated for prolonged or heavy-duty use; tendons need periodic re-tensioning.
Package chestnut/aero-hand-open@0.1.0 · upstream Chestnut-Robotics/aero-hand-open@7bb2f23485a7d440960c21046da642de132b7745 (main, 2026-09-15): hardware/Assembly/BOM.csv, Tools.csv, Gen1_OPEN_Assembly_Guide.pdf, firmware/ (bin up to v0.2.0), sdk/ (aero-open-sdk), ros2/; docs.tetheria.ai as of 2026-09-25 · 12 package sources
Models, repositories, links
7 links- URDFgithub.com/Chestnut-Robotics/aero-open-simmodel
- MJCFgithub.com/google-deepmind/mujoco_menagerie/tree/main/tetheria_aero_hand_openmodel
- Menageriemujoco_menagerie/tetheria_aero_hand_openmodel
- Repogithub.com/Chestnut-Robotics/aero-hand-opengithub.com
- Repogithub.com/Chestnut-Robotics/aero-open-simgithub.com
- Docsdocs.tetheria.ai/docs/intro/docs.tetheria.ai
- Buyshop.tetheria.ai/shop.tetheria.ai
Videos
2 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning Aero Hand Open
Papers using Aero Hand Open
Sources
last checked 2026-09-24- [1]Aero Hand Open repo (specs, license TL;DR)github.com/Chestnut-Robotics/aero-hand-openchecked 2026-09-24
- [2]Rebrand announcementx.com/ChestnutRobotic/status/2032330051707146679checked 2026-09-24
- [3]arXiv paperarxiv.org/abs/2608.28578checked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
Cite this page
humanoidrobots.systems. “Chestnut Aero Hand Open specs.” Hyperspawn, data revision 2026-11-22. https://humanoidrobots.systems/chestnut/aero-hand-open
Machine-readable: /data.json (record chestnut/aero-hand-open).