duke/duke-humanoid · spec sheet
Duke Humanoid v1 specs
Open-source 10-DOF research biped for energy-efficient RL locomotion exploiting passive dynamics.
Media
1 item · credited and licensed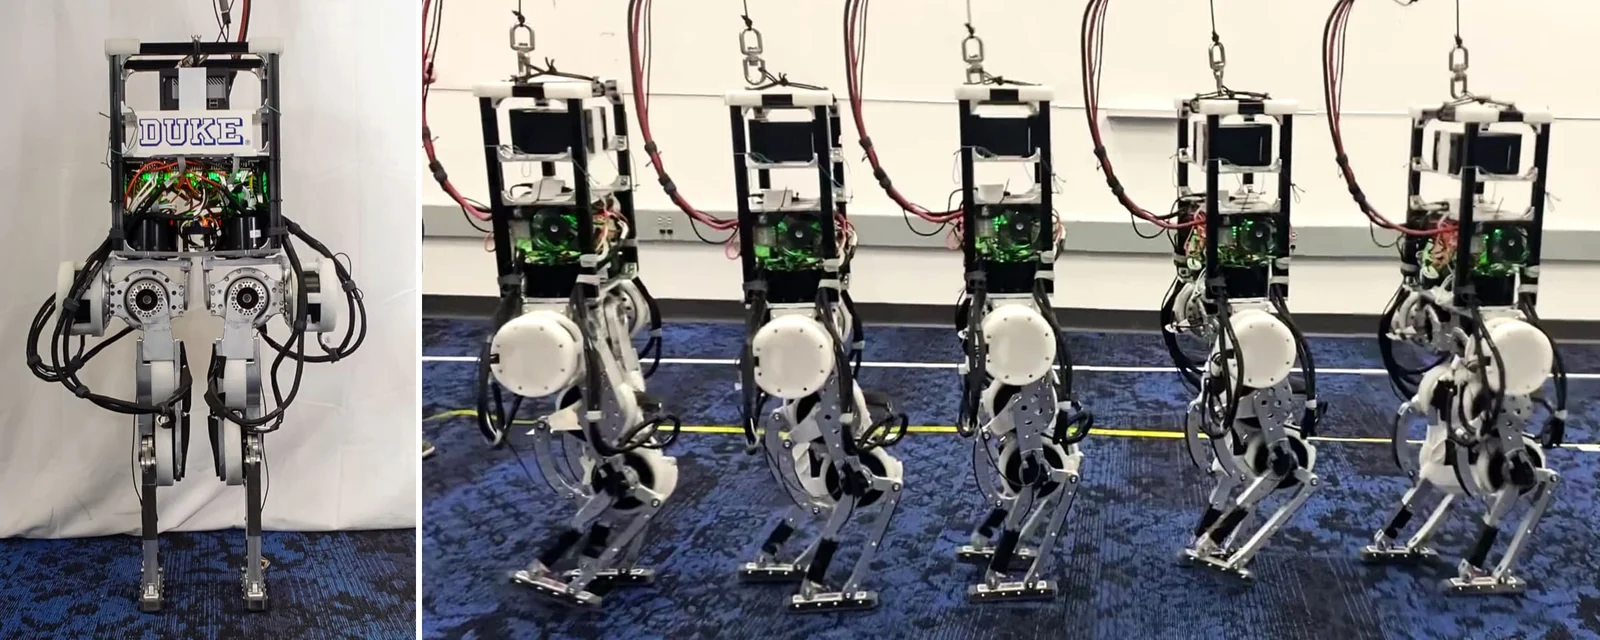

Specifications
3/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | unsourced |
| Degrees of freedomspecs.dof | 10 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | Not for sale |
| Actuatorsspecs.actuators | unsourced |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | 2024 |
| Licenselicense.hw / .sw / .docs | Software: MIT |
Note · Paper arXiv:2409.19795. Hardware wiki on Notion holds the BOM, CNC/DIY CAD zips and Fusion files; the GitHub repo holds code, URDF and policies. The repo is MIT; the Notion CAD has no stated license. v1 is legs only on a box body and tethered (48 V bench supplies, external Linux PC over EtherCAT); motors and drives are quote-only from Motorevo. Repo inactive since Jun 2025; the lab published Duke Humanoid V2 repos in Aug-Sep 2026 (generalroboticslab/duke_humanoid_v2).
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | no | 15 | 0 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | yes | 10 | 10 |
| score = Σ weight × public | 85 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Structure | 9 | 111 | — |
| Fasteners | 9 | 340 | — |
| Electronics | 7 | 24 | — |
| Cabling | 5 | 9 | — |
| Other | 5 | 5 | — |
| Power | 4 | 7 | — |
| Actuators | 3 | 10 | — |
| Sensors | 2 | 5 | — |
| Compute | 1 | 1 | — |
Offers in CN · GLOBAL · US from 12 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 2 | — | — |
| Legs | 4 | — | — |
| Body | 3 | — | — |
| Test rig | 1 | — | — |
| Electrical | 3 | — | 2 |
| Bring-up | 5 | — | 3 |
Fabrication: FDM print ×6 · CNC ×4
Firmware
- Targets
- teensy_comm (Teensy 4.0 sensor hub), Elmo drive parameters (.gprm per joint pair), ethercat_motor_py (host EtherCAT master, SOEM)
- Repo
- github.com/generalroboticslab/dukeHumanoidHardwareControl
- Calibrate
- Joint initialization with printed alignment jigs on every power-on (motor_controller.py stores offsets); IMU baud, gyro bias and mounting transform via MicroStrain SensorConnect.
- Notes
- Host runs Ubuntu 22.04 with a real-time priority Python loop (`sudo chrt -f 99`). The Teensy streams CRC-checked Packetizer frames at 1.5 Mbaud; the IMU runs on Serial1 at 921600. Drive tuning notes (kp/ki per pair) are on the motor0-motor4 wiki pages.
Policies
- walk, velocity tracking (baseline) · Isaac Gym + rl_games (legged_env) · github.com
- walk, energy-efficient passive-dynamics policy · Isaac Gym + rl_games (legged_env) · github.com
- walk (training checkpoints) · Isaac Gym + rl_games · github.comassets/checkpoints/dukehumanoid_passive.pth is the passive counterpart
Caveats · stated by the package
- Duke Humanoid v1 is legs only (10 DOF) with a box body, and it is tethered: power comes from four 48 V bench supplies and compute is an external Linux PC over EtherCAT. There is no battery and no onboard compute (a Jetson is optional).
- No prices anywhere upstream. The BOM.xlsx and the Notion table list sources only, so every line is unpriced.
- Motors and motor controllers come only from Motorevo (motorevo.cn) by quote. Controller part numbers are not given; the wiki shows they are Elmo-based EtherCAT drives configured in Elmo Application Studio.
- The Notion page's per-body list disagrees with the BOM table on the 2020 extrusions: 4x 260 mm (b) and 4x 120 mm (c) vs 2x 260 mm and 2x 260 mm. The table is used here.
- The gantry fasteners conflict: the frame list says 400 M8 T-nuts and 400 M8x16 screws, and the table gives 18 packs of 20 and 9 packs of 40 (360 each). The BOM also notes 'We don't suggest this option' on the T-nuts, without an alternative.
- Parts named in assembly but missing from the BOM: the PCB mount, the motor-controller plates and the power/ground splitters. Alignment jig quantities and material are not stated. The use of Task 16 resin ('for molding') is not explained.
- The TCA9548A, resistor, capacitor and retaining ring lines have no vendor link, and the Mean Well supplies are linked only to the datasheet. Sensor-board pin assignments are only in diagram images.
- The wiki links the load-cell code to github.com/generalroboticslab/fx29-load-cell-arduino, which returns 404. The sketch is in teensy_comm.ino.
- No torque values or step times are published; the assembly guidance is mostly video (upper leg, lower leg, body). The wiki reports that small knee and ankle rocker bearings deform and recommends replacing them with circular shafts.
- The wiki links (Notion) and the CNC/DIY zip and Fusion .f3z files are hosted on Notion. The GitHub repos hold only code, URDF and policies. The parent repo is MIT; the Notion CAD has no stated license.
- The hardware-control repo was last updated 2024-10-06 and the parent repo 2025-06-21. The lab published Duke Humanoid V2 repos in Aug-Sep 2026 (duke_humanoid_v2, Apache-2.0; Duke_Humanoid_V2_OpenSource), which this package does not cover.
Package duke/duke-humanoid@0.1.0 · upstream Notion hardware wiki 'Duke Humanoid V1' (page 38d54de887d1403a82f2367490c45b89, block version 429, read 2026-09-25) incl. BOM.xlsx; DukeHumanoidv1@0700cfbfe4e68b0db8c12a351f4c7dc449524356 (2025-06-21); dukeHumanoidHardwareControl@3a9c3cd4c8daf6b3ffe2e41768360d0515f2df55 (2024-10-06); legged_env@8b21398ffaa2abc8f4d2c599f2c0c11122dfe5a1 (2025-06-21); URDF v6biped_urdf_v4_aug29 · 10 package sources
Models, repositories, links
5 links- URDFgithub.com/generalroboticslab/DukeHumanoidv1model
- Repogithub.com/generalroboticslab/DukeHumanoidv1github.com
- Sitegeneralroboticslab.com/DukeHumanoidv1/generalroboticslab.com
- Docsapp.notion.com/p/Duke-Humanoid-V1-38d54de887d1403a82f2367490c45b89app.notion.com
- Videoyoutube.com/watch?v=RZYkb09JurUyoutube.com
Videos
1 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning Duke Humanoid v1
Papers using Duke Humanoid v1
Sources
last checked 2026-09-25- [1]Official repogithub.com/generalroboticslab/DukeHumanoidv1checked 2026-09-24
- [2]arXiv paperarxiv.org/abs/2409.19795checked 2026-09-24
- [3]Duke Humanoid V1 hardware wiki (Notion: BOM, CAD, power, EtherCAT)app.notion.com/p/Duke-Humanoid-V1-38d54de887d1403a82f2367490c45b89checked 2026-09-25
- [4]duke_humanoid_v2 repo (created 2026-08-25)github.com/generalroboticslab/duke_humanoid_v2checked 2026-09-25
Suggest a correction
Related
Nearest by size (height, mass)
Cite this page
humanoidrobots.systems. “Duke Humanoid v1 specs.” Hyperspawn, data revision 2026-11-22. https://humanoidrobots.systems/duke/duke-humanoid
Machine-readable: /data.json (record duke/duke-humanoid).