cmu/leap-hand · spec sheet
Carnegie LEAP Hand specs
Low-cost 16-DOF, four-finger anthropomorphic research hand built from Dynamixel servos and readily available parts, assemblable in under 4 hours.
Media
3 items · credited and licensed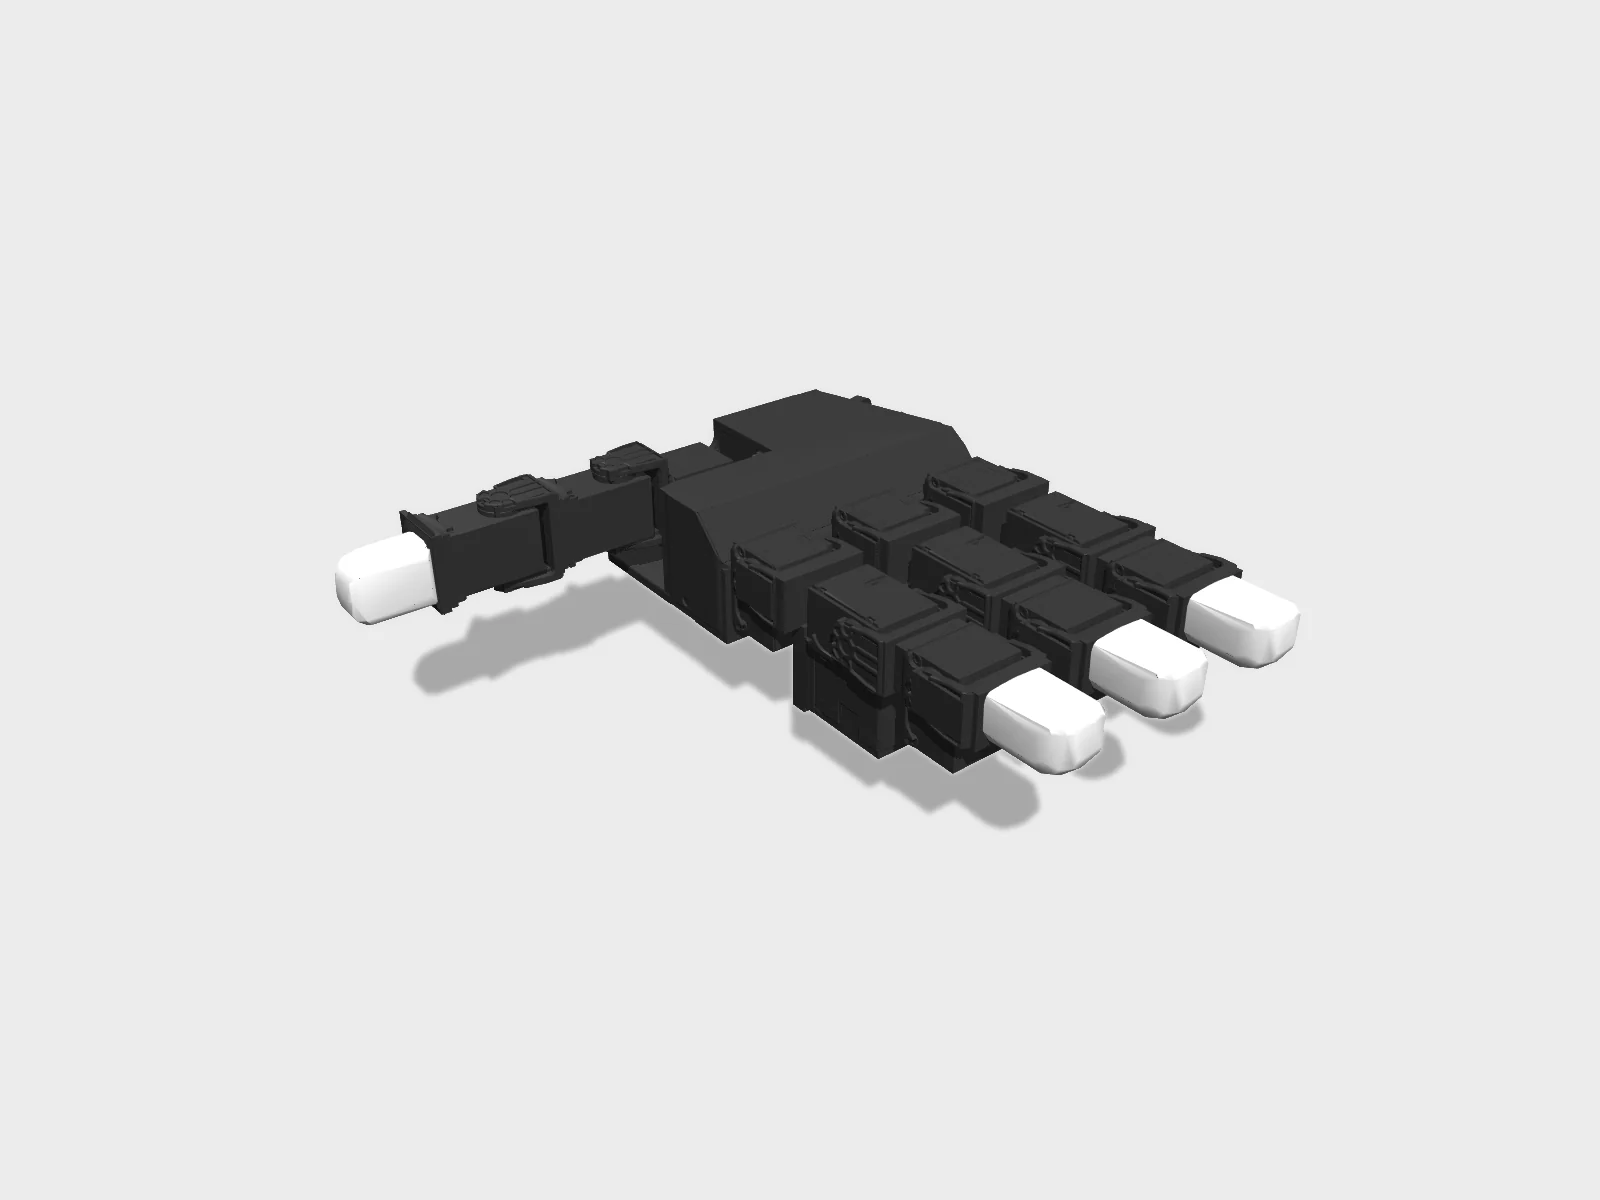 render
 render
Specifications
4/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | unsourced |
| Degrees of freedomspecs.dof | 16 |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | 2,000USDParts page (as of Aug 2023): full hand ~$1,772 (Dynamixel $1,578 + other $193), Lite ~$714; 'under $2000'. The ROBOTIS/Dexbotics kit partnership has ended. |
| Actuatorsspecs.actuators | 16x Dynamixel XC330 + U2D2 |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | 2023 |
| Licenselicense.hw / .sw / .docs | Hardware: CC-BY-NC-4.0Software: MIT |
Note · LEAP Hand v2 (hybrid rigid-soft) also exists. CAD is non-commercial: the LEAP_Hand_API LICENSE file is CC BY-NC 4.0, while its README says CAD is CC BY-NC-SA (no version given) and code is MIT; LEAP_Hand_Sim is MIT. Uses stock Dynamixel firmware. The LEAP purchase page says the ROBOTIS/Dexbotics partnership has ended, so kits and assembled hands are no longer sold through it (the ROBOTIS bundle page still loads); availability is DIY from the Parts list. Third-party assembled hands are not affiliated with LEAP.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | no | 15 | 0 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | no | 10 | 0 |
| score = Σ weight × public | 75 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Actuators | 1 | 16 | 1,440 |
| Structure | 3 | 8 | 78 |
| Printed | 2 | 2 | 69 |
| Fasteners | 4 | 8 | 57 |
| Electronics | 2 | 2 | 51 |
| Other | 1 | 1 | 30 |
| Power | 2 | 2 | 27 |
| Cabling | 2 | 2 | 19 |
Offers in GLOBAL · US from 5 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 3 | — | 1 |
| Preparation | 1 | — | — |
| Fingers | 3 | — | — |
| Palm | 1 | — | — |
| Electronics | 2 | — | 2 |
| Software | 1 | — | — |
| Bring-up | 1 | — | 1 |
| Policy | 1 | — | — |
Fabrication: FDM print ×6
Firmware
- Targets
- DYNAMIXEL XC330-M288-T (x16, IDs 0-15), U2D2 (USB-TTL)
- Repo
- github.com/leap-hand/LEAP_Hand_API
- Calibrate
- No encoder calibration: assemble with every horn at its home mark, set IDs 0-15 in Dynamixel Wizard 2.0, then run python/main.py, which commands the 180° home pose. A joint off by a multiple of 90° means a remounted horn is needed.
- Notes
- Stock Dynamixel firmware; the host API (Python, C++, ROS, ROS 2) sets PID gains and current limit (default 350 mA in main.py, up to 550 mA on XC330 Full hands, ~300 mA on Lite). Position, velocity and current can be read at up to about 500 Hz.
Policies
- in-hand cube reorientation (LeapHandRot) · Isaac Gym Preview 4 + rl_games PPO (LEAP_Hand_Sim) · github.comPretrained checkpoint shipped in the repo; the README deploys it on the real hand through the ROS 1 module.
Caveats · stated by the package
- Prices are the Parts page's 'As of Aug 2023' figures: Full ≈ $1,771.74 (Dynamixel $1,578.34 + other $193.40), Lite ≈ $714.30. The page also says 'under $2000' / '~$700'. Tools (printer, iron, drivers) are extra.
- Most non-Dynamixel links are Amazon a.co short links and DigiKey short links; they resolve to specific listings but can change. ROBOTIS US is the only region with product links; outside the US the page points to the ROBOTIS international shop front.
- The LEAP Purchase page says the ROBOTIS/Dexbotics partnership has ended, so ROBOTIS no longer sells LEAP Dynamixel kits or assembled hands through it, though the ROBOTIS bundle page still loads. Third-party assembled hands (Amazon, Taobao) are not affiliated with LEAP.
- M2 nuts used throughout the assembly are not a separate BOM line; the guide assumes the nuts supplied with the Dynamixel brackets. Count before you start.
- The Parts page lists the M2 8 mm and M2 10 mm screws as two $19 lines with the same variety-pack link; one pack may cover both.
- CAD is CC BY-NC-SA (non-commercial) and is behind a request form; the API code is MIT. The robots.ts record lists the hardware as CC-BY-NC-4.0.
- This package covers LEAP Hand v1. LEAP Hand v2 (v2.leaphand.com) and v2-adv are different designs with their own parts.
- The assembly page gives no torques and no per-step times; the Parts page says under three hours of assembly.
- Print hours and grams per part are not published (total: under 24 h, about 200 g of PLA).
Package cmu/leap-hand@0.1.0 · upstream v1.leaphand.com Parts/Assembly/Purchase/CAD pages as read 2026-09-25 (costs 'As of Aug 2023'); leap-hand/LEAP_Hand_API@b0d00c881d0119077b2cab771a6de44f5aaec904 (2025-10-20); leap-hand/LEAP_Hand_Sim@150bc3d4b61fd6619193ba5a8ef209f3609ced89 (2024-05-18) · 9 package sources
Models, repositories, links
8 links- URDFgithub.com/leap-hand/LEAP_Hand_Simmodel
- MJCFgithub.com/google-deepmind/mujoco_menagerie/tree/main/leap_handmodel
- Menageriemujoco_menagerie/leap_handmodel
- Repogithub.com/leap-hand/LEAP_Hand_APIgithub.com
- Repogithub.com/leap-hand/LEAP_Hand_Simgithub.com
- Sitev1.leaphand.com/v1.leaphand.com
- Docsv1.leaphand.com/v1.leaphand.com
- Buyv1.leaphand.com/purchasev1.leaphand.com
Videos
1 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning LEAP Hand
Papers using LEAP Hand
20231
- Open source
CMU releases the LEAP Hand
Carnegie Mellon researchers released LEAP Hand, an open anthropomorphic robot hand costing under $2,000 that can be assembled with a 3D printer and a screwdriver.
Carnegie LEAP Handcs.cmu.eduv1.leaphand.com
Sources
last checked 2026-09-25- [1]LEAP Hand v1 sitev1.leaphand.com/checked 2026-09-24
- [2]RSS 2023 paperroboticsproceedings.org/rss19/p089.pdfchecked 2026-09-24
- [3]API repo (license note)github.com/leap-hand/LEAP_Hand_APIchecked 2026-09-24
- [4]ROBOTIS bundlerobotis.us/products/leap-hand-bundle-xc330checked 2026-09-24
- [5]LEAP Hand purchase page (ROBOTIS/Dexbotics partnership ended)v1.leaphand.com/purchasechecked 2026-09-25
- [6]LEAP Hand parts list (costs as of Aug 2023)v1.leaphand.com/partschecked 2026-09-25
Suggest a correction
Related
Nearest by size (height, mass)
Cite this page
humanoidrobots.systems. “Carnegie LEAP Hand specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/cmu/leap-hand
Machine-readable: /data.json (record cmu/leap-hand).