alexanderkoch/koch-v1-1 · spec sheet
Alexander Koch v1.1 Low-Cost Robot Arm specs
Dynamixel-based low-cost leader/follower arm pair; an assembly-friendly revision of Alexander Koch's low_cost_robot, used in early LeRobot work.
Media
4 items · credited and licensed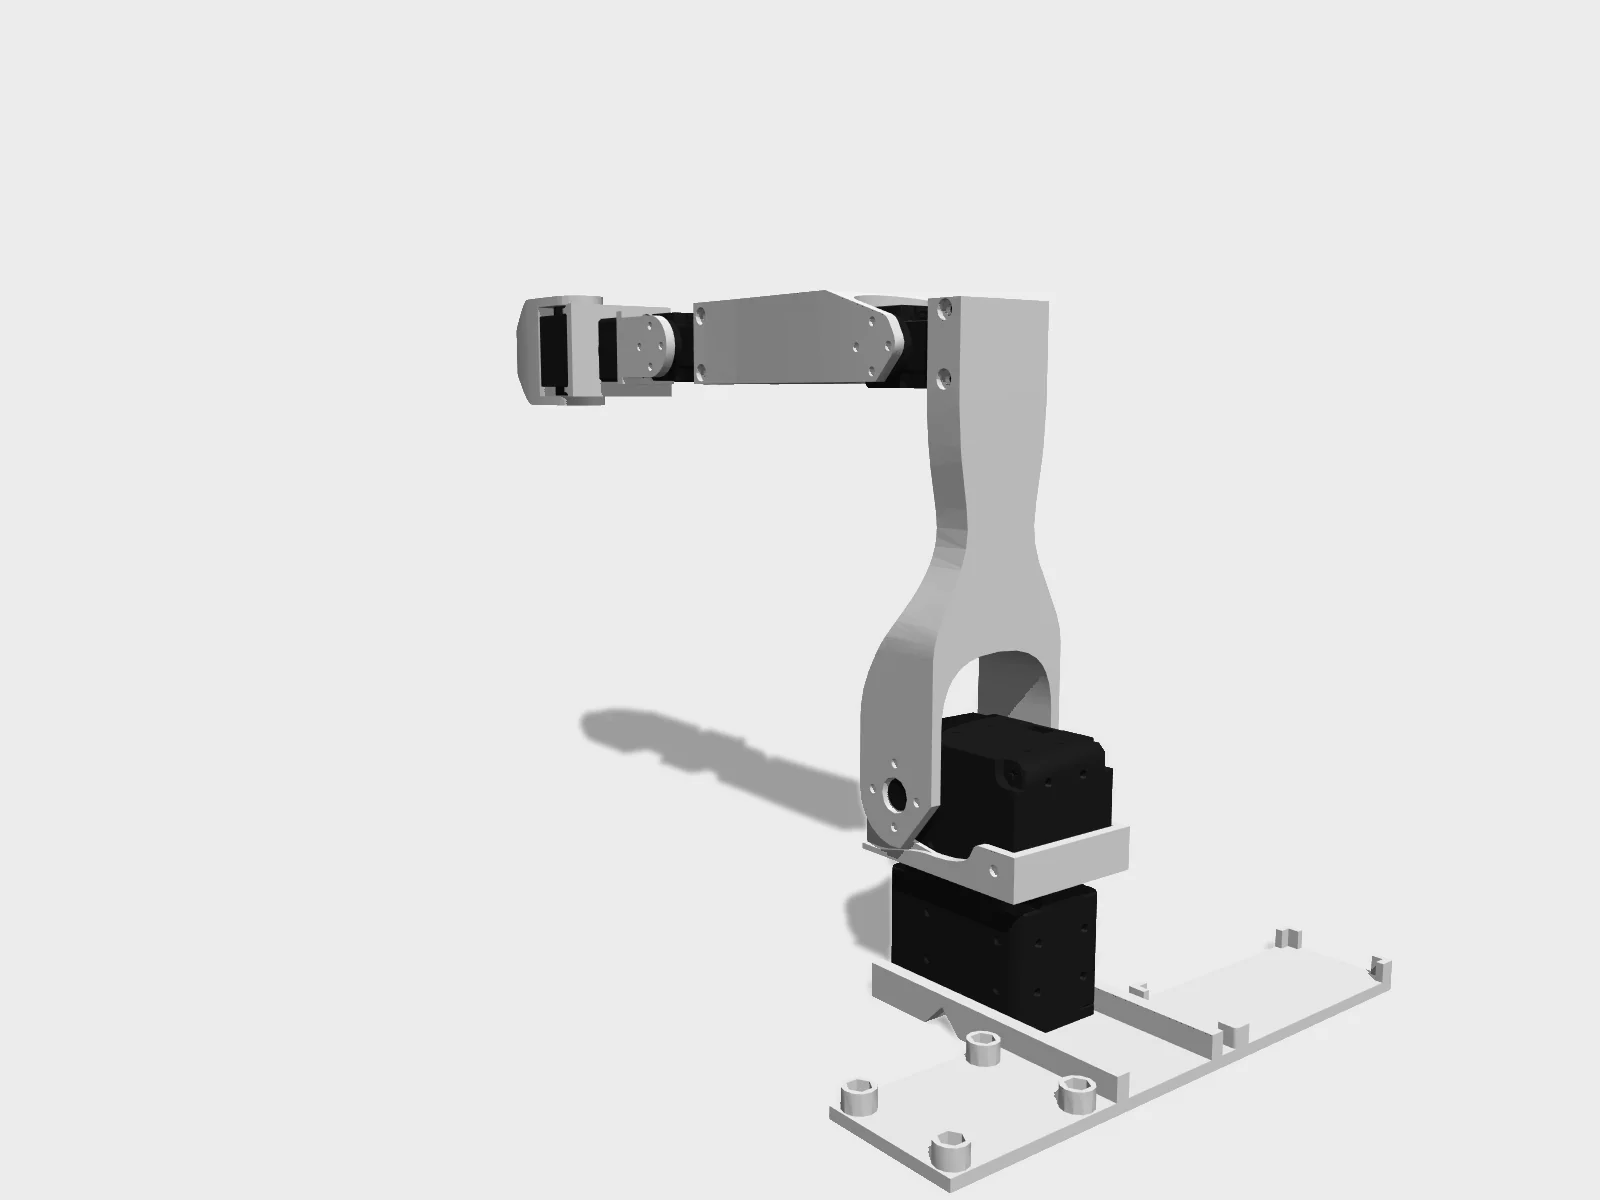 render
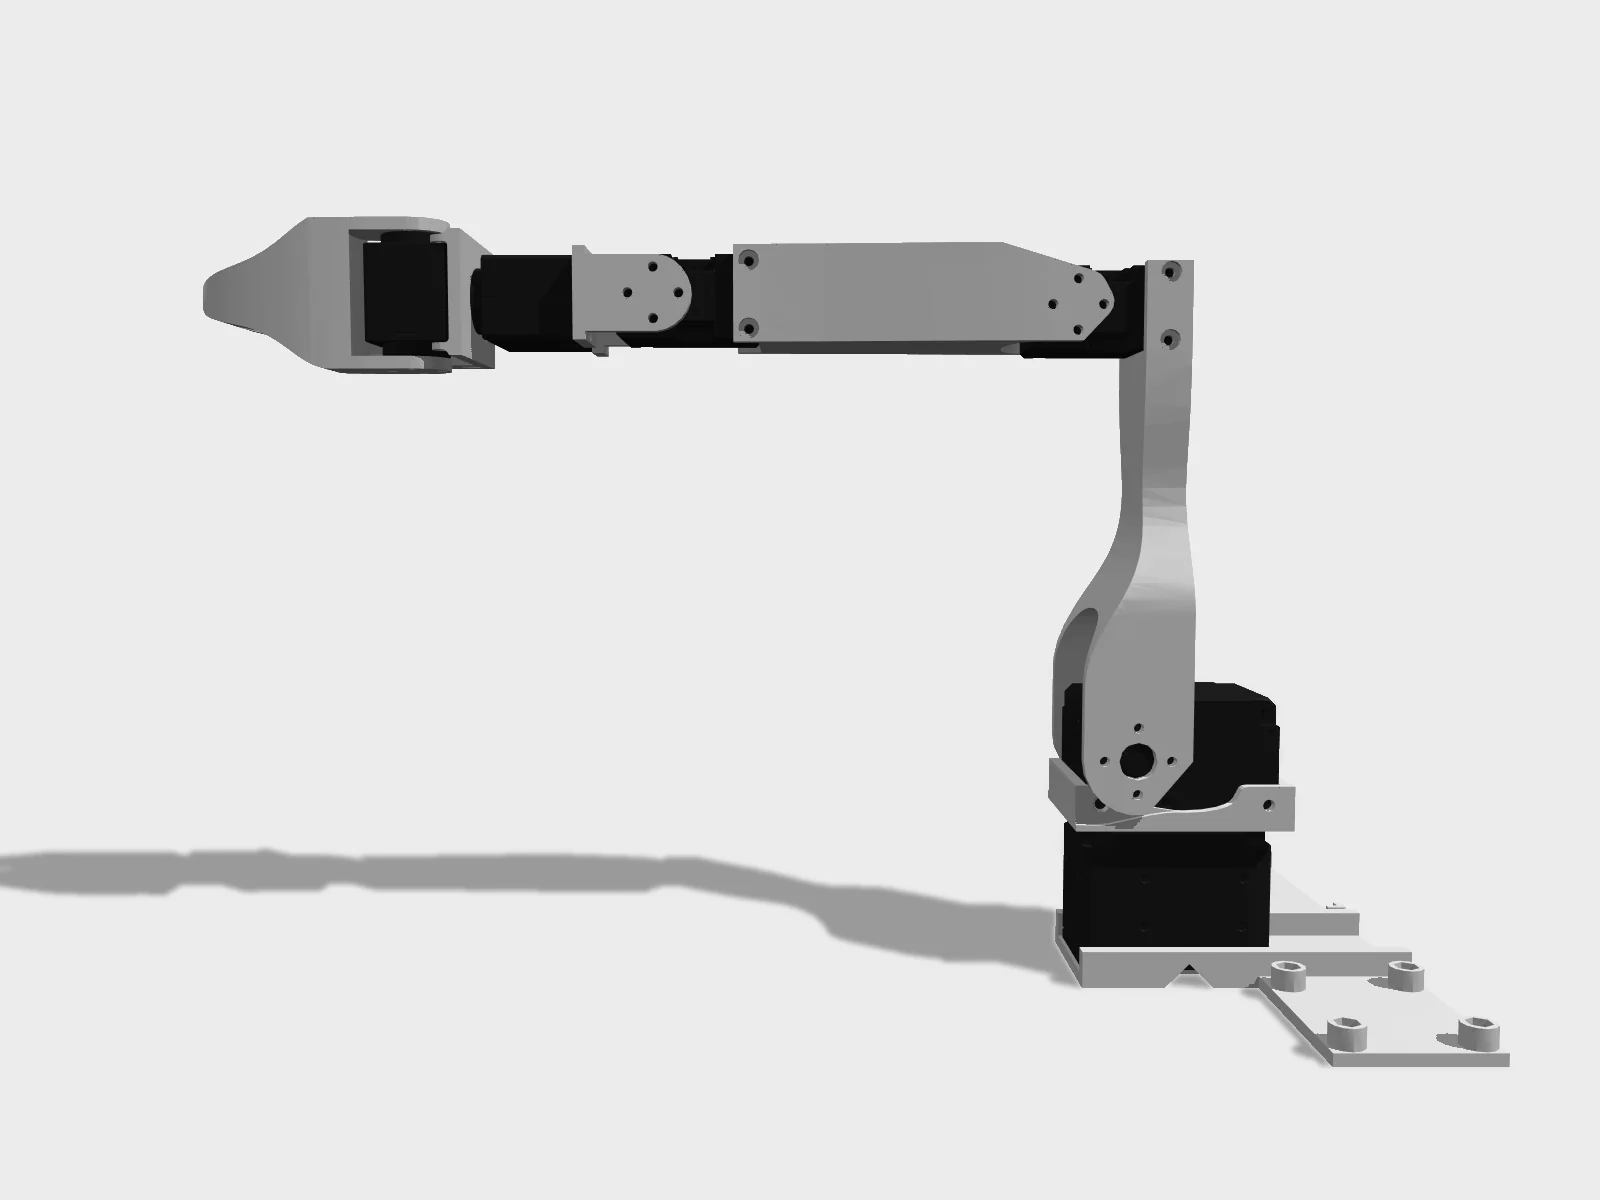 render
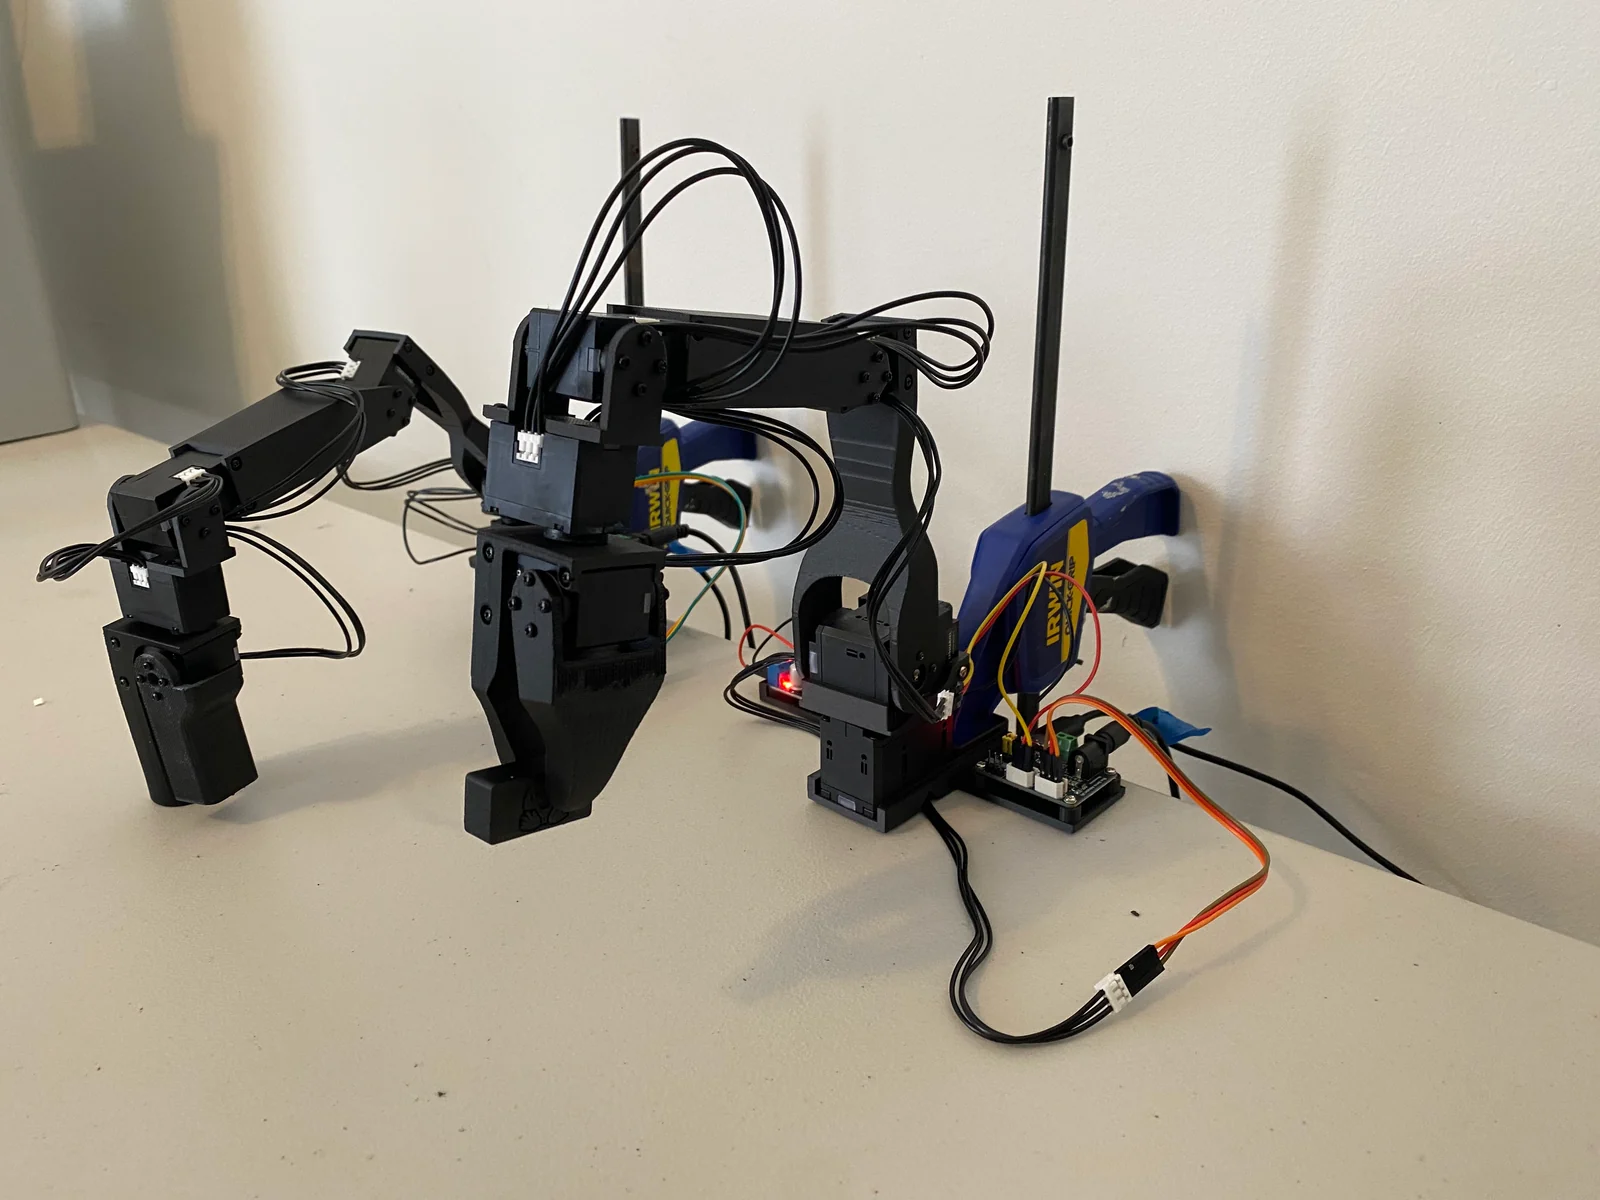

Specifications
2/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | unsourced |
| Degrees of freedomspecs.dof | unsourced |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourcedRepo README (2024, US parts): follower arm $278, leader arm $199; printing extra |
| Actuatorsspecs.actuators | Follower: Dynamixel XL430-W250-T x2 + XL330-M288-T x4; leader: XL330-M077-T x6 |
| Computespecs.compute | unsourced |
| Sensorsspecs.sensors | unsourced |
| Year introducedyear | 2024 |
| Licenselicense.hw / .sw / .docs | Hardware: Apache-2.0Software: Apache-2.0 |
Note · Repo last pushed Sep 2024; LeRobot community has largely moved to SO-101. Original low_cost_robot is MIT-licensed. Uses stock Dynamixel firmware (firmware=false). policies=false: only datasets are published upstream.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | no | 15 | 0 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | no | 10 | 0 |
| score = Σ weight × public | 75 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Actuators | 3 | 12 | 340 |
| Power | 3 | 3 | 32 |
| Structure | 3 | 3 | 27 |
| Cabling | 3 | 3 | 23 |
| Electronics | 2 | 2 | 20 |
| Other | 3 | 3 | 19 |
| Fasteners | 2 | 8 | — |
Offers in CN · EU · GLOBAL · US from 12 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 1 | — | — |
| Software | 1 | — | — |
| Follower arm | 3 | — | 1 |
| Leader arm | 4 | — | 1 |
| Electronics | 2 | — | 1 |
| Calibration | 2 | — | 1 |
| First motion | 1 | — | 1 |
| Policy | 2 | — | — |
Fabrication: FDM print ×17
Firmware
- Targets
- Dynamixel XL430-W250-T (stock firmware), Dynamixel XL330-M288-T (stock firmware), Dynamixel XL330-M077-T (stock firmware), Waveshare Serial Bus Servo Driver Board (USB-serial, no user firmware)
- Repo
- github.com/huggingface/lerobot
- Calibrate
- `lerobot-calibrate --robot.type=koch_follower --robot.port=<port> --robot.id=<name>` and `lerobot-calibrate --teleop.type=koch_leader --teleop.port=<port> --teleop.id=<name>`: move all joints to mid-range, press Enter, then sweep every joint through its full range.
- Notes
- No custom firmware. Motor IDs (1 shoulder_pan to 6 gripper) and baudrate are written to servo EEPROM by `lerobot-setup-motors`. The original low_cost_robot flow used Dynamixel Wizard 2 (baud 1 M) and the Dynamixel SDK (`pip install dynamixel-sdk`) with its own teleoperate_real_robot.py.
Caveats · stated by the package
- No official Koch policy checkpoints are published by LeRobot; only datasets exist (e.g. lerobot/koch_pick_place_5_lego). The robots.ts 'policies: true' flag rests on community models, not an upstream release.
- USD prices are the README's 2024 US figures (leader total $199, follower $278); EUR/GBP/CNY/JPY prices are kept as notes. Robotis prices and Amazon listings may have changed since the repo's last commit (Sep 2024).
- UK links are filed under region EU and Japan links under GLOBAL because the registry has no UK or JP region.
- Taobao/Tmall URLs are the README links reduced to item id and skuId; several a.co short links resolve to Amazon listings that may be gone.
- Leader and follower tables both list the Waveshare board, jumpers and a table clamp; the screwdriver and USB cable sets are listed twice upstream but the footnotes say buy once, so they appear once here.
- The LeRobot Koch page powers the follower board from the 5 V supply during motor setup, while the README and wiring diagram run the follower at 12 V with a 12-to-5 V reducer for the XL330 chain. Both are consistent only if the 12 V supply is never used while an XL330 is plugged straight into the board (XL330 rated 3.7-6.0 V, XL430 6.5-12.0 V per the Robotis e-Manual). Whether the XL430s answer ID setup at 5 V is not stated upstream.
- The leader board runs at 5 V although the Waveshare board is rated 9-12.6 V; the README says this is intended (footnote 14).
- The assembly video predates the screwed Leader_Platform and the LeRobot motor-setup order; follow the README and LeRobot notes where they differ.
- No fastener list beyond the four M2x5 screws and M2 nuts for the platform: servo screws come with the Robotis frame/idler sets. Check the video for counts.
- No camera is in the BOM; recording datasets needs at least one USB camera.
- Repo is Apache-2.0; the original low_cost_robot is MIT. The repo has not changed since Sep 2024 and LeRobot now centres on SO-101.
Package alexanderkoch/koch-v1-1@0.1.0 · upstream jess-moss/koch-v1-1@1a553e1fa7d5404b51bbd83b99b0f7eba54888e0 (2024-09-17); AlexanderKoch-Koch/low_cost_robot@0602b0c1e6a67d8f6ab96f81d1378639018d98af (2024-09-21); LeRobot docs page /koch and /il_robots as of 2026-09-25 (huggingface/lerobot@e624f3f7f8411ec3a02635d06e79373341e5ef35, v0.6.2, lerobot-* CLI) · 10 package sources
Models, repositories, links
7 links- URDFgithub.com/s1lent4gnt/koch-v1-1/blob/main/simulation/follower.urdfmodel
- MJCFgithub.com/google-deepmind/mujoco_menagerie/tree/main/low_cost_robot_armmodel
- Menageriemujoco_menagerie/low_cost_robot_armmodel
- Repogithub.com/jess-moss/koch-v1-1github.com
- Repogithub.com/AlexanderKoch-Koch/low_cost_robotgithub.com
- Sitegithub.com/jess-moss/koch-v1-1github.com
- Docsgithub.com/jess-moss/koch-v1-1github.com
Videos
1 tagged · 0 from the maker's channelNews and papers
0 stories · 0 papersNews mentioning Koch v1.1 Low-Cost Robot Arm
Papers using Koch v1.1 Low-Cost Robot Arm
Sources
last checked 2026-09-25- [1]Koch v1.1 repo (Apache-2.0, BOM, leader/follower totals)github.com/jess-moss/koch-v1-1checked 2026-09-25
- [2]LeRobot Koch dataset (no official policy)huggingface.co/datasets/lerobot/koch_pick_place_5_legochecked 2026-09-25
- [3]Original low_cost_robot (MIT)github.com/AlexanderKoch-Koch/low_cost_robotchecked 2026-09-24
- [4]MuJoCo Menagerie low_cost_robot_armgithub.com/google-deepmind/mujoco_menagerie/tree/main/low_cost_robot_armchecked 2026-09-24
- [5]Alexander Koch on GitHub (location)github.com/AlexanderKoch-Kochchecked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
Compare
Compare Koch v1.1 Low-Cost Robot Arm with up to three others
Cite this page
humanoidrobots.systems. “Alexander Koch v1.1 Low-Cost Robot Arm specs.” Hyperspawn, data revision 2026-10-08. https://humanoidrobots.systems/alexanderkoch/koch-v1-1
Machine-readable: /data.json (record alexanderkoch/koch-v1-1).