uiuc/lekiwi · spec sheet
SIGRobotics LeKiwi specs
Low-cost mobile manipulator combining a three-omni-wheel holonomic base with an SO-101 arm, a Raspberry Pi 5 and two RGB cameras, supported in LeRobot.
Media
4 items · credited and licensed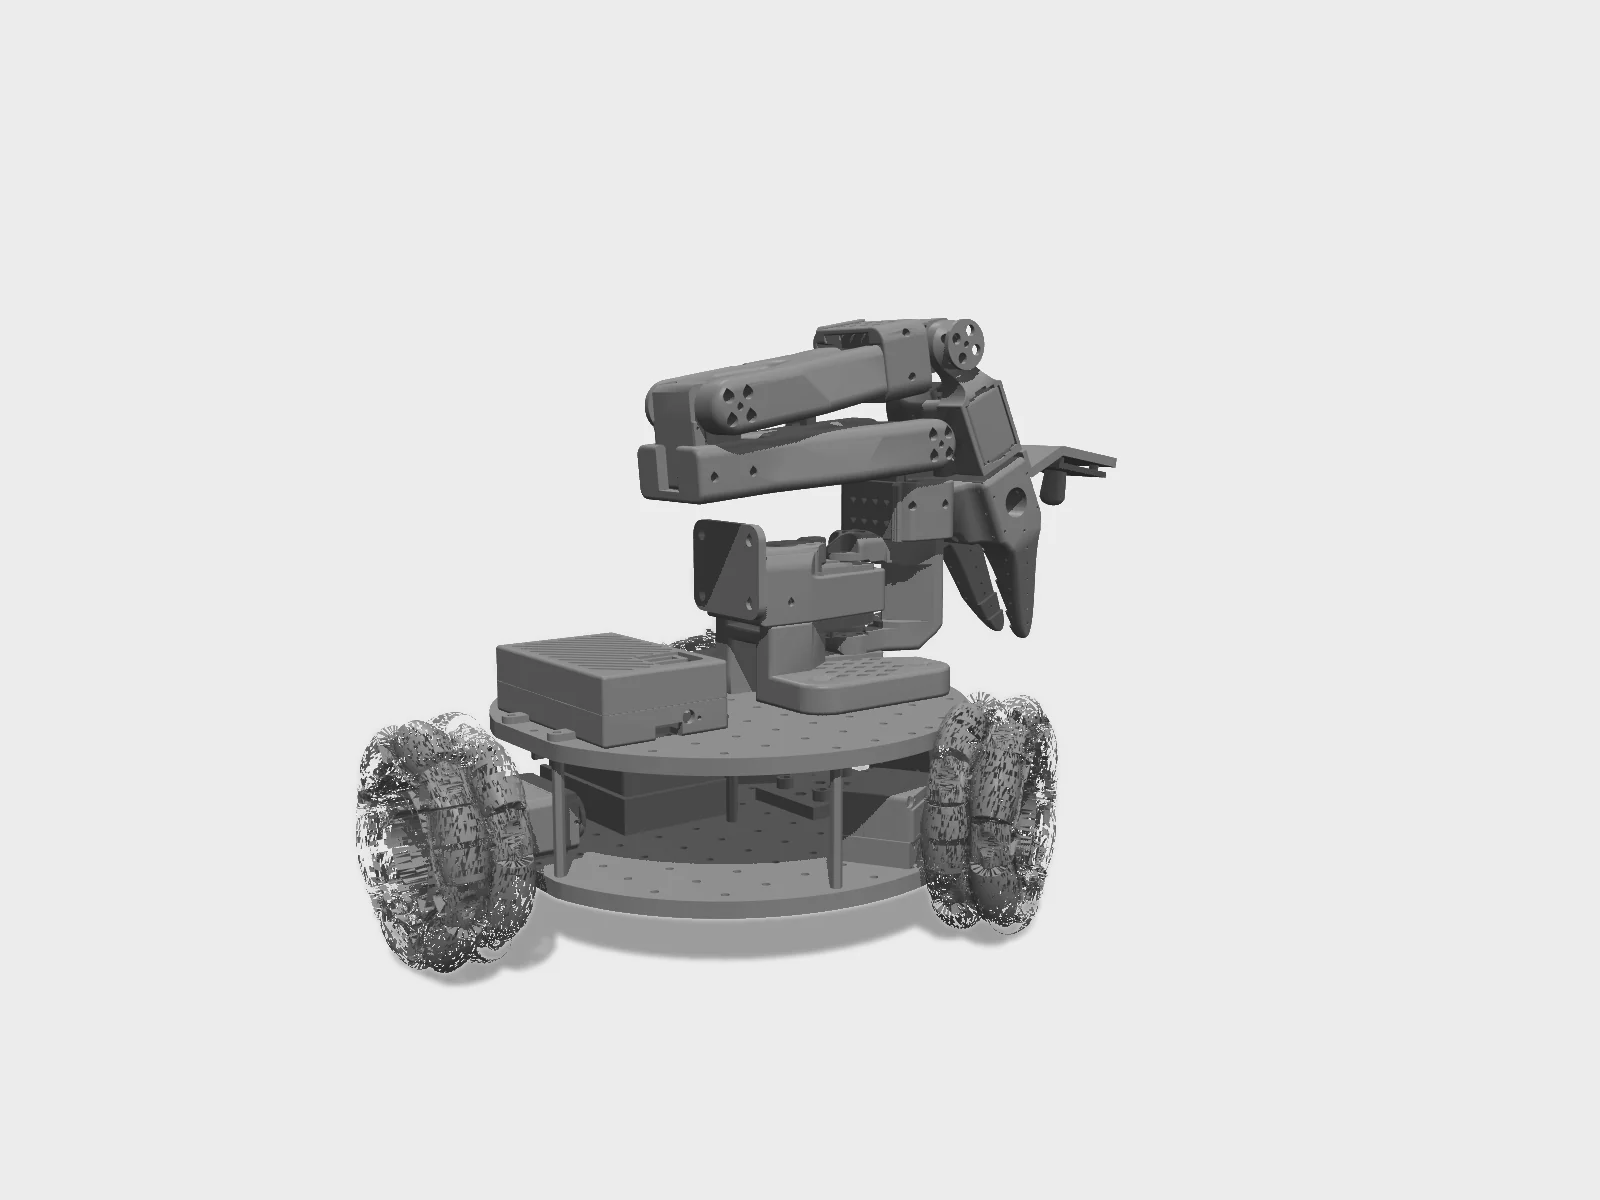 render
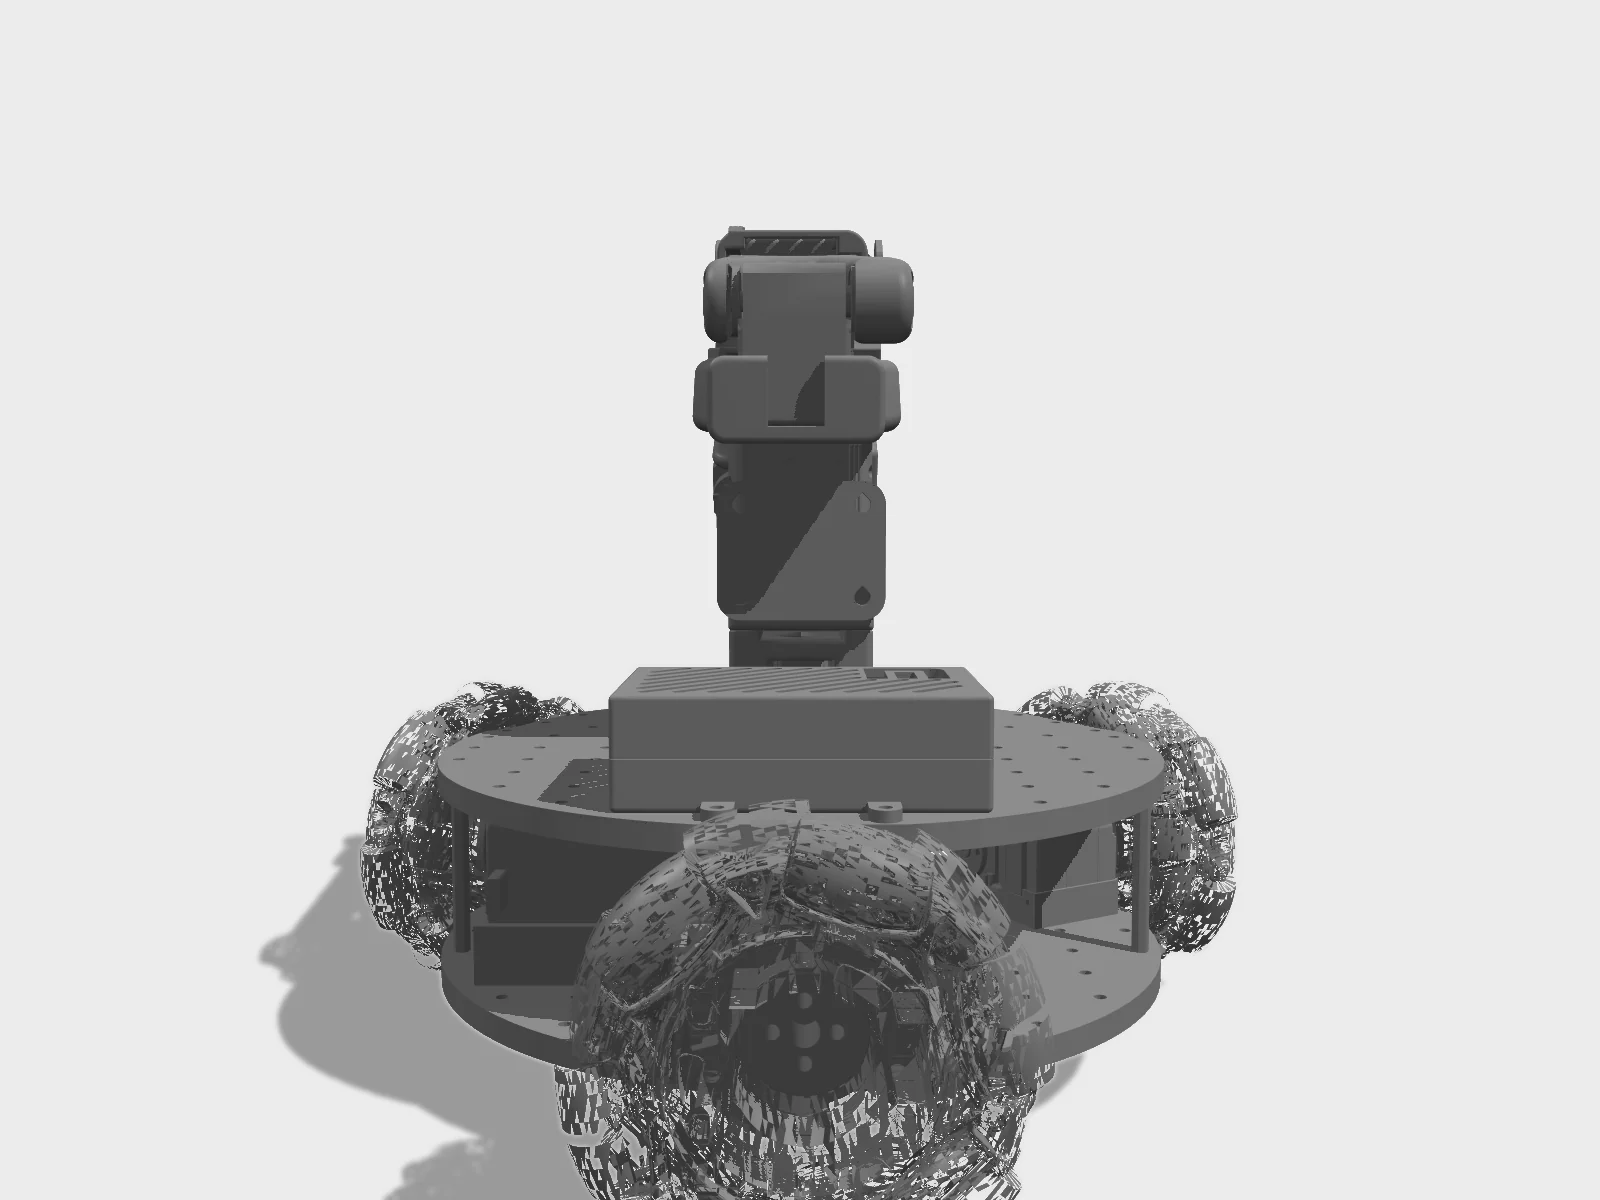 render
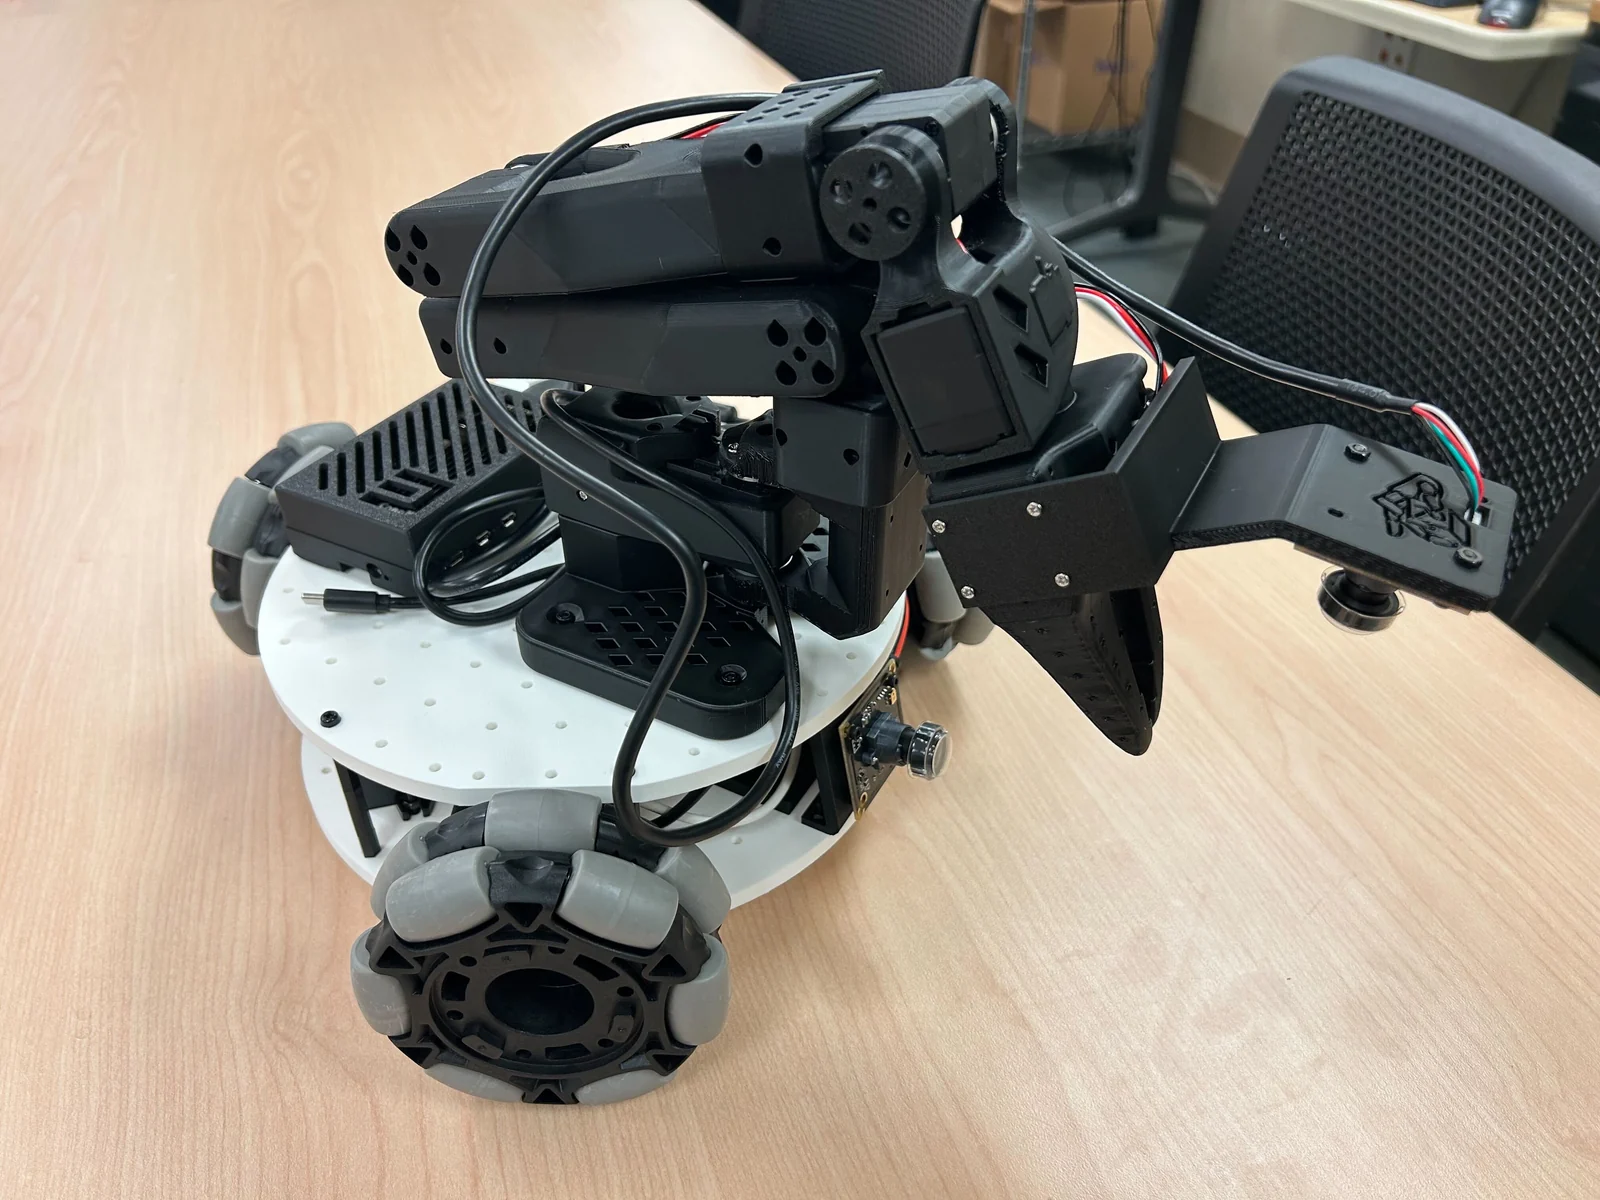

Specifications
2/12 fields sourced| Heightspecs.heightCm | unsourced |
|---|---|
| Massspecs.massKg | unsourced |
| Degrees of freedomspecs.dof | unsourced |
| Payloadspecs.payloadKg | unsourced |
| Top speedspecs.speedMps | unsourced |
| Runtimespecs.runtimeMin | unsourced |
| Battery capacityspecs.batteryWh | unsourced |
| Pricespecs.priceUsd | unsourcedUpstream BOM totals, excluding printing: 5 V $499, 12 V $482, base-only wired $184 |
| Actuatorsspecs.actuators | unsourced |
| Computespecs.compute | Raspberry Pi 5 |
| Sensorsspecs.sensors | Workspace and wrist RGB cameras |
| Year introducedyear | unsourced |
| Licenselicense.hw / .sw / .docs | Hardware: Apache-2.0Software: Apache-2.0 |
Note · Mobile manipulator (wheeled base + arm), classed as rover. Fusion 360 CAD public. Dynamixel variant uses Koch v1.1 arm. City = UIUC campus. Three upstream variants: 5 V (power bank), 12 V and wired. Seeed Studio sells a 12 V full kit, listed in the repo BOM.
| Artifact | Public | Weight | Points |
|---|---|---|---|
| CADopenness.cad | yes | 25 | 25 |
| Bill of materialsopenness.bom | yes | 20 | 20 |
| Sim model (URDF/MJCF)openness.sim | yes | 20 | 20 |
| Firmwareopenness.firmware | yes | 15 | 15 |
| Softwareopenness.software | yes | 10 | 10 |
| Trained policiesopenness.policies | no | 10 | 0 |
| score = Σ weight × public | 90 | ||
BOM by category · USD from priced lines
| Category | Lines | Qty | USD |
|---|---|---|---|
| Actuators | 2 | 15 | 225 |
| Compute | 1 | 1 | 60 |
| Power | 2 | 2 | 52 |
| Electronics | 2 | 3 | 33 |
| Structure | 1 | 3 | 30 |
| Sensors | 1 | 2 | 26 |
| Cabling | 3 | 3 | 25 |
| Other | 2 | 2 | 24 |
| Fasteners | 1 | 1 | 15 |
Offers in CN · EU · US from 14 vendors
Subsystems · assembly groups
| Group | Steps | Min | Safety |
|---|---|---|---|
| Fabrication | 1 | — | — |
| Arms | 1 | — | — |
| Compute | 2 | — | — |
| Mobile base | 4 | — | — |
| Electrical | 1 | — | 1 |
| Cameras | 1 | — | — |
| Motor setup | 1 | — | 1 |
| Calibration | 1 | — | 1 |
| First motion | 1 | — | 1 |
| Policy | 3 | — | 1 |
Fabrication: FDM print ×14
Firmware
- Targets
- Feetech STS3215 x9 on one bus (arm IDs 1-6, wheels 7 left / 8 back / 9 right), Waveshare serial bus servo driver (USB bridge, no user firmware), Raspberry Pi 5 running lerobot.robots.lekiwi.lekiwi_host (ZeroMQ, ports 5555 cmd / 5556 observations)
- Repo
- github.com/huggingface/lerobot
- Calibrate
- lerobot-calibrate --robot.type=lekiwi --robot.id=<id> on the Pi (arm only; wheels need none), then lerobot-calibrate --teleop.type=so100_leader --teleop.port=<port> --teleop.id=<id> on the laptop.
- Notes
- No custom firmware. LeKiwi runs as a host/client pair: lekiwi_host on the Pi owns the servo bus and cameras (default front=/dev/video0 640x480, wrist=/dev/video2 480x640, 30 fps), and LeKiwiClient on the laptop sends actions and receives observations. Kinematics use wheel radius 0.05 m and base radius 0.125 m. The wired version runs everything on the laptop. A Dynamixel variant (Koch v1.1 arm, U2D2, XL430 wheels) lives in DynamixelLeKiwi/ and is not covered here.
Policies
- LeKiwi pick and place (community SmolVLA fine-tune) · LeRobot (SmolVLA) · huggingface.coCommunity checkpoint, not from SIGRobotics or Hugging Face. Fine-tuned from lerobot/smolvla_base for 80k steps on Sounness/lekiwi_pick_and_place_v2 (98 episodes, robot_type lekiwi_client, cameras top/wrist/front). No success rate reported. Apache-2.0.
Caveats · stated by the package
- Upstream pins: SIGRobotics-UIUC/LeKiwi@efa608d7ee5a495a4803b1d28cd0c955b4f1e033 (2026-08-05): BOM.md, 3DPrinting.md, Assembly.md, 3DPrintMeshes; huggingface/lerobot@e624f3f7f8411ec3a02635d06e79373341e5ef35 (2026-09-24, lerobot 0.6.2): docs/source/lekiwi.mdx, src/lerobot/robots/lekiwi; huggingface.co/docs/lerobot/lekiwi as of 2026-09-25. BOM lines follow the upstream 5 V version (recommended for first builds); 12 V and wired swaps are listed in alts.
- Three upstream variants: 5 V (power bank, recommended for first builds), 12 V (12 V 5 A battery and 12 V servos, for heavier lifts) and wired (no Pi or battery; laptop over USB hub). This package lists the 5 V BOM with 12 V and wired swaps in alts. Upstream totals: 5 V $499 / €526 / ¥2829; 12 V $482 / €545.8 / ¥2891; base-only wired $184 / €235 / ¥963.9. All exclude 3D printing.
- The LeKiwi BOM's SO-101 teleoperation set lists 12 identical STS3215 servos from a 6-pack listing. The SO-ARM100 README specifies mixed leader gearing for the SO-101 (1/191 on joints 1 and 3, 1/147 on joints 4-6). Buy the leader servos per the SO-ARM100 BOM if you want the SO-101 leader behaviour.
- The LeKiwi docs and examples use so100_leader for the teleop arm. In lerobot 0.6.x so100_leader and so101_leader map to the same class, so either works.
- Webcam mounting needs M3x12, 2x M3x35 bolts and M3 nuts, and the Arducam option needs M2.5x12 screws. These may not all be in the assorted screw set.
- The upstream 5 V wiring is given only as a diagram image in Assembly.md, and the 12 V wiring is in prose (Wago lever connectors). There is no fuse or power switch in either BOM.
- Keyboard base teleoperation relies on a global key listener: it works on X11, Windows and macOS with Input Monitoring granted, not on Wayland or headless sessions.
- Several upstream vendor links are short links (a.co, e.tb.cn, qr.1688.com) or tracking URLs, and they resolve to marketplace listings that change often.
- Seeed Studio sells a LeKiwi full kit (12 V) at https://www.seeedstudio.com/LeKiwi-Full-Kit-12V-Verision.html (listed in BOM.md). The only public LeKiwi policies are community fine-tunes with no reported evaluation.
Package uiuc/lekiwi@0.1.0 · upstream SIGRobotics-UIUC/LeKiwi@efa608d7ee5a495a4803b1d28cd0c955b4f1e033 (2026-08-05): BOM.md, 3DPrinting.md, Assembly.md, 3DPrintMeshes; huggingface/lerobot@e624f3f7f8411ec3a02635d06e79373341e5ef35 (2026-09-24, lerobot 0.6.2): docs/source/lekiwi.mdx, src/lerobot/robots/lekiwi; huggingface.co/docs/lerobot/lekiwi as of 2026-09-25. BOM lines follow the upstream 5 V … (full pins in caveats) · 13 package sources
Models, repositories, links
6 links- URDFgithub.com/SIGRobotics-UIUC/LeKiwi/blob/main/URDF/LeKiwi.urdfmodel
- Repogithub.com/SIGRobotics-UIUC/LeKiwigithub.com
- Repogithub.com/huggingface/lerobotgithub.com
- Sitegithub.com/SIGRobotics-UIUC/LeKiwigithub.com
- Docshuggingface.co/docs/lerobot/lekiwihuggingface.co
- Buyseeedstudio.com/LeKiwi-Full-Kit-12V-Verision.htmlseeedstudio.com
News and papers
0 stories · 0 papersNews mentioning LeKiwi
Papers using LeKiwi
Sources
last checked 2026-09-25- [1]LeKiwi BOM (variant totals, Seeed kit link)github.com/SIGRobotics-UIUC/LeKiwi/blob/main/BOM.mdchecked 2026-09-25
- [2]Seeed Studio LeKiwi full kit (12 V)seeedstudio.com/LeKiwi-Full-Kit-12V-Verision.htmlchecked 2026-09-25
- [3]LeKiwi repogithub.com/SIGRobotics-UIUC/LeKiwichecked 2026-09-24
- [4]LeRobot LeKiwi docshuggingface.co/docs/lerobot/lekiwichecked 2026-09-24
Suggest a correction
Related
Nearest by size (height, mass)
Cite this page
humanoidrobots.systems. “SIGRobotics LeKiwi specs.” Hyperspawn, data revision 2026-11-22. https://humanoidrobots.systems/uiuc/lekiwi
Machine-readable: /data.json (record uiuc/lekiwi).